Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 erwincoumans |
63c4d67e33 | ||
|
Erwin Coumans
|
d1a4256b3a | ||
|
Erwin Coumans
|
6c888f4abd | ||
|
Erwin Coumans
|
bda00360fb | ||
|
Erwin Coumans
|
69783a8480 | ||
|
erwincoumans
|
e9c461b0ac | ||
|
erwincoumans
|
43d336fcad | ||
|
erwincoumans
|
5e89410409 | ||
|
ctingley
|
2c7918423d | ||
|
Ian Chen
|
d7f9d66207 | ||
|
Luke Bayes
|
335c18821f | ||
|
Erwin Coumans
|
6bb8d1123d | ||
|
Erwin Coumans
|
fcef2c81f2 | ||
|
erwincoumans
|
39b8de74df | ||
|
erwincoumans
|
e7193f8fdf | ||
|
Xinlei Wang
|
d9a4a7e703 | ||
|
Nate Koenig
|
94e5b69379 | ||
|
erwincoumans
|
0e59474e1c | ||
|
erwincoumans
|
c037d9ba27 | ||
|
Maarten Behn
|
e323404ac3 | ||
|
Maarten Behn
|
5c8dfe4b21 | ||
|
Maarten Behn
|
54cdf39933 | ||
|
Maarten Behn
|
2b4757f512 | ||
|
Maarten Behn
|
9dd446609a | ||
|
Johannes Brust
|
60512c7872 | ||
|
Johannes Brust
|
fa1d1fc8ee | ||
|
yo
|
8549f00502 | ||
|
erwincoumans
|
2c204c49e5 | ||
|
erwincoumans
|
327336d80b | ||
|
erwincoumans
|
dad061fc13 | ||
|
erwincoumans
|
daadfacfff | ||
|
erwincoumans
|
fd2fe1365a | ||
|
Matt Bennice
|
ee0100abbf | ||
|
Matt Bennice
|
555c0c6cd9 | ||
|
Matt Bennice
|
82b7fa6df0 | ||
|
Matt Bennice
|
c7a67d509e | ||
|
Hill Ma
|
dfdb6e2db9 | ||
|
Vitaly Buka
|
acbeea543b | ||
|
Sho Yamanishi
|
d19a418728 | ||
|
Vitaly Buka
|
6626ed1a89 | ||
|
erwincoumans
|
a1d96646c8 | ||
|
erwincoumans
|
466b76680b | ||
|
erwincoumans
|
19aa740d84 | ||
|
Erwin Coumans
|
4ca2de2fd7 | ||
|
Erwin Coumans
|
7ba2965a22 | ||
|
Erwin Coumans
|
56186db344 | ||
|
erwincoumans
|
2ad5f5a7d7 | ||
|
Erwin Coumans
|
b9df2190f1 | ||
|
Rémi Verschelde
|
cc3f3cf7ca | ||
|
erwincoumans
|
7dee3436e7 | ||
|
Erwin Coumans
|
657f347223 | ||
|
erwin coumans
|
fdab95dbab | ||
|
erwin coumans
|
a899725cc6 | ||
|
Erwin Coumans
|
ae4c1f8e72 | ||
|
erwin coumans
|
9185f93174 | ||
|
erwincoumans
|
e95657f80f | ||
|
Erwin Coumans
|
9eb945b1e8 | ||
|
Erwin Coumans
|
968b4356dc | ||
|
Erwin Coumans
|
957a46d840 | ||
|
Erwin Coumans
|
a3ec165915 | ||
|
erwincoumans
|
617df44898 | ||
|
erwincoumans
|
ce23bb9dce | ||
|
Erwin Coumans
|
f263c422e2 | ||
|
Erwin Coumans
|
31b9be82a1 | ||
|
erwincoumans
|
0edcbd693a | ||
|
Sebastian Jura
|
2a8d463fd3 | ||
|
Erwin Coumans
|
4f0673810c | ||
|
erwincoumans
|
cd771af26f | ||
|
erwincoumans
|
31aeeadb2d | ||
|
Szabolcs Dombi
|
aef1d3e27d | ||
|
Raphael Isemann
|
772dcf57ff | ||
|
erwincoumans
|
e306b274f1 | ||
|
Daniele Bartolini
|
66012fe215 | ||
|
Erwin Coumans
|
d3b4c27db4 | ||
|
erwincoumans
|
22d9eec148 | ||
|
Erwin Coumans
|
5e8a4717b9 | ||
|
erwincoumans
|
ae885be38d | ||
|
Erwin Coumans
|
0070e0d52b | ||
|
erwincoumans
|
5d75748c0d | ||
|
erwincoumans
|
b9117c780f | ||
|
erwincoumans
|
c07f6f66e8 | ||
|
erwincoumans
|
c0c03f279a | ||
|
Pawel
|
5e8343cffe | ||
|
Sandy Carter
|
35264f81bb | ||
|
Sandy
|
e4414c8023 | ||
|
Roker2
|
072439b8eb | ||
|
erwincoumans
|
ea715cc3b3 | ||
|
erwincoumans
|
6c300fbeee | ||
|
Chuyuan Kelly Fu
|
d63a721eaa | ||
|
Chuyuan Kelly Fu
|
158eb6d63b | ||
|
Erwin Coumans
|
e942db6f4d | ||
|
erwincoumans
|
e576dbe92c | ||
|
erwincoumans
|
4fbecfeddc | ||
|
erwincoumans
|
aee1ab63fe | ||
|
erwincoumans
|
3df6e1a721 | ||
|
erwincoumans
|
a8e1ce8273 | ||
|
erwincoumans
|
2e4e25b330 | ||
|
erwincoumans
|
6b35174ea9 | ||
|
erwincoumans
|
2b685e98ee | ||
|
Erwin Coumans
|
e262b2b7ee | ||
|
Erwin Coumans
|
3315190d97 | ||
|
Erwin Coumans
|
90414a5074 | ||
|
erwincoumans
|
b74bdfbbcf | ||
|
erwincoumans
|
0c40b73b0e | ||
|
erwincoumans
|
103db13379 | ||
|
erwincoumans
|
0ec6091efb | ||
|
erwincoumans
|
e32c0674e7 | ||
|
erwincoumans
|
34a471586e | ||
|
Erwin Coumans
|
dd93f73fc4 | ||
|
Chuyuan Kelly Fu
|
3fd61413df | ||
|
Chuyuan Kelly Fu
|
cf185a2d53 | ||
|
Chuyuan Kelly Fu
|
c9fe6638f8 | ||
|
tarsin
|
187b2bbc68 | ||
|
Chuyuan Kelly Fu
|
a8cf6008b7 | ||
|
Chuyuan Kelly Fu
|
c014789db0 | ||
|
Chuyuan Kelly Fu
|
4b12767b60 | ||
|
Chuyuan Kelly Fu
|
3088db22a2 | ||
|
jingyuc
|
5fd7ec99ba | ||
|
jingyuc
|
2c1cd798ea | ||
|
Jingyu Chen
|
e9a78e460c | ||
|
jingyuc
|
ca9d9b3ee6 | ||
|
erwincoumans
|
9f3c4123a2 | ||
|
jingyuc
|
c89a7054e9 | ||
|
Erwin Coumans
|
28b951c128 | ||
|
erwincoumans
|
267f983498 | ||
|
r-a-sattarov
|
6038bb2993 | ||
|
erwincoumans
|
58cde7b598 | ||
|
Erwin Coumans
|
9bfca83a8f | ||
|
Tigran Gasparian
|
d26dbef2dc | ||
|
erwincoumans
|
88651395b7 | ||
|
Chris E. Mower
|
713392b789 | ||
|
Peng Xu
|
19d6304d8d | ||
|
Peng Xu
|
751fd3fb65 | ||
|
jingyuc
|
41ce1cca24 | ||
|
Chuyuan Kelly Fu
|
60b6df94d9 | ||
|
Chuyuan Kelly Fu
|
372c8e07bc | ||
|
Chuyuan Kelly Fu
|
548d6af901 | ||
|
Chuyuan Kelly Fu
|
807cf3d387 | ||
|
Chuyuan Kelly Fu
|
bdba9fa2e0 | ||
|
Chuyuan Kelly Fu
|
4e5b3f34c9 | ||
|
Chuyuan Kelly Fu
|
450c95d0b9 | ||
|
Chuyuan Kelly Fu
|
236d39d2ec | ||
|
Chuyuan Kelly Fu
|
07de08a38e | ||
|
Chuyuan Kelly Fu
|
fb3b306af1 | ||
|
erwincoumans
|
9eac022ffa | ||
|
erwincoumans
|
22ef34bb69 | ||
|
Jingyu Chen
|
ca334946a7 | ||
|
jaecheol.sim
|
7d7fb1e291 | ||
|
Jingyu Chen
|
c159305910 | ||
|
erwincoumans
|
2cad239c00 | ||
|
Erwin Coumans
|
256fe2ec70 | ||
|
erwincoumans
|
f0f2a952e1 | ||
|
jingyuc
|
f8abdd1fe1 | ||
|
jingyuc
|
11b79c3838 | ||
|
jingyuc
|
cf7b142063 | ||
|
jingyuc
|
6a78b4bb07 | ||
|
jingyuc
|
bfef75f871 | ||
|
jingyuc
|
fbeafa0249 | ||
|
Erwin Coumans
|
6906198132 | ||
|
Erwin Coumans
|
5cd8160086 | ||
|
Erwin Coumans
|
b602045665 | ||
|
Erwin Coumans
|
6cc267f84b | ||
|
Peter
|
2a5a1d4935 | ||
|
Jelle
|
06a212e667 | ||
|
erwincoumans
|
478da7469a | ||
|
erwincoumans
|
dc72081eb1 | ||
|
Erwin Coumans
|
5d1c8a2ece | ||
|
James Braza
|
51a5aa8026 | ||
|
James Braza
|
0e114e9f9b | ||
|
James Braza
|
72dc1bb4dd | ||
|
James Braza
|
878e3d57f6 | ||
|
erwincoumans
|
f84b523c05 | ||
|
Erwin Coumans
|
0ab3b9d9f7 | ||
|
erwincoumans
|
0fac8209c9 | ||
|
Erwin Coumans
|
610fb2c117 | ||
|
Erwin Coumans
|
0aecbb9cdc | ||
|
Jingyu Chen
|
c9a2d733ad | ||
|
Jingyu Chen
|
f19133e410 | ||
|
Jingyu Chen
|
1feb81463a | ||
|
erwincoumans
|
578523eab4 | ||
|
jingyuc
|
4634077733 | ||
|
jyc-n
|
a018d63fb3 | ||
|
erwincoumans
|
6a59241074 | ||
|
Erwin Coumans
|
9c380f18f6 | ||
|
jingyuc
|
96605f7a8c | ||
|
erwincoumans
|
fa50f195e6 | ||
|
Chase Kew
|
adf75169d8 | ||
|
jingyuc
|
6fb7bd9a94 | ||
|
jingyuc
|
f729fbda95 | ||
|
jingyuc
|
9fae47667b | ||
|
jingyuc
|
8efd0296ab | ||
|
jingyuc
|
bc8adf7bd1 | ||
|
jingyuc
|
4c9d6275aa | ||
|
jingyuc
|
0b641b51d7 | ||
|
erwincoumans
|
946d500c8e | ||
|
jingyuc
|
0279a5a500 | ||
|
jingyuc
|
8c118515b8 | ||
|
jingyuc
|
007eea15cb | ||
|
jingyuc
|
2d08d4047a | ||
|
jingyuc
|
18f81dcaea | ||
|
jingyuc
|
676221fb3e | ||
|
erwincoumans
|
10f72b9b5d | ||
|
erwincoumans
|
ccafe333d1 | ||
|
erwincoumans
|
691ad46baa | ||
|
erwincoumans
|
a9a103fc8c | ||
|
erwincoumans
|
40aeecb72e | ||
|
erwincoumans
|
88c04a8eae | ||
|
Erwin Coumans
|
a3005879bb | ||
|
Erwin Coumans
|
e3b98615f1 | ||
|
jingyuc
|
c2072b5538 | ||
|
Erwin Coumans
|
a84071ee67 | ||
|
Erwin Coumans
|
6088293149 | ||
|
jingyuc
|
7fafbd7718 | ||
|
jingyuc
|
e386b55543 | ||
|
erwincoumans
|
98254b51a9 | ||
|
jingyuc
|
3ec4d68323 | ||
|
jingyuc
|
0a6f278663 | ||
|
jingyuc
|
d7fb9e8a92 | ||
|
jingyuc
|
df661fde15 | ||
|
Chuyuan Fu
|
a2aada62ae | ||
|
erwincoumans
|
a62fb187a5 | ||
|
erwincoumans
|
1dd3d8408e | ||
|
QiaodongCui
|
a672536f43 | ||
|
QiaodongCui
|
e9d40d0726 | ||
|
Stephen Tu
|
63446558cd | ||
|
jingyuc
|
2255e26e14 | ||
|
erwincoumans
|
ac3c283842 | ||
|
jingyuc
|
3540400a9d | ||
|
jingyuc
|
88863f92eb | ||
|
Tigran Gasparian
|
740d2b9783 | ||
|
jingyuc
|
e2f6430d19 | ||
|
Kentaro Wada
|
fd98afe764 | ||
|
Kentaro Wada
|
b22a2432b5 | ||
|
Erwin Coumans
|
1a670681f7 | ||
|
Erwin Coumans
|
e1ac14b23d | ||
|
erwincoumans
|
e4a450a53d | ||
|
erwincoumans
|
33cceed500 | ||
|
erwincoumans
|
d4598bf1cf | ||
|
erwincoumans
|
f79463b699 | ||
|
erwincoumans
|
aef54fed64 | ||
|
Max Argus
|
3c4cb80157 | ||
|
jingyuc
|
b5325a265f | ||
|
jingyuc
|
3a3d8c7a3a | ||
|
Johannes Brust
|
61d5bdb783 | ||
|
Kentaro Wada
|
00dcce85f5 | ||
|
jingyuc
|
d945e48af2 | ||
|
Wenhao Yu
|
af0bfc62ec | ||
|
Wenhao Yu
|
fd96062972 | ||
|
erwincoumans
|
48dc1c45da | ||
|
Erwin Coumans
|
90e331a239 | ||
|
Erwin Coumans
|
a8f088d4d3 | ||
|
Erwin Coumans
|
00567a5261 | ||
|
erwincoumans
|
aa49e19385 | ||
|
jingyuc
|
bd6e49bcc1 | ||
|
jingyuc
|
07cfa9a433 | ||
|
Rémi Verschelde
|
41f03e78a5 | ||
|
Erwin Coumans
|
6390db4bd6 | ||
|
jingyuc
|
1949710131 | ||
|
jingyuc
|
c4da596778 | ||
|
Erwin Coumans
|
931f93d266 | ||
|
Erwin Coumans
|
9d211393e4 | ||
|
Erwin Coumans
|
34d77242e5 | ||
|
Ariel Kwiatkowski
|
496e614f77 | ||
|
Rémi Verschelde
|
364796d1e5 | ||
|
Rémi Verschelde
|
ba65e909bc | ||
|
Johannes Brust
|
5795bd676f | ||
|
jingyuc
|
1bee1ba4c4 | ||
|
jingyuc
|
354c5a6e62 | ||
|
jingyuc
|
107c5526eb | ||
|
jingyuc
|
5e0a805d73 | ||
|
jingyuc
|
9de3d25172 | ||
|
erwincoumans
|
ce26271923 | ||
|
erwincoumans
|
cc84887919 | ||
|
erwincoumans
|
289a1b3f6e | ||
|
erwincoumans
|
9c37ca5185 | ||
|
erwincoumans
|
c57d6f0163 | ||
|
Erwin Coumans
|
143f87abcf | ||
|
erwincoumans
|
47c3f5e994 | ||
|
Erwin Coumans
|
87605ca4c8 | ||
|
Brendan L
|
9675e3d39b | ||
|
jingyuc
|
064fdc40bd | ||
|
erwincoumans
|
101c98cfb8 | ||
|
jingyuc
|
bfd3d1cd8d | ||
|
jingyuc
|
19375d6569 | ||
|
jingyuc
|
593f387a06 | ||
|
Aaron Franke
|
ad74cfe6c8 | ||
|
jingyuc
|
1c8afcf54f | ||
|
jingyuc
|
b4efd91476 | ||
|
jingyuc
|
9d1aafc51c | ||
|
jingyuc
|
e62c42f54c | ||
|
jingyuc
|
ce765a8a88 | ||
|
jingyuc
|
eef3b73cd2 | ||
|
jingyuc
|
3a70641c65 | ||
|
jingyuc
|
3a84b05058 | ||
|
Brendan Lewis
|
b1927a4f92 | ||
|
Erwin Coumans
|
4e881118ef | ||
|
jingyuc
|
df07b42318 | ||
|
jingyuc
|
f2e114fc81 | ||
|
jingyuc
|
e70fc6453b | ||
|
erwincoumans
|
b638300fe4 | ||
|
Erwin Coumans
|
b6df08b553 | ||
|
jingyuc
|
93e00054e3 | ||
|
Felix Büttner
|
4b6ec20b30 | ||
|
jingyuc
|
104410c63d | ||
|
erwin coumans
|
3577ef8108 | ||
|
erwin coumans
|
7de63bdbc5 | ||
|
erwincoumans
|
3fee64fb95 | ||
|
jingyuc
|
c2601663e4 | ||
|
Chuyuan Fu
|
9b3c8c8dbb | ||
|
Chuyuan Fu
|
b795243cc5 | ||
|
jingyuc
|
634c8b7b38 | ||
|
jingyuc
|
42fac2e364 | ||
|
erwincoumans
|
31b8841efc | ||
|
Erwin Coumans
|
68424feb2d | ||
|
jingyuc
|
b1803afbb9 | ||
|
erwincoumans
|
5ec0820c0e | ||
|
jingyuc
|
3e76b11d46 | ||
|
jingyuc
|
f26e3d133d | ||
|
jingyuc
|
6a87310d3c | ||
|
jingyuc
|
52abe35e41 | ||
|
Brendan Lewis
|
090f8369f8 | ||
|
jingyuc
|
166dc2865d | ||
|
jingyuc
|
c735830f0a | ||
|
jingyuc
|
840db372b9 | ||
|
erwincoumans
|
41158a4be8 | ||
|
jingyuc
|
d9152b9cf5 | ||
|
jingyuc
|
368385d5ad | ||
|
Chuyuan Fu
|
107295db5f | ||
|
Chuyuan Fu
|
e16c9bb1cc | ||
|
jingyuc
|
70ec2f9d46 | ||
|
jingyuc
|
0444fea9eb | ||
|
erwin coumans
|
7ac95be8cd | ||
|
jingyuc
|
eacdbe67a0 | ||
|
jingyuc
|
9a17391a9a | ||
|
jyc-n
|
d6d8c3ceac | ||
|
jingyuc
|
35f7a1a569 | ||
|
jingyuc
|
e4e8f1ad93 | ||
|
jingyuc
|
6355b06a8b | ||
|
jyc-n
|
3425c01acc | ||
|
jyc-n
|
042a1f75c9 | ||
|
jingyuc
|
a56ce358f3 | ||
|
jingyuc
|
0acf18f246 | ||
|
notrabs
|
b2fd9a492d | ||
|
Fabrice Fontaine
|
dd37b97e79 | ||
|
jingyuc
|
4f66d8bb87 | ||
|
jyc-n
|
252aa91e9a | ||
|
jingyuc
|
32398d4d7f | ||
|
jingyuc
|
fdfb08b72f | ||
|
erwin coumans
|
e399944982 | ||
|
jingyuc
|
35ec8b39a7 | ||
|
jingyuc
|
a37d23fa24 | ||
|
Ayzaan Wahid
|
83fbd60d5b | ||
|
jingyuc
|
5d17353269 | ||
|
Antonin Raffin
|
13f3778c22 | ||
|
Antonin Raffin
|
2f8b44c702 | ||
|
jingyuc
|
c6c7533167 | ||
|
jingyuc
|
549b57df77 | ||
|
jingyuc
|
6c2023e330 | ||
|
jyc-n
|
bfa74dbacd | ||
|
jingyuc
|
67b58428e8 | ||
|
jingyuc
|
24eb021ed6 | ||
|
jyc-n
|
0983d36eff | ||
|
jyc-n
|
7678545e76 | ||
|
jingyuc
|
9baee29300 | ||
|
jingyuc
|
6f3dd32f37 | ||
|
jyc-n
|
87e20f450b | ||
|
jyc-n
|
c325da8b34 | ||
|
jyc-n
|
45c3db58ff | ||
|
jingyuc
|
49d7bb0301 | ||
|
jingyuc
|
237333d030 | ||
|
jingyuc
|
f6dbbd4e66 | ||
|
jingyuc
|
4119d8812e | ||
|
jingyuc
|
c24f2a72ef | ||
|
jingyuc
|
4b6eaeed4c | ||
|
jingyuc
|
d390360f9e | ||
|
jingyuc
|
f1e86bf257 | ||
|
jingyuc
|
fa00ee2bbd | ||
|
jingyuc
|
a3dc901696 | ||
|
PouleyKetchoupp
|
2045f04f3c | ||
|
erwincoumans
|
0e124cb2f1 | ||
|
erwincoumans
|
a435fb7a41 | ||
|
erwincoumans
|
3e0a211868 | ||
|
Erwin Coumans
|
92fb2db0a3 | ||
|
Chuyuan Fu
|
88112560a1 | ||
|
erwincoumans
|
ebe1916b90 | ||
|
Erwin Coumans
|
092b7bc3d9 | ||
|
erwincoumans
|
39d981bce6 | ||
|
erwin coumans
|
adcf785a4a | ||
|
Erwin Coumans
|
cd76d605a9 | ||
|
erwin coumans
|
f14911c998 | ||
|
erwin coumans
|
e952ac6f63 | ||
|
erwin coumans
|
8e85dedaa9 | ||
|
erwin coumans
|
e4ff5a45d4 | ||
|
erwin coumans
|
b696ed7d7b | ||
|
cadop
|
ace34c4d08 | ||
|
erwincoumans
|
00cd39dc50 | ||
|
Andrea Catania
|
c0efe069c5 | ||
|
erwincoumans
|
c74d5e322f | ||
|
erwincoumans
|
8aab71a86e | ||
|
Erwin Coumans
|
d70c3cfdc8 | ||
|
Erwin Coumans
|
18c62ed725 | ||
|
erwincoumans
|
7f7238f630 | ||
|
erwin coumans
|
a142e8d174 | ||
|
erwin coumans
|
3b2e46e7dd | ||
|
erwincoumans
|
e0b9bc6d7f | ||
|
Erwin Coumans
|
1f6baad974 | ||
|
Erwin Coumans
|
85a03bf999 | ||
|
Erwin Coumans
|
fc2992b75a | ||
|
erwin coumans
|
6cb72b5128 | ||
|
erwin coumans
|
46ea89a284 | ||
|
erwincoumans
|
45d3ead747 | ||
|
Erwin Coumans
|
184b7816d0 | ||
|
erwincoumans
|
a7832e3a18 | ||
|
erwincoumans
|
afb572166a | ||
|
Erwin Coumans
|
c915e82d49 | ||
|
Matt Bennice
|
225fa20944 | ||
|
Erwin Coumans
|
83a5fe2d31 | ||
|
erwincoumans
|
00dcc77885 | ||
|
erwin coumans
|
a5761f2b10 | ||
|
Erwin Coumans
|
9f91e6837a | ||
|
erwincoumans
|
5c2fa7009b | ||
|
erwincoumans
|
201e7159d6 | ||
|
erwincoumans
|
f774a102ee | ||
|
erwin coumans
|
e58e5bdf95 | ||
|
erwin coumans
|
fd154cee8f | ||
|
erwin coumans
|
78f5b141f9 | ||
|
erwin coumans
|
84a63cf221 | ||
|
r-a-sattarov
|
a923ce184e | ||
|
erwincoumans
|
48ba5a37ad | ||
|
erwin coumans
|
910c20334f | ||
|
Alexander Turkin
|
f26e858154 | ||
|
Alexander Turkin
|
f04768ecc4 | ||
|
erwincoumans
|
5ae9a15eca | ||
|
erwincoumans
|
049d13d190 | ||
|
erwincoumans
|
0a8e4f3f6c | ||
|
Erwin Coumans
|
973d8c128f | ||
|
erwincoumans
|
0478d10099 | ||
|
jaraujo98
|
dcf9c8d6a5 | ||
|
erwincoumans
|
21d1b8fc71 | ||
|
Erwin Coumans
|
5205dafcc2 | ||
|
Erwin Coumans
|
29f388a5d8 | ||
|
Erwin Coumans
|
513e3a7db4 | ||
|
Erwin Coumans
|
674c82db89 | ||
|
erwincoumans
|
7ec009ec50 | ||
|
erwincoumans
|
2c3318f86d | ||
|
erwin coumans
|
8b8c1af6a4 | ||
|
erwin coumans
|
4d34ba7310 | ||
|
Erwin Coumans
|
58d47935a3 | ||
|
erwin coumans
|
d1c4c41b9a | ||
|
erwincoumans
|
93be7e6440 | ||
|
erwin coumans
|
0196edd4d2 | ||
|
Kieren
|
c810edf483 | ||
|
erwin coumans
|
546212b158 | ||
|
Chris Djali
|
6e2577ca59 | ||
|
erwin coumans
|
6f7d458679 | ||
|
erwincoumans
|
395e17c7bf | ||
|
erwin coumans
|
5cf8ee3360 | ||
|
erwin coumans
|
0b8f95598d | ||
|
erwincoumans
|
87e668f6b2 | ||
|
erwincoumans
|
2bd7fa7064 | ||
|
Erwin Coumans
|
5864901a2e | ||
|
erwincoumans
|
0c7ea68709 | ||
|
erwincoumans
|
0bf5f2cd84 | ||
|
mbennice
|
296cd85f60 | ||
|
mbennice
|
237843b93a | ||
|
Gleb Mazovetskiy
|
89c76981fc | ||
|
Gleb Mazovetskiy
|
40a9584ccb | ||
|
Gleb Mazovetskiy
|
8f5a00dd1e | ||
|
Gleb Mazovetskiy
|
bb838dbec0 | ||
|
Gleb MazovetskiyandAndrew Shulaev
|
e7e28bebf8 | ||
|
Gleb MazovetskiyandAndrew Shulaev
|
782f14caa1 | ||
|
Alexander Turkin
|
7aff26b80d | ||
|
daniel.ordonez
|
f719c27b04 | ||
|
yycho0108
|
6f65a12b3a | ||
|
yycho0108
|
c0d9553d65 | ||
|
Nan Jiang
|
46519720eb |
@@ -0,0 +1,38 @@
|
||||
name: CMake
|
||||
|
||||
on:
|
||||
push:
|
||||
branches: [ master ]
|
||||
pull_request:
|
||||
branches: [ master ]
|
||||
|
||||
env:
|
||||
# Customize the CMake build type here (Release, Debug, RelWithDebInfo, etc.)
|
||||
BUILD_TYPE: Release
|
||||
|
||||
jobs:
|
||||
build:
|
||||
# The CMake configure and build commands are platform agnostic and should work equally
|
||||
# well on Windows or Mac. You can convert this to a matrix build if you need
|
||||
# cross-platform coverage.
|
||||
# See: https://docs.github.com/en/free-pro-team@latest/actions/learn-github-actions/managing-complex-workflows#using-a-build-matrix
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- uses: actions/checkout@v2
|
||||
|
||||
- name: Configure CMake
|
||||
# Configure CMake in a 'build' subdirectory. `CMAKE_BUILD_TYPE` is only required if you are using a single-configuration generator such as make.
|
||||
# See https://cmake.org/cmake/help/latest/variable/CMAKE_BUILD_TYPE.html?highlight=cmake_build_type
|
||||
run: cmake -B ${{github.workspace}}/build -DCMAKE_BUILD_TYPE=${{env.BUILD_TYPE}}
|
||||
|
||||
- name: Build
|
||||
# Build your program with the given configuration
|
||||
run: cmake --build ${{github.workspace}}/build --config ${{env.BUILD_TYPE}}
|
||||
|
||||
- name: Test
|
||||
working-directory: ${{github.workspace}}/build
|
||||
# Execute tests defined by the CMake configuration.
|
||||
# See https://cmake.org/cmake/help/latest/manual/ctest.1.html for more detail
|
||||
run: ctest -C ${{env.BUILD_TYPE}}
|
||||
|
||||
@@ -36,3 +36,7 @@ CTestTestFile.cmake
|
||||
|
||||
# vim temp files
|
||||
*.swp
|
||||
|
||||
.vscode/
|
||||
.idea/
|
||||
cmake-build-debug/
|
||||
|
||||
-46
@@ -1,46 +0,0 @@
|
||||
language: cpp
|
||||
matrix:
|
||||
include:
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=TRUSTY_CLANG
|
||||
- SUDO=sudo
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=XENIAL_CLANG
|
||||
- DOCKER_FILE="ubuntu-xenial"
|
||||
services: docker
|
||||
- os: linux
|
||||
compiler: gcc
|
||||
env:
|
||||
- BUILD_NAME=BIONIC_GCC
|
||||
- DOCKER_FILE="ubuntu-bionic"
|
||||
services: docker
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=BIONIC_CLANG
|
||||
- DOCKER_FILE="ubuntu-bionic"
|
||||
services: docker
|
||||
- os: osx
|
||||
compiler: gcc
|
||||
env:
|
||||
- BUILD_NAME=OSX_GCC
|
||||
- os: osx
|
||||
compiler: clang
|
||||
env:
|
||||
- COMPILER=clang++
|
||||
- BUILD_NAME=OSX_CLANG
|
||||
before_install:
|
||||
- if [ -n "$DOCKER_FILE" ]; then
|
||||
docker build -t "$DOCKER_FILE" -f ".ci/docker/$DOCKER_FILE" .;
|
||||
docker run -itd -v $TRAVIS_BUILD_DIR:$TRAVIS_BUILD_DIR --env-file .ci/docker/env.list --name bullet-docker "$DOCKER_FILE";
|
||||
fi
|
||||
script:
|
||||
- if [ -n "$DOCKER_FILE" ]; then
|
||||
docker exec bullet-docker /bin/sh -c "cd $TRAVIS_BUILD_DIR && ./.ci/script.sh";
|
||||
else
|
||||
'.ci/script.sh';
|
||||
fi
|
||||
+1
-1
@@ -1,4 +1,4 @@
|
||||
cmake_minimum_required(VERSION 2.4.3)
|
||||
cmake_minimum_required(VERSION 3.5)
|
||||
set(CMAKE_ALLOW_LOOSE_LOOP_CONSTRUCTS true)
|
||||
cmake_policy(SET CMP0017 NEW)
|
||||
#this line has to appear before 'PROJECT' in order to be able to disable incremental linking
|
||||
|
||||
@@ -304,6 +304,7 @@ INSTALL (
|
||||
ENDIF (APPLE AND BUILD_SHARED_LIBS AND FRAMEWORK)
|
||||
|
||||
IF(NOT MSVC)
|
||||
SET(PKGCONFIG_INSTALL_PREFIX "lib${LIB_SUFFIX}/pkgconfig/" CACHE STRING "Base directory for pkgconfig files")
|
||||
CONFIGURE_FILE(${CMAKE_CURRENT_SOURCE_DIR}/bullet_robotics.pc.cmake
|
||||
${CMAKE_CURRENT_BINARY_DIR}/bullet_robotics.pc @ONLY)
|
||||
INSTALL(
|
||||
|
||||
@@ -183,6 +183,7 @@ ENDIF (BUILD_SHARED_LIBS)
|
||||
ENDIF (APPLE AND BUILD_SHARED_LIBS AND FRAMEWORK)
|
||||
|
||||
IF(NOT MSVC)
|
||||
SET(PKGCONFIG_INSTALL_PREFIX "lib${LIB_SUFFIX}/pkgconfig/" CACHE STRING "Base directory for pkgconfig files")
|
||||
CONFIGURE_FILE(${CMAKE_CURRENT_SOURCE_DIR}/bullet_robotics_gui.pc.cmake
|
||||
${CMAKE_CURRENT_BINARY_DIR}/bullet_robotics_gui.pc @ONLY)
|
||||
INSTALL(
|
||||
|
||||
+32
-1
@@ -1,5 +1,36 @@
|
||||
SUBDIRS( InverseDynamics BulletRoboticsGUI BulletRobotics obj2sdf Serialize ConvexDecomposition HACD GIMPACTUtils )
|
||||
OPTION(BUILD_INVERSE_DYNAMIC_EXTRA "Build InverseDynamic extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_GUI_EXTRA "Build BulletRoboticsGUI extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_EXTRA "Build BulletRobotics extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_OBJ2SDF_EXTRA "Build obj2sdf extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_SERIALIZE_EXTRA "Build Serialize extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_CONVEX_DECOMPOSITION_EXTRA "Build ConvexDecomposition extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_HACD_EXTRA "Build HACD extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_GIMPACTUTILS_EXTRA "Build GIMPACTUtils extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
|
||||
IF(BUILD_INVERSE_DYNAMIC_EXTRA)
|
||||
SUBDIRS( InverseDynamics )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_GUI_EXTRA)
|
||||
SUBDIRS( BulletRoboticsGUI )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_EXTRA)
|
||||
SUBDIRS( BulletRobotics )
|
||||
ENDIF()
|
||||
IF(BUILD_OBJ2SDF_EXTRA)
|
||||
SUBDIRS( obj2sdf )
|
||||
ENDIF()
|
||||
IF(BUILD_SERIALIZE_EXTRA)
|
||||
SUBDIRS( Serialize )
|
||||
ENDIF()
|
||||
IF(BUILD_CONVEX_DECOMPOSITION_EXTRA)
|
||||
SUBDIRS( ConvexDecomposition )
|
||||
ENDIF()
|
||||
IF(BUILD_HACD_EXTRA)
|
||||
SUBDIRS( HACD )
|
||||
ENDIF()
|
||||
IF(BUILD_GIMPACTUTILS_EXTRA)
|
||||
SUBDIRS( GIMPACTUtils )
|
||||
ENDIF()
|
||||
|
||||
|
||||
#Maya Dynamica plugin is moved to http://dynamica.googlecode.com
|
||||
|
||||
@@ -75,6 +75,7 @@ bFile::bFile(const char *filename, const char headerString[7])
|
||||
fseek(fp, 0L, SEEK_SET);
|
||||
|
||||
mFileBuffer = (char *)malloc(mFileLen + 1);
|
||||
memset(mFileBuffer, 0, mFileLen+1);
|
||||
size_t bytesRead;
|
||||
bytesRead = fread(mFileBuffer, mFileLen, 1, fp);
|
||||
|
||||
@@ -736,7 +737,7 @@ void bFile::parseStruct(char *strcPtr, char *dtPtr, int old_dna, int new_dna, bo
|
||||
if (new_dna == -1) return;
|
||||
|
||||
//disable this, because we need to fixup pointers/ListBase
|
||||
if (0) //mFileDNA->flagEqual(old_dna))
|
||||
if (/* DISABLES CODE */ (0)) //mFileDNA->flagEqual(old_dna))
|
||||
{
|
||||
short *strc = mFileDNA->getStruct(old_dna);
|
||||
int len = mFileDNA->getLength(strc[0]);
|
||||
|
||||
@@ -333,6 +333,7 @@ void btBulletFile::parse(int verboseMode)
|
||||
if (m_DnaCopy)
|
||||
delete m_DnaCopy;
|
||||
m_DnaCopy = (char*)btAlignedAlloc(sBulletDNAlen64, 16);
|
||||
memset(m_DnaCopy, 0, sBulletDNAlen64);
|
||||
memcpy(m_DnaCopy, sBulletDNAstr64, sBulletDNAlen64);
|
||||
parseInternal(verboseMode, m_DnaCopy, sBulletDNAlen64);
|
||||
}
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2011 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2011 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -69,7 +69,7 @@
|
||||
#include <pthread.h>
|
||||
#endif
|
||||
|
||||
#if defined(__APPLE__)
|
||||
#if defined(__APPLE__) || !defined(__GLIBC__)
|
||||
#define PTHREAD_MUTEX_RECURSIVE_NP PTHREAD_MUTEX_RECURSIVE
|
||||
#endif
|
||||
|
||||
|
||||
+12
-12
@@ -30,13 +30,13 @@
|
||||
#include "Bullet3Common/b3HashMap.h"
|
||||
#include "../Utils/b3BulletDefaultFileIO.h"
|
||||
|
||||
using tinyobj::index_t;
|
||||
using bt_tinyobj::index_t;
|
||||
|
||||
struct ShapeContainer
|
||||
{
|
||||
std::string m_matName;
|
||||
std::string m_shapeName;
|
||||
tinyobj::material_t material;
|
||||
bt_tinyobj::material_t material;
|
||||
std::vector<float> positions;
|
||||
std::vector<float> normals;
|
||||
std::vector<float> texcoords;
|
||||
@@ -91,11 +91,11 @@ int main(int argc, char* argv[])
|
||||
char materialPrefixPath[MAX_PATH_LEN];
|
||||
b3FileUtils::extractPath(fileNameWithPath, materialPrefixPath, MAX_PATH_LEN);
|
||||
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
|
||||
b3BulletDefaultFileIO fileIO;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, fileNameWithPath, materialPrefixPath,&fileIO);
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, fileNameWithPath, materialPrefixPath, &fileIO);
|
||||
|
||||
char sdfFileName[MAX_PATH_LEN];
|
||||
sprintf(sdfFileName, "%s%s.sdf", materialPrefixPath, "newsdf");
|
||||
@@ -110,8 +110,8 @@ int main(int argc, char* argv[])
|
||||
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
tinyobj::material_t mat = shape.material;
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::material_t mat = shape.material;
|
||||
|
||||
b3HashString key = mat.name.length() ? mat.name.c_str() : "";
|
||||
if (!gMaterialNames.find(key))
|
||||
@@ -212,7 +212,7 @@ int main(int argc, char* argv[])
|
||||
|
||||
int faceCount = shapeCon->indices.size();
|
||||
int vertexCount = shapeCon->positions.size();
|
||||
tinyobj::material_t mat = shapeCon->material;
|
||||
bt_tinyobj::material_t mat = shapeCon->material;
|
||||
if (shapeCon->m_matName.length())
|
||||
{
|
||||
const char* objName = shapeCon->m_matName.c_str();
|
||||
@@ -271,7 +271,7 @@ int main(int argc, char* argv[])
|
||||
fprintf(sdfFile,
|
||||
"\t\t<model name='%s'>\n"
|
||||
"\t\t\t<static>1</static>\n"
|
||||
"\t\t\t<pose frame=''>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<pose >0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<link name='link_d%d'>\n"
|
||||
"\t\t\t<inertial>\n"
|
||||
"\t\t\t<mass>0</mass>\n"
|
||||
@@ -317,7 +317,7 @@ int main(int argc, char* argv[])
|
||||
{
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
|
||||
if (shape.name.length())
|
||||
{
|
||||
@@ -351,7 +351,7 @@ int main(int argc, char* argv[])
|
||||
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
int vertexCount = attribute.vertices.size();
|
||||
tinyobj::material_t mat = shape.material;
|
||||
bt_tinyobj::material_t mat = shape.material;
|
||||
if (shape.name.length())
|
||||
{
|
||||
const char* objName = shape.name.c_str();
|
||||
@@ -411,7 +411,7 @@ int main(int argc, char* argv[])
|
||||
fprintf(sdfFile,
|
||||
"\t\t<model name='%s'>\n"
|
||||
"\t\t\t<static>1</static>\n"
|
||||
"\t\t\t<pose frame=''>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<pose>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<link name='link_d%d'>\n"
|
||||
"\t\t\t<inertial>\n"
|
||||
"\t\t\t<mass>0</mass>\n"
|
||||
|
||||
@@ -7,8 +7,11 @@ This is the official C++ source code repository of the Bullet Physics SDK: real-
|
||||
|
||||
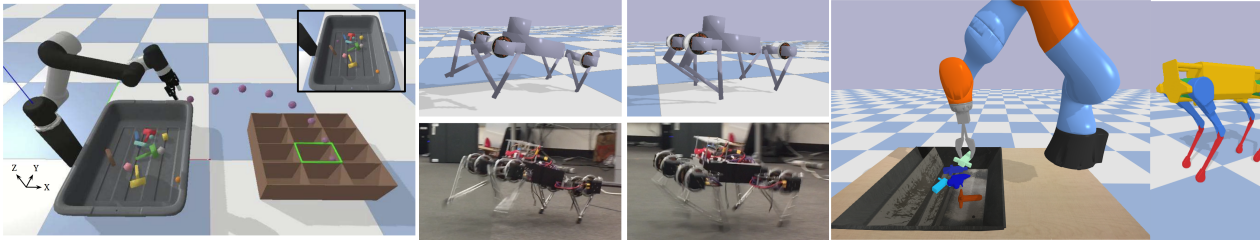
|
||||
|
||||
## Issues ##
|
||||
The Issue tracker was flooded with support questions and is closed until it is cleaned up. Use the [PyBullet forums](http://pybullet.org) to discuss with others.
|
||||
|
||||
## PyBullet ##
|
||||
New in Bullet 2.85: pybullet Python bindings, improved support for robotics and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
It is highly recommended to use PyBullet Python bindings for improved support for robotics, reinforcement learning and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
|
||||
Installation is simple:
|
||||
```
|
||||
@@ -21,11 +24,11 @@ python3 -m pybullet_envs.deep_mimic.testrl --arg_file run_humanoid3d_backflip_ar
|
||||
If you use PyBullet in your research, please cite it like this:
|
||||
|
||||
```
|
||||
@MISC{coumans2019,
|
||||
@MISC{coumans2021,
|
||||
author = {Erwin Coumans and Yunfei Bai},
|
||||
title = {PyBullet, a Python module for physics simulation for games, robotics and machine learning},
|
||||
howpublished = {\url{http://pybullet.org}},
|
||||
year = {2016--2019}
|
||||
year = {2016--2021}
|
||||
}
|
||||
```
|
||||
|
||||
@@ -63,7 +66,7 @@ You can download and install Bullet using the [vcpkg](https://github.com/Microso
|
||||
cd vcpkg
|
||||
./bootstrap-vcpkg.sh
|
||||
./vcpkg integrate install
|
||||
vcpkg install bullet3
|
||||
./vcpkg install bullet3
|
||||
|
||||
The Bullet port in vcpkg is kept up to date by Microsoft team members and community contributors. If the version is out of date, please [create an issue or pull request](https://github.com/Microsoft/vcpkg) on the vcpkg repository.
|
||||
|
||||
@@ -88,12 +91,12 @@ p.connect(p.SHARED_MEMORY) #or (p.TCP, "localhost", 6667) or (p.UDP, "192.168.86
|
||||
|
||||
**Linux and Mac OSX gnu make**
|
||||
|
||||
Make sure cmake is installed (sudo apt-get install cmake, brew install cmake, or https://cmake.org)
|
||||
Make sure gcc and cmake is installed (`sudo apt-get install build-essential` and `sudo apt-get install cmake` for Linux, `brew install cmake` for Mac, or https://cmake.org)
|
||||
|
||||
In a terminal type:
|
||||
|
||||
./build_cmake_pybullet_double.sh
|
||||
|
||||
```
|
||||
./build_cmake_pybullet_double.sh
|
||||
```
|
||||
This script will invoke cmake and build in the build_cmake directory. You can find pybullet in Bullet/examples/pybullet.
|
||||
The BulletExampleBrowser binary will be in Bullet/examples/ExampleBrowser.
|
||||
|
||||
@@ -101,15 +104,15 @@ You can also build Bullet using premake. There are premake executables in the bu
|
||||
Depending on your system (Linux 32bit, 64bit or Mac OSX) use one of the following lines
|
||||
Using premake:
|
||||
```
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
```
|
||||
Then
|
||||
```
|
||||
cd gmake
|
||||
make
|
||||
cd gmake
|
||||
make
|
||||
```
|
||||
|
||||
Note that on Linux, you need to use cmake to build pybullet, since the compiler has issues of mixing shared and static libraries.
|
||||
@@ -117,9 +120,9 @@ Note that on Linux, you need to use cmake to build pybullet, since the compiler
|
||||
**Mac OSX Xcode**
|
||||
|
||||
Click on build3/xcode4.command or in a terminal window execute
|
||||
|
||||
./premake_osx xcode4
|
||||
|
||||
```
|
||||
./premake_osx xcode4
|
||||
```
|
||||
## Usage
|
||||
|
||||
The App_ExampleBrowser executables will be located in the bin folder.
|
||||
|
||||
+29
-1
@@ -66,7 +66,27 @@
|
||||
trigger = "enable_static_vr_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/vrSyncPlugin)"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_test_plugin",
|
||||
description = "Statically link test plugin (in examples/SharedMemory/plugins/testPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_tiny_renderer__plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/tinyRendererPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_pd_control_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/pdControlPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_collision_filter_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/collisionFilterPlugin)"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_physx",
|
||||
@@ -319,6 +339,12 @@ end
|
||||
trigger = "no-test",
|
||||
description = "Disable all tests"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "test-bullet2",
|
||||
|
||||
description = "Enable Bullet2 LinearMath test"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
@@ -646,7 +672,9 @@ end
|
||||
end
|
||||
|
||||
if not _OPTIONS["no-test"] then
|
||||
if _OPTIONS["test-bullet2"] then
|
||||
include "../test/Bullet2"
|
||||
end
|
||||
|
||||
if not _OPTIONS["no-gtest"] then
|
||||
include "../test/gtest-1.7.0"
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
mkdir build_cmake
|
||||
cd build_cmake
|
||||
cmake -DBUILD_PYBULLET=ON -DUSE_DOUBLE_PRECISION=ON -DCMAKE_BUILD_TYPE=Release -DPYTHON_INCLUDE_DIR=c:\python-3.5.3.amd64\include -DPYTHON_LIBRARY=c:\python-3.5.3.amd64\libs\python35.lib -DPYTHON_DEBUG_LIBRARY=c:\python-3.5.3.amd64\libs\python35_d.lib -G "Visual Studio 16 2019" ..
|
||||
cmake -DBUILD_PYBULLET=ON -DUSE_DOUBLE_PRECISION=ON -DCMAKE_BUILD_TYPE=Release -DPYTHON_INCLUDE_DIR=c:\python38\include -DPYTHON_LIBRARY=c:\python38\libs\python38.lib -DPYTHON_DEBUG_LIBRARY=c:\python38\libs\python38.lib -G "Visual Studio 16 2019" ..
|
||||
start .
|
||||
+1
-1
@@ -1,7 +1,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='unit_box_0'>
|
||||
<pose frame=''>0 0 0.107 0 0 0</pose>
|
||||
<pose>0 0 0.107 0 0 0</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
<inertial>
|
||||
<mass>0.1</mass>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.26 3.14 0 0</pose>
|
||||
<pose>0 0 0.26 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -249,9 +249,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -264,7 +264,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -273,7 +273,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</joint>
|
||||
|
||||
<link name='finger_right'>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -319,7 +319,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -329,7 +329,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -345,7 +345,7 @@
|
||||
</joint>
|
||||
|
||||
<link name='finger_left'>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -359,7 +359,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -369,7 +369,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -3,11 +3,11 @@
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
|
||||
<pose frame=''>0 -2.3 2.1 0 0 0</pose>
|
||||
<pose>0 -2.3 2.1 0 0 0</pose>
|
||||
<link name='world'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -26,9 +26,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -41,7 +41,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -56,9 +56,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -70,7 +70,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -100,9 +100,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -114,7 +114,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -145,9 +145,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -159,7 +159,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -190,9 +190,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -205,7 +205,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -214,7 +214,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -247,9 +247,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -262,7 +262,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -271,7 +271,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -307,7 +307,7 @@
|
||||
<lateral_friction value="1.0"/>
|
||||
<spinning_friction value="1.5"/>
|
||||
</contact>
|
||||
<pose frame=''>0.042 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.042 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -321,7 +321,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -331,7 +331,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -351,7 +351,7 @@
|
||||
<lateral_friction value="1.0"/>
|
||||
<spinning_friction value="1.5"/>
|
||||
</contact>
|
||||
<pose frame=''>-0.042 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.042 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -365,7 +365,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -375,7 +375,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.7 3.14 0 0</pose>
|
||||
<pose>0 0 0.7 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -248,9 +248,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -263,7 +263,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -272,7 +272,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -307,7 +307,7 @@
|
||||
<spinning_friction>.3</spinning_friction>
|
||||
<rolling_friction>0.04</rolling_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -321,7 +321,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -331,7 +331,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -351,7 +351,7 @@
|
||||
<spinning_friction>.3</spinning_friction>
|
||||
<rolling_friction>0.04</rolling_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -365,7 +365,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -375,7 +375,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,11 +2,11 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>1.4 -0.2 2.1 0 0 0</pose>
|
||||
<pose>1.4 -0.2 2.1 0 0 0</pose>
|
||||
<link name='world'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -25,9 +25,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -40,7 +40,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -55,9 +55,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -69,7 +69,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -99,9 +99,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -113,7 +113,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -144,9 +144,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -158,7 +158,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -189,9 +189,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -204,7 +204,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -213,7 +213,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -245,9 +245,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -260,7 +260,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -269,7 +269,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -304,7 +304,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -318,7 +318,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -328,7 +328,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -348,7 +348,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -362,7 +362,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -372,7 +372,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.4 3.14 0 0</pose>
|
||||
<pose>0 0 0.4 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -248,9 +248,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 0</pose>
|
||||
<pose>0.055 0 0.06 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -263,7 +263,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 3.14159</pose>
|
||||
<pose>0 0 -0.06 0 0 3.14159</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -272,7 +272,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 3.14159</pose>
|
||||
<pose>0 0 -0.037 0 0 3.14159</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.27 3.14 0 0</pose>
|
||||
<pose>0 0 0.27 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -42,7 +42,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='base_link_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.2 0.05 0.05 </size>
|
||||
@@ -50,7 +50,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -67,9 +67,9 @@
|
||||
</link>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0 0 -0 0</pose>
|
||||
<pose>-0.055 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -82,7 +82,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='gripper_left_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -91,7 +91,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<collision name='gripper_left_fixed_joint_lump__finger_left_collision_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -101,7 +101,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -110,7 +110,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -141,9 +141,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0 0 -0 3.14159</pose>
|
||||
<pose>0.055 0 0 0 -0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -156,7 +156,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='gripper_right_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -165,7 +165,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<collision name='gripper_right_fixed_joint_lump__finger_right_collision_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -175,7 +175,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -184,7 +184,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -219,7 +219,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -233,7 +233,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -243,7 +243,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -263,7 +263,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -277,7 +277,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -287,7 +287,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
+170
-170
File diff suppressed because it is too large
Load Diff
@@ -11,9 +11,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa_with_wsg50'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -25,7 +25,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -34,7 +34,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -50,9 +50,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -64,7 +64,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -73,7 +73,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -108,9 +108,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -122,7 +122,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -131,7 +131,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -166,9 +166,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -180,7 +180,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -189,7 +189,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -224,9 +224,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -238,7 +238,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,7 +247,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -282,9 +282,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -296,7 +296,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -340,9 +340,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -354,7 +354,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -363,7 +363,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -398,9 +398,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -412,7 +412,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -421,7 +421,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -462,9 +462,9 @@
|
||||
<child>base_link</child>
|
||||
</joint>
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 1.305 0 -0 0</pose>
|
||||
<pose>0 0 1.305 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -476,7 +476,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -511,9 +511,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='left_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -525,7 +525,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -544,9 +544,9 @@
|
||||
<child>left_finger_base</child>
|
||||
</joint>
|
||||
<link name='left_finger_base'>
|
||||
<pose frame=''>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<pose>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>-0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -558,7 +558,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -573,7 +573,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -606,9 +606,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>1.0</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<pose>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>-0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -620,7 +620,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_tip_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -635,7 +635,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -664,9 +664,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='right_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -678,7 +678,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -697,9 +697,9 @@
|
||||
<child>right_finger_base</child>
|
||||
</joint>
|
||||
<link name='right_finger_base'>
|
||||
<pose frame=''>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<pose>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -711,7 +711,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -726,7 +726,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -759,9 +759,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>1.0</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<pose>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -773,7 +773,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -788,7 +788,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -11,9 +11,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa_with_wsg50'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -25,7 +25,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -34,7 +34,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -50,9 +50,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -64,7 +64,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -73,7 +73,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -108,9 +108,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -122,7 +122,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -131,7 +131,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -166,9 +166,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -180,7 +180,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -189,7 +189,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -224,9 +224,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -238,7 +238,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,7 +247,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -282,9 +282,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -296,7 +296,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -340,9 +340,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -354,7 +354,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -363,7 +363,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -398,9 +398,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>1.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -412,7 +412,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -421,7 +421,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -468,9 +468,9 @@
|
||||
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 1.305 0 -0 0</pose>
|
||||
<pose>0 0 1.305 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -482,7 +482,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -496,7 +496,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='base_link_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -531,9 +531,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='left_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -545,7 +545,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -559,7 +559,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_collision'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -577,9 +577,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<pose>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>-0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -591,7 +591,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -606,7 +606,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -639,9 +639,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<pose>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>-0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -653,7 +653,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_tip_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -668,7 +668,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -701,9 +701,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0 0.024 1.35 0 0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -715,7 +715,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -729,7 +729,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_collision'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -752,9 +752,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<pose>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -766,7 +766,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -781,7 +781,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -814,9 +814,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<pose>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -828,7 +828,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -843,7 +843,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -6,9 +6,9 @@
|
||||
<child>lbr_iiwa_link_0</child>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0.01</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -20,7 +20,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -29,7 +29,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -39,9 +39,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -53,7 +53,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -62,7 +62,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -92,9 +92,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -106,7 +106,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -115,7 +115,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -145,9 +145,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -159,7 +159,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -168,7 +168,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -198,9 +198,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -212,7 +212,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -221,7 +221,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -251,9 +251,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -265,7 +265,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -274,7 +274,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -304,9 +304,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -318,7 +318,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -327,7 +327,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -357,9 +357,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -371,7 +371,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -380,7 +380,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
+33
-33
@@ -1,11 +1,11 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa'>
|
||||
<pose frame=''>0 -2.3 0.7 0 0 0</pose>
|
||||
<pose>0 -2.3 0.7 0 0 0</pose>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -17,7 +17,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -26,7 +26,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -42,9 +42,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -56,7 +56,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -65,7 +65,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -101,9 +101,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -115,7 +115,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -124,7 +124,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -160,9 +160,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -174,7 +174,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -183,7 +183,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -219,9 +219,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -233,7 +233,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -242,7 +242,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -278,9 +278,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -292,7 +292,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -301,7 +301,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -337,9 +337,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -351,7 +351,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -360,7 +360,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -396,9 +396,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -410,7 +410,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -419,7 +419,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
+65
-65
@@ -2,9 +2,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -16,7 +16,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -25,7 +25,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -35,9 +35,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -49,7 +49,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,7 +58,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -88,9 +88,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -102,7 +102,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -111,7 +111,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -141,9 +141,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -155,7 +155,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -164,7 +164,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -194,9 +194,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -208,7 +208,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -217,7 +217,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,9 +247,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -261,7 +261,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -270,7 +270,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -300,9 +300,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -314,7 +314,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -323,7 +323,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -353,9 +353,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -367,7 +367,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -376,7 +376,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -408,11 +408,11 @@
|
||||
</model>
|
||||
|
||||
<model name='lbr_iiwa'>
|
||||
<pose frame=''>2 2 0 0 -0 0</pose>
|
||||
<pose>2 2 0 0 -0 0</pose>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -424,7 +424,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -433,7 +433,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -443,9 +443,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -457,7 +457,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -466,7 +466,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -496,9 +496,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -510,7 +510,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -519,7 +519,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -549,9 +549,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -563,7 +563,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -572,7 +572,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -602,9 +602,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -616,7 +616,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -625,7 +625,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -655,9 +655,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -669,7 +669,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -678,7 +678,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -708,9 +708,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -722,7 +722,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -731,7 +731,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -761,9 +761,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -775,7 +775,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -784,7 +784,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,83 @@
|
||||
#vtk DataFile Version 2.0
|
||||
I don't think this matters
|
||||
ASCII
|
||||
DATASET UNSTRUCTURED_GRID
|
||||
POINTS 28 double
|
||||
-0.5000000000000000 -0.2500000000000000 -2.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 -2.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 -2.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 -2.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 2.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 2.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 2.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 2.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 0.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 0.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 0.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 1.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 0.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 -1.0000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 -1.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 -0.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 0.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 1.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 1.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 0.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 -0.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 -1.5000000000000000
|
||||
CELLS 48 192
|
||||
4 22 12 17 13
|
||||
4 20 26 21 11
|
||||
4 23 8 5 24
|
||||
4 11 27 26 19
|
||||
4 27 11 26 20
|
||||
4 17 22 24 25
|
||||
4 7 23 13 6
|
||||
4 22 17 24 13
|
||||
4 9 25 21 15
|
||||
4 24 22 8 14
|
||||
4 24 8 22 23
|
||||
4 25 9 21 22
|
||||
4 23 7 13 24
|
||||
4 15 10 16 26
|
||||
4 14 25 9 15
|
||||
4 25 14 9 22
|
||||
4 24 23 22 13
|
||||
4 15 10 21 9
|
||||
4 15 21 10 26
|
||||
4 24 25 22 14
|
||||
4 2 11 27 20
|
||||
4 7 5 23 6
|
||||
4 11 21 12 26
|
||||
4 20 1 0 16
|
||||
4 18 25 12 17
|
||||
4 18 12 25 26
|
||||
4 5 7 23 24
|
||||
4 26 21 25 15
|
||||
4 20 16 27 1
|
||||
4 21 25 22 12
|
||||
4 20 16 10 26
|
||||
4 20 27 16 26
|
||||
4 20 10 16 0
|
||||
4 11 12 19 26
|
||||
4 14 22 8 9
|
||||
4 8 23 5 4
|
||||
4 24 14 8 5
|
||||
4 11 2 27 3
|
||||
4 2 27 1 20
|
||||
4 12 18 19 26
|
||||
4 27 2 1 3
|
||||
4 24 13 17 7
|
||||
4 20 2 0 1
|
||||
4 5 23 6 4
|
||||
4 20 10 21 26
|
||||
4 12 22 17 25
|
||||
4 3 27 11 19
|
||||
4 21 26 25 12
|
||||
CELL_TYPES 10
|
||||
@@ -0,0 +1,83 @@
|
||||
#vtk DataFile Version 2.0
|
||||
I don't think this matters
|
||||
ASCII
|
||||
DATASET UNSTRUCTURED_GRID
|
||||
POINTS 28 double
|
||||
0.0000000000000000 0.0000000000000000 0.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 0.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 0.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 0.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 4.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 4.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 4.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 4.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 2.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 2.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 2.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 3.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 2.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 1.0000000000000000
|
||||
0.5000000000000000 0.0000000000000000 0.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 1.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 2.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 3.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 3.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 2.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 1.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 0.5000000000000000
|
||||
CELLS 48 192
|
||||
4 22 12 17 13
|
||||
4 20 26 21 11
|
||||
4 23 8 5 24
|
||||
4 11 27 26 19
|
||||
4 27 11 26 20
|
||||
4 17 22 24 25
|
||||
4 7 23 13 6
|
||||
4 22 17 24 13
|
||||
4 9 25 21 15
|
||||
4 24 22 8 14
|
||||
4 24 8 22 23
|
||||
4 25 9 21 22
|
||||
4 23 7 13 24
|
||||
4 15 10 16 26
|
||||
4 14 25 9 15
|
||||
4 25 14 9 22
|
||||
4 24 23 22 13
|
||||
4 15 10 21 9
|
||||
4 15 21 10 26
|
||||
4 24 25 22 14
|
||||
4 2 11 27 20
|
||||
4 7 5 23 6
|
||||
4 11 21 12 26
|
||||
4 20 1 0 16
|
||||
4 18 25 12 17
|
||||
4 18 12 25 26
|
||||
4 5 7 23 24
|
||||
4 26 21 25 15
|
||||
4 20 16 27 1
|
||||
4 21 25 22 12
|
||||
4 20 16 10 26
|
||||
4 20 27 16 26
|
||||
4 20 10 16 0
|
||||
4 11 12 19 26
|
||||
4 14 22 8 9
|
||||
4 8 23 5 4
|
||||
4 24 14 8 5
|
||||
4 11 2 27 3
|
||||
4 2 27 1 20
|
||||
4 12 18 19 26
|
||||
4 27 2 1 3
|
||||
4 24 13 17 7
|
||||
4 20 2 0 1
|
||||
4 5 23 6 4
|
||||
4 20 10 21 26
|
||||
4 12 22 17 25
|
||||
4 3 27 11 19
|
||||
4 21 26 25 12
|
||||
CELL_TYPES 10
|
||||
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_beam">
|
||||
<num_modes value="20"/>
|
||||
<mass value="1"/>
|
||||
<stiffness_scale value="100"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.0"/>
|
||||
<visual filename="beam_mesh_origin.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
File diff suppressed because it is too large
Load Diff
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="cube">
|
||||
<deformable name="cube">
|
||||
<inertial>
|
||||
<mass value="10" />
|
||||
<inertia ixx="0.0" ixy="0" ixz="0" iyy="0" iyz="0" izz="0" />
|
||||
</inertial>
|
||||
<collision_margin value="0.006"/>
|
||||
<repulsion_stiffness value="800.0"/>
|
||||
<friction value= "0.5"/>
|
||||
<neohookean mu= "180" lambda= "600" damping= "0.01" />
|
||||
<visual filename="cube_mesh.vtk"/>
|
||||
</deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_cube">
|
||||
<num_modes value="20"/>
|
||||
<mass value="10"/>
|
||||
<stiffness_scale value="100"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.0"/>
|
||||
<visual filename="cube_mesh.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,15 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_cube">
|
||||
<num_modes value="20"/>
|
||||
<mass value="10"/>
|
||||
<stiffness_scale value="10"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.00001"/>
|
||||
<visual filename="torus_textured.obj"/>
|
||||
<collision filename="torus_mesh.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
File diff suppressed because it is too large
Load Diff
File diff suppressed because it is too large
Load Diff
File diff suppressed because it is too large
Load Diff
+3
-3
@@ -3,7 +3,7 @@
|
||||
<gravity>0 0 -9.8</gravity>
|
||||
<model name='roboschool/models_outdoor/stadium/part0.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d0'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -34,7 +34,7 @@
|
||||
</model>
|
||||
<model name='roboschool/models_outdoor/stadium/part1.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d1'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -73,7 +73,7 @@
|
||||
</model>
|
||||
<model name='part2.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d2'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
|
||||
@@ -3,7 +3,7 @@
|
||||
<gravity>0 0 -9.8</gravity>
|
||||
<model name='part0.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d0'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -42,7 +42,7 @@
|
||||
</model>
|
||||
<model name='part1.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d1'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -81,7 +81,7 @@
|
||||
</model>
|
||||
<model name='part2.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d2'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
|
||||
+11
-11
@@ -3,7 +3,7 @@
|
||||
<light name='sun' type='directional'>
|
||||
<yunfei>99.2</yunfei>
|
||||
<cast_shadows>1</cast_shadows>
|
||||
<pose frame=''>0 0 10 0 -0 0</pose>
|
||||
<pose>0 0 10 0 -0 0</pose>
|
||||
<diffuse>0.8 0.8 0.8 1</diffuse>
|
||||
<specular>0.2 0.2 0.2 1</specular>
|
||||
<attenuation>
|
||||
@@ -87,7 +87,7 @@
|
||||
</spherical_coordinates>
|
||||
<model name='unit_box_0'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0.512455 -1.58317 0.5 0 -0 0</pose>
|
||||
<pose>0.512455 -1.58317 0.5 0 -0 0</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
|
||||
<inertial>
|
||||
@@ -142,7 +142,7 @@
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0_clone'>
|
||||
<pose frame=''>0.105158 -4.55002 1.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 1.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
<inertial>
|
||||
<mass>1</mass>
|
||||
@@ -197,42 +197,42 @@
|
||||
<wall_time>1462824251 956472000</wall_time>
|
||||
<iterations>0</iterations>
|
||||
<model name='ground_plane'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='link'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<velocity>0 0 0 0 -0 0</velocity>
|
||||
<acceleration>0 0 0 0 -0 0</acceleration>
|
||||
<wrench>0 0 0 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0'>
|
||||
<pose frame=''>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='unit_box_0::link'>
|
||||
<pose frame=''>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<velocity>0.004896 3e-06 -0.004891 -6e-06 0.009793 -0</velocity>
|
||||
<acceleration>0.010615 0.006191 -9.78231 -0.012424 0.021225 -1.8e-05</acceleration>
|
||||
<wrench>0.010615 0.006191 -9.78231 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0_clone'>
|
||||
<pose frame=''>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='unit_box_0::link'>
|
||||
<pose frame=''>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<velocity>0 0 0 0 -0 0</velocity>
|
||||
<acceleration>0 0 0 0 -0 0</acceleration>
|
||||
<wrench>0 0 0 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<light name='sun'>
|
||||
<pose frame=''>0 0 10 0 -0 0</pose>
|
||||
<pose>0 0 10 0 -0 0</pose>
|
||||
</light>
|
||||
</state>
|
||||
<gui fullscreen='0'>
|
||||
<camera name='user_camera'>
|
||||
<pose frame=''>8.0562 -8.87312 3.07529 0 0.205021 2.5208</pose>
|
||||
<pose>8.0562 -8.87312 3.07529 0 0.205021 2.5208</pose>
|
||||
<view_controller>orbit</view_controller>
|
||||
<projection_type>perspective</projection_type>
|
||||
</camera>
|
||||
|
||||
Binary file not shown.
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -52,6 +52,8 @@ struct GUIHelperInterface
|
||||
virtual int getShapeIndexFromInstance(int instanceUid) { return -1; }
|
||||
virtual void replaceTexture(int shapeIndex, int textureUid) {}
|
||||
virtual void removeTexture(int textureUid) {}
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]) {}
|
||||
|
||||
|
||||
virtual Common2dCanvasInterface* get2dCanvasInterface() = 0;
|
||||
|
||||
@@ -110,6 +112,7 @@ struct GUIHelperInterface
|
||||
|
||||
virtual int addUserDebugText3D(const char* txt, const double positionXYZ[3], const double orientation[4], const double textColorRGB[3], double size, double lifeTime, int trackingVisualShapeIndex, int optionFlags, int replaceItemUid) { return -1; }
|
||||
virtual int addUserDebugLine(const double debugLineFromXYZ[3], const double debugLineToXYZ[3], const double debugLineColorRGB[3], double lineWidth, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid) { return -1; };
|
||||
virtual int addUserDebugPoints(const double debugPointPositionXYZ[], const double debugPointColorRGB[3], double pointSize, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid, int debugPointNum) { return -1; };
|
||||
virtual int addUserDebugParameter(const char* txt, double rangeMin, double rangeMax, double startValue) { return -1; };
|
||||
virtual int readUserDebugParameter(int itemUniqueId, double* value) { return 0; }
|
||||
|
||||
@@ -217,6 +220,10 @@ struct DummyGUIHelper : public GUIHelperInterface
|
||||
{
|
||||
return -1;
|
||||
}
|
||||
virtual int addUserDebugPoints(const double debugPointPositionXYZ[3], const double debugPointColorRGB[3], double pointSize, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid, int debugPointNum)
|
||||
{
|
||||
return -1;
|
||||
};
|
||||
virtual void removeUserDebugItem(int debugItemUniqueId)
|
||||
{
|
||||
}
|
||||
|
||||
@@ -56,6 +56,8 @@ struct CommonRenderInterface
|
||||
|
||||
virtual void setLightPosition(const float lightPos[3]) = 0;
|
||||
virtual void setLightPosition(const double lightPos[3]) = 0;
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]) = 0;
|
||||
|
||||
virtual void setShadowMapResolution(int shadowMapResolution) = 0;
|
||||
virtual void setShadowMapIntensity(double shadowMapIntensity) = 0;
|
||||
|
||||
@@ -78,6 +80,7 @@ struct CommonRenderInterface
|
||||
virtual void drawLine(const double from[4], const double to[4], const double color[4], double lineWidth) = 0;
|
||||
virtual void drawPoint(const float* position, const float color[4], float pointDrawSize) = 0;
|
||||
virtual void drawPoint(const double* position, const double color[4], double pointDrawSize) = 0;
|
||||
virtual void drawPoints(const float* positions, const float* colors, int numPoints, int pointStrideInBytes, float pointDrawSize) = 0;
|
||||
virtual void drawTexturedTriangleMesh(float worldPosition[3], float worldOrientation[4], const float* vertices, int numvertices, const unsigned int* indices, int numIndices, float color[4], int textureIndex = -1, int vertexLayout = 0) = 0;
|
||||
|
||||
virtual int registerShape(const float* vertices, int numvertices, const int* indices, int numIndices, int primitiveType = B3_GL_TRIANGLES, int textureIndex = -1) = 0;
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2015 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2015 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -55,7 +55,7 @@ public:
|
||||
m_dynamicsWorld->stepSimulation(deltaTime, 4, internalTimeStep);
|
||||
}
|
||||
|
||||
void addCloth(btVector3 origin);
|
||||
void addCloth(const btVector3& origin);
|
||||
|
||||
virtual void renderScene()
|
||||
{
|
||||
@@ -126,7 +126,7 @@ void DeformableSelfCollision::initPhysics()
|
||||
getDeformableDynamicsWorld()->setLineSearch(false);
|
||||
m_guiHelper->autogenerateGraphicsObjects(m_dynamicsWorld);
|
||||
}
|
||||
void DeformableSelfCollision::addCloth(btVector3 origin)
|
||||
void DeformableSelfCollision::addCloth(const btVector3& origin)
|
||||
// create a piece of cloth
|
||||
{
|
||||
const btScalar s = 0.6;
|
||||
|
||||
@@ -0,0 +1,405 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2019 Google Inc. http://bulletphysics.org
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
*/
|
||||
|
||||
#include "LoadDeformed.h"
|
||||
///btBulletDynamicsCommon.h is the main Bullet include file, contains most common include files.
|
||||
#include "btBulletDynamicsCommon.h"
|
||||
#include "BulletSoftBody/btDeformableMultiBodyDynamicsWorld.h"
|
||||
#include "BulletSoftBody/btSoftBody.h"
|
||||
#include "BulletSoftBody/btSoftBodyHelpers.h"
|
||||
#include "BulletSoftBody/btDeformableBodySolver.h"
|
||||
#include "BulletSoftBody/btSoftBodyRigidBodyCollisionConfiguration.h"
|
||||
#include "BulletDynamics/Featherstone/btMultiBodyConstraintSolver.h"
|
||||
#include "../CommonInterfaces/CommonParameterInterface.h"
|
||||
#include <stdio.h> //printf debugging
|
||||
|
||||
#include "../CommonInterfaces/CommonDeformableBodyBase.h"
|
||||
#include "../Utils/b3ResourcePath.h"
|
||||
#include "../Utils/b3BulletDefaultFileIO.h"
|
||||
#include <iostream>
|
||||
#include <iomanip>
|
||||
#include <sstream>
|
||||
#include <string.h>
|
||||
|
||||
struct CustomSoftBodyHelper : public btSoftBodyHelpers
|
||||
{
|
||||
static std::string loadDeformableState(btAlignedObjectArray<btVector3>& qs, btAlignedObjectArray<btVector3>& vs, const char* filename, CommonFileIOInterface* fileIO);
|
||||
|
||||
};
|
||||
|
||||
static inline bool isSpace(const char c)
|
||||
{
|
||||
return (c == ' ') || (c == '\t');
|
||||
}
|
||||
static inline bool isNewLine(const char c)
|
||||
{
|
||||
return (c == '\r') || (c == '\n') || (c == '\0');
|
||||
}
|
||||
static inline float parseFloat(const char*& token)
|
||||
{
|
||||
token += strspn(token, " \t");
|
||||
float f = (float)atof(token);
|
||||
token += strcspn(token, " \t\r");
|
||||
return f;
|
||||
}
|
||||
static inline void parseFloat3(
|
||||
float& x, float& y, float& z,
|
||||
const char*& token)
|
||||
{
|
||||
x = parseFloat(token);
|
||||
y = parseFloat(token);
|
||||
z = parseFloat(token);
|
||||
}
|
||||
|
||||
|
||||
std::string CustomSoftBodyHelper::loadDeformableState(btAlignedObjectArray<btVector3>& qs, btAlignedObjectArray<btVector3>& vs, const char* filename, CommonFileIOInterface* fileIO)
|
||||
{
|
||||
{
|
||||
qs.clear();
|
||||
vs.clear();
|
||||
std::string tmp = filename;
|
||||
std::stringstream err;
|
||||
#ifdef USE_STREAM
|
||||
std::ifstream ifs(filename);
|
||||
if (!ifs)
|
||||
{
|
||||
err << "Cannot open file [" << filename << "]" << std::endl;
|
||||
return err.str();
|
||||
}
|
||||
#else
|
||||
int fileHandle = fileIO->fileOpen(filename, "r");
|
||||
if (fileHandle < 0)
|
||||
{
|
||||
err << "Cannot open file [" << filename << "]" << std::endl;
|
||||
return err.str();
|
||||
}
|
||||
#endif
|
||||
|
||||
std::string name;
|
||||
|
||||
int maxchars = 8192; // Alloc enough size.
|
||||
std::vector<char> buf(maxchars); // Alloc enough size.
|
||||
std::string linebuf;
|
||||
linebuf.reserve(maxchars);
|
||||
|
||||
#ifdef USE_STREAM
|
||||
while (ifs.peek() != -1)
|
||||
#else
|
||||
char* line = 0;
|
||||
do
|
||||
#endif
|
||||
{
|
||||
linebuf.resize(0);
|
||||
#ifdef USE_STREAM
|
||||
safeGetline(ifs, linebuf);
|
||||
#else
|
||||
char tmpBuf[1024];
|
||||
line = fileIO->readLine(fileHandle, tmpBuf, 1024);
|
||||
if (line)
|
||||
{
|
||||
linebuf = line;
|
||||
}
|
||||
#endif
|
||||
// Trim newline '\r\n' or '\r'
|
||||
if (linebuf.size() > 0)
|
||||
{
|
||||
if (linebuf[linebuf.size() - 1] == '\n') linebuf.erase(linebuf.size() - 1);
|
||||
}
|
||||
if (linebuf.size() > 0)
|
||||
{
|
||||
if (linebuf[linebuf.size() - 1] == '\n') linebuf.erase(linebuf.size() - 1);
|
||||
}
|
||||
|
||||
// Skip if empty line.
|
||||
if (linebuf.empty())
|
||||
{
|
||||
continue;
|
||||
}
|
||||
|
||||
// Skip leading space.
|
||||
const char* token = linebuf.c_str();
|
||||
token += strspn(token, " \t");
|
||||
|
||||
btAssert(token);
|
||||
if (token[0] == '\0') continue; // empty line
|
||||
|
||||
if (token[0] == '#') continue; // comment line
|
||||
|
||||
// q
|
||||
if (token[0] == 'q' && isSpace((token[1])))
|
||||
{
|
||||
token += 2;
|
||||
float x, y, z;
|
||||
parseFloat3(x, y, z, token);
|
||||
qs.push_back(btVector3(x, y, z));
|
||||
continue;
|
||||
}
|
||||
|
||||
// v
|
||||
if (token[0] == 'v' && isSpace((token[1])))
|
||||
{
|
||||
token += 3;
|
||||
float x, y, z;
|
||||
parseFloat3(x, y, z, token);
|
||||
vs.push_back(btVector3(x, y, z));
|
||||
continue;
|
||||
}
|
||||
|
||||
// Ignore unknown command.
|
||||
}
|
||||
#ifndef USE_STREAM
|
||||
while (line)
|
||||
;
|
||||
#endif
|
||||
|
||||
if (fileHandle >= 0)
|
||||
{
|
||||
fileIO->fileClose(fileHandle);
|
||||
}
|
||||
return err.str();
|
||||
}
|
||||
}
|
||||
|
||||
|
||||
class LoadDeformed : public CommonDeformableBodyBase
|
||||
{
|
||||
int steps;
|
||||
btSoftBody* psb;
|
||||
char filename;
|
||||
int reset_frame;
|
||||
float sim_time;
|
||||
|
||||
public:
|
||||
LoadDeformed(struct GUIHelperInterface* helper)
|
||||
: CommonDeformableBodyBase(helper)
|
||||
{
|
||||
steps = 0;
|
||||
psb = nullptr;
|
||||
reset_frame = 0;
|
||||
sim_time = 0;
|
||||
}
|
||||
virtual ~LoadDeformed()
|
||||
{
|
||||
}
|
||||
void initPhysics();
|
||||
|
||||
void exitPhysics();
|
||||
|
||||
void resetCamera()
|
||||
{
|
||||
float dist = 2;
|
||||
float pitch = -45;
|
||||
float yaw = 100;
|
||||
float targetPos[3] = {0, 0, 0};
|
||||
m_guiHelper->resetCamera(dist, yaw, pitch, targetPos[0], targetPos[1], targetPos[2]);
|
||||
}
|
||||
|
||||
void stepSimulation(float deltaTime)
|
||||
{
|
||||
steps++;
|
||||
sim_time += deltaTime;
|
||||
//// int seconds = 1/deltaTime;
|
||||
if (0)
|
||||
{
|
||||
// if (reset_frame==0 && steps<100){
|
||||
//// printf("steps %d, seconds %d, steps/seconds %d\n", steps,seconds,steps/seconds);
|
||||
char filename[100];
|
||||
sprintf(filename, "%s_%d_%d.txt", "states", reset_frame, steps);
|
||||
btSoftBodyHelpers::writeState(filename, psb);
|
||||
}
|
||||
if (sim_time + reset_frame * 0.05 >= 5) exit(0);
|
||||
float internalTimeStep = 1. / 240.f;
|
||||
// float internalTimeStep = 0.1f;
|
||||
m_dynamicsWorld->stepSimulation(deltaTime, deltaTime / internalTimeStep, internalTimeStep);
|
||||
}
|
||||
|
||||
void addCloth(const btVector3& origin);
|
||||
|
||||
virtual void renderScene()
|
||||
{
|
||||
CommonDeformableBodyBase::renderScene();
|
||||
btDeformableMultiBodyDynamicsWorld* deformableWorld = getDeformableDynamicsWorld();
|
||||
|
||||
for (int i = 0; i < deformableWorld->getSoftBodyArray().size(); i++)
|
||||
{
|
||||
btSoftBody* psb = (btSoftBody*)deformableWorld->getSoftBodyArray()[i];
|
||||
{
|
||||
btSoftBodyHelpers::DrawFrame(psb, deformableWorld->getDebugDrawer());
|
||||
btSoftBodyHelpers::Draw(psb, deformableWorld->getDebugDrawer(), deformableWorld->getDrawFlags());
|
||||
}
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
void LoadDeformed::initPhysics()
|
||||
{
|
||||
m_guiHelper->setUpAxis(1);
|
||||
|
||||
///collision configuration contains default setup for memory, collision setup
|
||||
m_collisionConfiguration = new btSoftBodyRigidBodyCollisionConfiguration();
|
||||
|
||||
///use the default collision dispatcher. For parallel processing you can use a diffent dispatcher (see Extras/BulletMultiThreaded)
|
||||
m_dispatcher = new btCollisionDispatcher(m_collisionConfiguration);
|
||||
|
||||
m_broadphase = new btDbvtBroadphase();
|
||||
btDeformableBodySolver* deformableBodySolver = new btDeformableBodySolver();
|
||||
|
||||
btDeformableMultiBodyConstraintSolver* sol = new btDeformableMultiBodyConstraintSolver();
|
||||
sol->setDeformableSolver(deformableBodySolver);
|
||||
m_solver = sol;
|
||||
|
||||
m_dynamicsWorld = new btDeformableMultiBodyDynamicsWorld(m_dispatcher, m_broadphase, sol, m_collisionConfiguration, deformableBodySolver);
|
||||
btVector3 gravity = btVector3(0, -9.8, 0);
|
||||
m_dynamicsWorld->setGravity(gravity);
|
||||
getDeformableDynamicsWorld()->getWorldInfo().m_gravity = gravity;
|
||||
getDeformableDynamicsWorld()->getWorldInfo().m_sparsesdf.setDefaultVoxelsz(0.25);
|
||||
|
||||
m_guiHelper->createPhysicsDebugDrawer(m_dynamicsWorld);
|
||||
|
||||
{
|
||||
///create a ground
|
||||
btCollisionShape* groundShape = new btBoxShape(btVector3(btScalar(150.), btScalar(2.5), btScalar(150.)));
|
||||
groundShape->setMargin(0.02);
|
||||
m_collisionShapes.push_back(groundShape);
|
||||
|
||||
btTransform groundTransform;
|
||||
groundTransform.setIdentity();
|
||||
groundTransform.setOrigin(btVector3(0, -3.5, 0));
|
||||
groundTransform.setRotation(btQuaternion(btVector3(1, 0, 0), SIMD_PI * 0));
|
||||
btScalar mass(0.);
|
||||
|
||||
//rigidbody is dynamic if and only if mass is non zero, otherwise static
|
||||
bool isDynamic = (mass != 0.f);
|
||||
|
||||
btVector3 localInertia(0, 0, 0);
|
||||
if (isDynamic)
|
||||
groundShape->calculateLocalInertia(mass, localInertia);
|
||||
|
||||
//using motionstate is recommended, it provides interpolation capabilities, and only synchronizes 'active' objects
|
||||
btDefaultMotionState* myMotionState = new btDefaultMotionState(groundTransform);
|
||||
btRigidBody::btRigidBodyConstructionInfo rbInfo(mass, myMotionState, groundShape, localInertia);
|
||||
btRigidBody* body = new btRigidBody(rbInfo);
|
||||
body->setFriction(4);
|
||||
|
||||
//add the ground to the dynamics world
|
||||
m_dynamicsWorld->addRigidBody(body);
|
||||
}
|
||||
addCloth(btVector3(0, 1, 0));
|
||||
getDeformableDynamicsWorld()->setImplicit(false);
|
||||
getDeformableDynamicsWorld()->setLineSearch(false);
|
||||
m_guiHelper->autogenerateGraphicsObjects(m_dynamicsWorld);
|
||||
}
|
||||
|
||||
void LoadDeformed::addCloth(const btVector3& origin)
|
||||
// create a piece of cloth
|
||||
{
|
||||
const btScalar s = 0.6;
|
||||
const btScalar h = 0;
|
||||
|
||||
psb = btSoftBodyHelpers::CreatePatch(getDeformableDynamicsWorld()->getWorldInfo(), btVector3(-s, h, -2 * s),
|
||||
btVector3(+s, h, -2 * s),
|
||||
btVector3(-s, h, +2 * s),
|
||||
btVector3(+s, h, +2 * s),
|
||||
15, 30,
|
||||
0, true, 0.0);
|
||||
|
||||
psb->getCollisionShape()->setMargin(0.02);
|
||||
psb->generateBendingConstraints(2);
|
||||
psb->setTotalMass(.5);
|
||||
psb->m_cfg.kKHR = 1; // collision hardness with kinematic objects
|
||||
psb->m_cfg.kCHR = 1; // collision hardness with rigid body
|
||||
psb->m_cfg.kDF = 0.1;
|
||||
psb->rotate(btQuaternion(0, SIMD_PI / 2, 0));
|
||||
btTransform clothTransform;
|
||||
clothTransform.setIdentity();
|
||||
clothTransform.setOrigin(btVector3(0, 0.2, 0) + origin);
|
||||
psb->transform(clothTransform);
|
||||
|
||||
b3BulletDefaultFileIO fileio;
|
||||
char absolute_path[1024];
|
||||
char filename[100];
|
||||
sprintf(filename, "/Users/fuchuyuan/Documents/mybullet/build_cmake/examples/ExampleBrowser/states_0_%d.txt", reset_frame);
|
||||
fileio.findResourcePath(filename, absolute_path, 1024);
|
||||
btAlignedObjectArray<btVector3> qs;
|
||||
btAlignedObjectArray<btVector3> vs;
|
||||
CustomSoftBodyHelper::loadDeformableState(qs, vs, absolute_path, &fileio);
|
||||
if (reset_frame > 0)
|
||||
psb->updateState(qs, vs);
|
||||
psb->m_cfg.collisions = btSoftBody::fCollision::SDF_RD;
|
||||
psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_MDF;
|
||||
psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_RDF;
|
||||
// psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_RDN;
|
||||
psb->setCollisionFlags(0);
|
||||
psb->setCacheBarycenter(true);
|
||||
getDeformableDynamicsWorld()->addSoftBody(psb);
|
||||
psb->setSelfCollision(false);
|
||||
|
||||
btDeformableMassSpringForce* mass_spring = new btDeformableMassSpringForce(2, 0.2, true);
|
||||
psb->setSpringStiffness(4);
|
||||
getDeformableDynamicsWorld()->addForce(psb, mass_spring);
|
||||
m_forces.push_back(mass_spring);
|
||||
btVector3 gravity = btVector3(0, -9.8, 0);
|
||||
btDeformableGravityForce* gravity_force = new btDeformableGravityForce(gravity);
|
||||
getDeformableDynamicsWorld()->addForce(psb, gravity_force);
|
||||
// getDeformableDynamicsWorld()->setUseProjection(true);
|
||||
m_forces.push_back(gravity_force);
|
||||
}
|
||||
|
||||
void LoadDeformed::exitPhysics()
|
||||
{
|
||||
//cleanup in the reverse order of creation/initialization
|
||||
removePickingConstraint();
|
||||
//remove the rigidbodies from the dynamics world and delete them
|
||||
int i;
|
||||
for (i = m_dynamicsWorld->getNumCollisionObjects() - 1; i >= 0; i--)
|
||||
{
|
||||
btCollisionObject* obj = m_dynamicsWorld->getCollisionObjectArray()[i];
|
||||
btRigidBody* body = btRigidBody::upcast(obj);
|
||||
if (body && body->getMotionState())
|
||||
{
|
||||
delete body->getMotionState();
|
||||
}
|
||||
m_dynamicsWorld->removeCollisionObject(obj);
|
||||
delete obj;
|
||||
}
|
||||
// delete forces
|
||||
for (int j = 0; j < m_forces.size(); j++)
|
||||
{
|
||||
btDeformableLagrangianForce* force = m_forces[j];
|
||||
delete force;
|
||||
}
|
||||
m_forces.clear();
|
||||
|
||||
//delete collision shapes
|
||||
for (int j = 0; j < m_collisionShapes.size(); j++)
|
||||
{
|
||||
btCollisionShape* shape = m_collisionShapes[j];
|
||||
delete shape;
|
||||
}
|
||||
m_collisionShapes.clear();
|
||||
|
||||
delete m_dynamicsWorld;
|
||||
|
||||
delete m_solver;
|
||||
|
||||
delete m_broadphase;
|
||||
|
||||
delete m_dispatcher;
|
||||
|
||||
delete m_collisionConfiguration;
|
||||
}
|
||||
|
||||
class CommonExampleInterface* LoadDeformedCreateFunc(struct CommonExampleOptions& options)
|
||||
{
|
||||
return new LoadDeformed(options.m_guiHelper);
|
||||
}
|
||||
@@ -0,0 +1,19 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2019 Google Inc. http://bulletphysics.org
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
*/
|
||||
|
||||
#ifndef _LOAD_DEFORMED_H
|
||||
#define _LOAD_DEFORMED_H
|
||||
|
||||
class CommonExampleInterface* LoadDeformedCreateFunc(struct CommonExampleOptions& options);
|
||||
|
||||
#endif //_LOAD_DEFORMED_H
|
||||
@@ -284,7 +284,7 @@ SET(BulletExampleBrowser_SRCS
|
||||
../Benchmarks/BenchmarkDemo.cpp
|
||||
../Benchmarks/BenchmarkDemo.h
|
||||
../Benchmarks/landscapeData.h
|
||||
../Benchmarks/TaruData
|
||||
../Benchmarks/TaruData.h
|
||||
../Raycast/RaytestDemo.cpp
|
||||
../Importers/ImportBsp/BspConverter.h
|
||||
../Importers/ImportBullet/SerializeSetup.cpp
|
||||
@@ -379,6 +379,8 @@ SET(BulletExampleBrowser_SRCS
|
||||
../DeformableDemo/Collide.cpp
|
||||
../DeformableDemo/Collide.h
|
||||
../DeformableDemo/LargeDeformation.cpp
|
||||
../DeformableDemo/LoadDeformed.h
|
||||
../DeformableDemo/LoadDeformed.cpp
|
||||
../DeformableDemo/LargeDeformation.h
|
||||
../DeformableDemo/DeformableClothAnchor.cpp
|
||||
../DeformableDemo/DeformableClothAnchor.h
|
||||
@@ -388,6 +390,24 @@ SET(BulletExampleBrowser_SRCS
|
||||
../MultiBody/MultiDofDemo.h
|
||||
../RigidBody/RigidBodySoftContact.cpp
|
||||
../RigidBody/KinematicRigidBodyExample.cpp
|
||||
../ReducedDeformableDemo/ConservationTest.cpp
|
||||
../ReducedDeformableDemo/ConservationTest.h
|
||||
../ReducedDeformableDemo/Springboard.cpp
|
||||
../ReducedDeformableDemo/Springboard.h
|
||||
../ReducedDeformableDemo/ModeVisualizer.cpp
|
||||
../ReducedDeformableDemo/ModeVisualizer.h
|
||||
../ReducedDeformableDemo/FreeFall.cpp
|
||||
../ReducedDeformableDemo/FreeFall.h
|
||||
../ReducedDeformableDemo/FrictionSlope.cpp
|
||||
../ReducedDeformableDemo/FrictionSlope.h
|
||||
../ReducedDeformableDemo/ReducedCollide.cpp
|
||||
../ReducedDeformableDemo/ReducedCollide.h
|
||||
../ReducedDeformableDemo/ReducedGrasp.cpp
|
||||
../ReducedDeformableDemo/ReducedGrasp.h
|
||||
../ReducedDeformableDemo/ReducedBenchmark.cpp
|
||||
../ReducedDeformableDemo/ReducedBenchmark.h
|
||||
../ReducedDeformableDemo/ReducedMotorGrasp.cpp
|
||||
../ReducedDeformableDemo/ReducedMotorGrasp.h
|
||||
../Constraints/TestHingeTorque.cpp
|
||||
../Constraints/TestHingeTorque.h
|
||||
../Constraints/ConstraintDemo.cpp
|
||||
|
||||
@@ -55,6 +55,7 @@
|
||||
#include "../DeformableDemo/DeformableMultibody.h"
|
||||
#include "../DeformableDemo/VolumetricDeformable.h"
|
||||
#include "../DeformableDemo/LargeDeformation.h"
|
||||
#include "../DeformableDemo/LoadDeformed.h"
|
||||
#include "../DeformableDemo/Collide.h"
|
||||
#include "../DeformableDemo/GraspDeformable.h"
|
||||
#include "../DeformableDemo/DeformableContact.h"
|
||||
@@ -72,6 +73,15 @@
|
||||
#include "../RoboticsLearning/R2D2GraspExample.h"
|
||||
#include "../RoboticsLearning/KukaGraspExample.h"
|
||||
#include "../RoboticsLearning/GripperGraspExample.h"
|
||||
#include "../ReducedDeformableDemo/ConservationTest.h"
|
||||
#include "../ReducedDeformableDemo/ModeVisualizer.h"
|
||||
#include "../ReducedDeformableDemo/Springboard.h"
|
||||
#include "../ReducedDeformableDemo/FreeFall.h"
|
||||
#include "../ReducedDeformableDemo/FrictionSlope.h"
|
||||
#include "../ReducedDeformableDemo/ReducedCollide.h"
|
||||
#include "../ReducedDeformableDemo/ReducedGrasp.h"
|
||||
#include "../ReducedDeformableDemo/ReducedMotorGrasp.h"
|
||||
#include "../ReducedDeformableDemo/ReducedBenchmark.h"
|
||||
#include "../InverseKinematics/InverseKinematicsExample.h"
|
||||
|
||||
#ifdef B3_ENABLE_TINY_AUDIO
|
||||
@@ -209,11 +219,24 @@ static ExampleEntry gDefaultExamples[] =
|
||||
ExampleEntry(1, "Grasp Deformable with Motor", "Grasping test", GraspDeformableCreateFunc),
|
||||
ExampleEntry(1, "Volumetric Deformable Objects", "Volumetric Deformable test", VolumetricDeformableCreateFunc),
|
||||
ExampleEntry(1, "Extreme Deformation", "Recovery from extreme deformation", LargeDeformationCreateFunc),
|
||||
ExampleEntry(1, "Load Deformed", "Reconstruct a deformed object", LoadDeformedCreateFunc),
|
||||
ExampleEntry(1, "Colliding Test", "Volumetric deformable collide with rigid box", CollideCreateFunc),
|
||||
ExampleEntry(1, "Rigid Cloth Anchor", "Deformable Rigid body Anchor test", DeformableClothAnchorCreateFunc),
|
||||
ExampleEntry(1, "Multibody Cloth Anchor", "Deformable Multibody Anchor test", MultibodyClothAnchorCreateFunc),
|
||||
ExampleEntry(1, "Deformable-MultiBody Contact", "MultiBody and Deformable contact", DeformableMultibodyCreateFunc),
|
||||
// ExampleEntry(1, "MultiBody Baseline", "MultiBody Baseline", MultiBodyBaselineCreateFunc),
|
||||
|
||||
ExampleEntry(0, "Reduced Deformabe Body"),
|
||||
ExampleEntry(1, "Mode Visualizer", "Visualizer the modes for reduced deformable objects", ReducedModeVisualizerCreateFunc),
|
||||
ExampleEntry(1, "Reduced Conservation Test", "Momentum conservation test for the reduced deformable objects", ReducedConservationTestCreateFunc),
|
||||
ExampleEntry(1, "Reduced Springboard", "Moving rigid object colliding with a fixed reduced deformable objects", ReducedSpringboardCreateFunc),
|
||||
ExampleEntry(1, "Reduced Free Fall", "Free fall ground contact test for the reduced deformable model", ReducedFreeFallCreateFunc),
|
||||
ExampleEntry(1, "Reduced Collision Test", "Collision between a reduced block and the a rigid block", ReducedCollideCreateFunc),
|
||||
ExampleEntry(1, "Reduced Grasp", "Grasp a reduced deformable block", ReducedGraspCreateFunc),
|
||||
ExampleEntry(1, "Reduced Motor Grasp", "Grasp a reduced deformable block with motor", ReducedMotorGraspCreateFunc),
|
||||
ExampleEntry(1, "Reduced Friction Slope", "Grasp a reduced deformable block", FrictionSlopeCreateFunc),
|
||||
ExampleEntry(1, "Reduced Benchmark", "Reduced deformable performance benchmark example", ReducedBenchmarkCreateFunc),
|
||||
// ExampleEntry(1, "Simple Reduced Deformable Test", "Simple dynamics test for the reduced deformable objects", ReducedBasicTestCreateFunc),
|
||||
|
||||
#ifdef INCLUDE_CLOTH_DEMOS
|
||||
ExampleEntry(0, "Soft Body"),
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,7 +1,11 @@
|
||||
#include "GwenParameterInterface.h"
|
||||
#include "gwenInternalData.h"
|
||||
#include <cstring>
|
||||
|
||||
#ifdef _WIN32
|
||||
#define safe_printf _snprintf
|
||||
#else
|
||||
#define safe_printf snprintf
|
||||
#endif
|
||||
struct MyButtonEventHandler : public Gwen::Event::Handler
|
||||
{
|
||||
Gwen::Controls::Button* m_buttonControl;
|
||||
@@ -85,7 +89,7 @@ struct MySliderEventHandler : public Gwen::Event::Handler
|
||||
if (m_showValue)
|
||||
{
|
||||
char txt[1024];
|
||||
snprintf(txt, sizeof(txt), "%s : %.3f", m_variableName, val);
|
||||
safe_printf(txt, sizeof(txt), "%s : %.3f", m_variableName, val);
|
||||
m_label->SetText(txt);
|
||||
}
|
||||
}
|
||||
@@ -231,7 +235,7 @@ void GwenParameterInterface::registerSliderFloatParameter(SliderParams& params)
|
||||
}
|
||||
pSlider->SetValue(*params.m_paramValuePointer); //dimensions[i] );
|
||||
char labelName[1024];
|
||||
snprintf(labelName, sizeof(labelName), "%s", params.m_name); //axisNames[0]);
|
||||
safe_printf(labelName, sizeof(labelName), "%s", params.m_name); //axisNames[0]);
|
||||
MySliderEventHandler<btScalar>* handler = new MySliderEventHandler<btScalar>(labelName, label, pSlider, params.m_paramValuePointer, params.m_callback, params.m_userPointer);
|
||||
handler->m_showValue = params.m_showValues;
|
||||
m_paramInternalData->m_sliderEventHandlers.push_back(handler);
|
||||
|
||||
@@ -885,6 +885,20 @@ bool OpenGLExampleBrowser::init(int argc, char* argv[])
|
||||
sUseOpenGL2 = args.CheckCmdLineFlag("opengl2");
|
||||
args.GetCmdLineArgument("render_device", gRenderDevice);
|
||||
args.GetCmdLineArgument("window_backend", gWindowBackend);
|
||||
|
||||
int max_num_object_capacity = 128 * 1024;
|
||||
int max_shape_capacity_in_bytes = 128 * 1024 * 1024;
|
||||
if (args.CheckCmdLineFlag("max_num_object_capacity"))
|
||||
{
|
||||
args.GetCmdLineArgument("max_num_object_capacity", max_num_object_capacity);
|
||||
}
|
||||
|
||||
if (args.CheckCmdLineFlag("max_shape_capacity_in_bytes"))
|
||||
{
|
||||
args.GetCmdLineArgument("max_shape_capacity_in_bytes", max_shape_capacity_in_bytes);
|
||||
}
|
||||
|
||||
|
||||
#else
|
||||
sUseOpenGL2 = true;
|
||||
#endif
|
||||
@@ -914,7 +928,7 @@ bool OpenGLExampleBrowser::init(int argc, char* argv[])
|
||||
{
|
||||
char title[1024];
|
||||
sprintf(title, "%s using OpenGL3+ %s %s", appTitle, glContext, optMode);
|
||||
simpleApp = new SimpleOpenGL3App(title, width, height, gAllowRetina, gWindowBackend, gRenderDevice);
|
||||
simpleApp = new SimpleOpenGL3App(title, width, height, gAllowRetina, gWindowBackend, gRenderDevice, max_num_object_capacity, max_shape_capacity_in_bytes);
|
||||
s_app = simpleApp;
|
||||
}
|
||||
#endif
|
||||
|
||||
@@ -236,13 +236,19 @@ OpenGLGuiHelper::OpenGLGuiHelper(CommonGraphicsApp* glApp, bool useOpenGL2)
|
||||
m_data->m_debugDraw = 0;
|
||||
}
|
||||
|
||||
OpenGLGuiHelper::~OpenGLGuiHelper()
|
||||
|
||||
OpenGLGuiHelper::~OpenGLGuiHelper()
|
||||
{
|
||||
delete m_data->m_debugDraw;
|
||||
|
||||
delete m_data;
|
||||
}
|
||||
|
||||
void OpenGLGuiHelper::setBackgroundColor(const double rgbBackground[3])
|
||||
{
|
||||
this->getRenderInterface()->setBackgroundColor(rgbBackground);
|
||||
}
|
||||
|
||||
struct CommonRenderInterface* OpenGLGuiHelper::getRenderInterface()
|
||||
{
|
||||
return m_data->m_glApp->m_renderer;
|
||||
|
||||
@@ -36,7 +36,7 @@ struct OpenGLGuiHelper : public GUIHelperInterface
|
||||
virtual int getShapeIndexFromInstance(int instanceUid);
|
||||
virtual void replaceTexture(int shapeIndex, int textureUid);
|
||||
virtual void updateShape(int shapeIndex, float* vertices, int numVertices);
|
||||
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]);
|
||||
virtual void createCollisionShapeGraphicsObject(btCollisionShape* collisionShape);
|
||||
|
||||
virtual void syncPhysicsToGraphics(const btDiscreteDynamicsWorld* rbWorld);
|
||||
|
||||
@@ -182,6 +182,7 @@ project "App_BulletExampleBrowser"
|
||||
"../VoronoiFracture/*",
|
||||
"../SoftDemo/*",
|
||||
"../DeformableDemo/*",
|
||||
"../ReducedDeformableDemo/*",
|
||||
"../RollingFrictionDemo/*",
|
||||
"../rbdl/*",
|
||||
"../FractureDemo/*",
|
||||
|
||||
@@ -101,7 +101,7 @@ void CompoundBoxesExample::initPhysics()
|
||||
#else
|
||||
// recompute the shift to make sure the compound shape is re-aligned
|
||||
for (int i = 0; i < compoundShape->getNumChildShapes(); i++)
|
||||
compound2->addChildShape(compoundShape->getChildTransform(i) * principal.inverse(),
|
||||
compound2->addChildShape(principal.inverse() * compoundShape->getChildTransform(i),
|
||||
compoundShape->getChildShape(i));
|
||||
#endif
|
||||
delete compoundShape;
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2011 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2011 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2007 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2007 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -2273,7 +2273,7 @@ int BulletMJCFImporter::getBodyUniqueId() const
|
||||
return m_data->m_activeBodyUniqueId;
|
||||
}
|
||||
|
||||
static btCollisionShape* MjcfCreateConvexHullFromShapes(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, const btVector3& geomScale, btScalar collisionMargin)
|
||||
static btCollisionShape* MjcfCreateConvexHullFromShapes(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, const btVector3& geomScale, btScalar collisionMargin)
|
||||
{
|
||||
btCompoundShape* compound = new btCompoundShape();
|
||||
compound->setMargin(collisionMargin);
|
||||
@@ -2285,7 +2285,7 @@ static btCollisionShape* MjcfCreateConvexHullFromShapes(const tinyobj::attrib_t&
|
||||
{
|
||||
btConvexHullShape* convexHull = new btConvexHullShape();
|
||||
convexHull->setMargin(collisionMargin);
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
@@ -2399,9 +2399,9 @@ class btCompoundShape* BulletMJCFImporter::convertLinkCollisionShapes(int linkIn
|
||||
}
|
||||
else
|
||||
{
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, col->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, col->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
//create a convex hull for each shape, and store it in a btCompoundShape
|
||||
|
||||
childShape = MjcfCreateConvexHullFromShapes(attribute, shapes, col->m_geometry.m_meshScale, m_data->m_globalDefaults.m_defaultCollisionMargin);
|
||||
|
||||
@@ -64,8 +64,8 @@ bool b3ImportMeshUtility::loadAndRegisterMeshFromFileInternal(const std::string&
|
||||
b3FileUtils::extractPath(relativeFileName, pathPrefix, 1024);
|
||||
btVector3 shift(0, 0, 0);
|
||||
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
{
|
||||
B3_PROFILE("tinyobj::LoadObj");
|
||||
std::string err = LoadFromCachedOrFromObj(attribute, shapes, relativeFileName, pathPrefix, fileIO);
|
||||
@@ -79,7 +79,7 @@ bool b3ImportMeshUtility::loadAndRegisterMeshFromFileInternal(const std::string&
|
||||
//try to load some texture
|
||||
for (int i = 0; meshData.m_textureImage1 == 0 && i < shapes.size(); i++)
|
||||
{
|
||||
const tinyobj::shape_t& shape = shapes[i];
|
||||
const bt_tinyobj::shape_t& shape = shapes[i];
|
||||
meshData.m_rgbaColor[0] = shape.material.diffuse[0];
|
||||
meshData.m_rgbaColor[1] = shape.material.diffuse[1];
|
||||
meshData.m_rgbaColor[2] = shape.material.diffuse[2];
|
||||
|
||||
@@ -11,8 +11,8 @@
|
||||
struct CachedObjResult
|
||||
{
|
||||
std::string m_msg;
|
||||
std::vector<tinyobj::shape_t> m_shapes;
|
||||
tinyobj::attrib_t m_attribute;
|
||||
std::vector<bt_tinyobj::shape_t> m_shapes;
|
||||
bt_tinyobj::attrib_t m_attribute;
|
||||
};
|
||||
|
||||
static b3HashMap<b3HashString, CachedObjResult> gCachedObjResults;
|
||||
@@ -32,8 +32,8 @@ void b3EnableFileCaching(int enable)
|
||||
}
|
||||
|
||||
std::string LoadFromCachedOrFromObj(
|
||||
tinyobj::attrib_t& attribute,
|
||||
std::vector<tinyobj::shape_t>& shapes, // [output]
|
||||
bt_tinyobj::attrib_t& attribute,
|
||||
std::vector<bt_tinyobj::shape_t>& shapes, // [output]
|
||||
const char* filename,
|
||||
const char* mtl_basepath,
|
||||
struct CommonFileIOInterface* fileIO)
|
||||
@@ -47,7 +47,7 @@ std::string LoadFromCachedOrFromObj(
|
||||
return result.m_msg;
|
||||
}
|
||||
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, filename, mtl_basepath, fileIO);
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, filename, mtl_basepath, fileIO);
|
||||
CachedObjResult result;
|
||||
result.m_msg = err;
|
||||
result.m_shapes = shapes;
|
||||
@@ -62,10 +62,10 @@ std::string LoadFromCachedOrFromObj(
|
||||
GLInstanceGraphicsShape* LoadMeshFromObj(const char* relativeFileName, const char* materialPrefixPath, struct CommonFileIOInterface* fileIO)
|
||||
{
|
||||
B3_PROFILE("LoadMeshFromObj");
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
{
|
||||
B3_PROFILE("tinyobj::LoadObj2");
|
||||
B3_PROFILE("bt_tinyobj::LoadObj2");
|
||||
std::string err = LoadFromCachedOrFromObj(attribute, shapes, relativeFileName, materialPrefixPath, fileIO);
|
||||
}
|
||||
|
||||
|
||||
@@ -9,8 +9,8 @@ int b3IsFileCachingEnabled();
|
||||
void b3EnableFileCaching(int enable);
|
||||
|
||||
std::string LoadFromCachedOrFromObj(
|
||||
tinyobj::attrib_t& attribute,
|
||||
std::vector<tinyobj::shape_t>& shapes, // [output]
|
||||
bt_tinyobj::attrib_t& attribute,
|
||||
std::vector<bt_tinyobj::shape_t>& shapes, // [output]
|
||||
const char* filename,
|
||||
const char* mtl_basepath,
|
||||
struct CommonFileIOInterface* fileIO);
|
||||
|
||||
@@ -9,7 +9,7 @@
|
||||
#include "../../OpenGLWindow/GLInstancingRenderer.h"
|
||||
#include "../../OpenGLWindow/GLInstanceGraphicsShape.h"
|
||||
|
||||
GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, bool flatShading)
|
||||
GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, bool flatShading)
|
||||
{
|
||||
b3AlignedObjectArray<GLInstanceVertex>* vertices = new b3AlignedObjectArray<GLInstanceVertex>;
|
||||
{
|
||||
@@ -19,7 +19,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
for (int f = 0; f < faceCount; f += 3)
|
||||
@@ -36,7 +36,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx0;
|
||||
tinyobj::index_t v_0 = shape.mesh.indices[f];
|
||||
bt_tinyobj::index_t v_0 = shape.mesh.indices[f];
|
||||
vtx0.xyzw[0] = attribute.vertices[3 * v_0.vertex_index];
|
||||
vtx0.xyzw[1] = attribute.vertices[3 * v_0.vertex_index + 1];
|
||||
vtx0.xyzw[2] = attribute.vertices[3 * v_0.vertex_index + 2];
|
||||
@@ -65,7 +65,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx1;
|
||||
tinyobj::index_t v_1 = shape.mesh.indices[f + 1];
|
||||
bt_tinyobj::index_t v_1 = shape.mesh.indices[f + 1];
|
||||
vtx1.xyzw[0] = attribute.vertices[3 * v_1.vertex_index];
|
||||
vtx1.xyzw[1] = attribute.vertices[3 * v_1.vertex_index + 1];
|
||||
vtx1.xyzw[2] = attribute.vertices[3 * v_1.vertex_index + 2];
|
||||
@@ -94,7 +94,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx2;
|
||||
tinyobj::index_t v_2 = shape.mesh.indices[f + 2];
|
||||
bt_tinyobj::index_t v_2 = shape.mesh.indices[f + 2];
|
||||
vtx2.xyzw[0] = attribute.vertices[3 * v_2.vertex_index];
|
||||
vtx2.xyzw[1] = attribute.vertices[3 * v_2.vertex_index + 1];
|
||||
vtx2.xyzw[2] = attribute.vertices[3 * v_2.vertex_index + 2];
|
||||
|
||||
@@ -4,6 +4,6 @@
|
||||
#include "../../ThirdPartyLibs/Wavefront/tiny_obj_loader.h"
|
||||
#include <vector>
|
||||
|
||||
struct GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, bool flatShading = false);
|
||||
struct GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, bool flatShading = false);
|
||||
|
||||
#endif //WAVEFRONT2GRAPHICS_H
|
||||
|
||||
@@ -483,6 +483,12 @@ void BulletURDFImporter::getMassAndInertia(int linkIndex, btScalar& mass, btVect
|
||||
}
|
||||
|
||||
bool BulletURDFImporter::getJointInfo2(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity) const
|
||||
{
|
||||
btScalar twistLimit;
|
||||
return getJointInfo3(urdfLinkIndex, parent2joint, linkTransformInWorld, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction, jointMaxForce, jointMaxVelocity, twistLimit);
|
||||
}
|
||||
|
||||
bool BulletURDFImporter::getJointInfo3(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity, btScalar& twistLimit) const
|
||||
{
|
||||
jointLowerLimit = 0.f;
|
||||
jointUpperLimit = 0.f;
|
||||
@@ -510,6 +516,7 @@ bool BulletURDFImporter::getJointInfo2(int urdfLinkIndex, btTransform& parent2jo
|
||||
jointFriction = pj->m_jointFriction;
|
||||
jointMaxForce = pj->m_effortLimit;
|
||||
jointMaxVelocity = pj->m_velocityLimit;
|
||||
twistLimit = pj->m_twistLimit;
|
||||
return true;
|
||||
}
|
||||
else
|
||||
@@ -540,7 +547,7 @@ bool BulletURDFImporter::getRootTransformInWorld(btTransform& rootTransformInWor
|
||||
return true;
|
||||
}
|
||||
|
||||
static btCollisionShape* createConvexHullFromShapes(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, const btVector3& geomScale, int flags)
|
||||
static btCollisionShape* createConvexHullFromShapes(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, const btVector3& geomScale, int flags)
|
||||
{
|
||||
B3_PROFILE("createConvexHullFromShapes");
|
||||
btCompoundShape* compound = new btCompoundShape();
|
||||
@@ -553,7 +560,7 @@ static btCollisionShape* createConvexHullFromShapes(const tinyobj::attrib_t& att
|
||||
{
|
||||
btConvexHullShape* convexHull = new btConvexHullShape();
|
||||
convexHull->setMargin(gUrdfDefaultCollisionMargin);
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
for (int f = 0; f < faceCount; f += 3)
|
||||
@@ -747,9 +754,9 @@ btCollisionShape* BulletURDFImporter::convertURDFToCollisionShape(const UrdfColl
|
||||
}
|
||||
else
|
||||
{
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, collision->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, collision->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
//create a convex hull for each shape, and store it in a btCompoundShape
|
||||
shape = createConvexHullFromShapes(attribute, shapes, collision->m_geometry.m_meshScale, m_data->m_flags);
|
||||
m_data->m_bulletCollisionShape2UrdfCollision.insert(shape, *collision);
|
||||
@@ -1534,3 +1541,8 @@ const struct UrdfDeformable& BulletURDFImporter::getDeformableModel() const
|
||||
{
|
||||
return m_data->m_urdfParser.getDeformable();
|
||||
}
|
||||
|
||||
const struct UrdfReducedDeformable& BulletURDFImporter::getReducedDeformableModel() const
|
||||
{
|
||||
return m_data->m_urdfParser.getReducedDeformable();
|
||||
}
|
||||
|
||||
@@ -60,6 +60,7 @@ public:
|
||||
|
||||
virtual bool getJointInfo(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction) const;
|
||||
virtual bool getJointInfo2(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity) const;
|
||||
virtual bool getJointInfo3(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity, btScalar& twistLimit) const;
|
||||
|
||||
virtual bool getRootTransformInWorld(btTransform& rootTransformInWorld) const;
|
||||
virtual void setRootTransformInWorld(const btTransform& rootTransformInWorld);
|
||||
@@ -92,6 +93,7 @@ public:
|
||||
virtual void setEnableTinyRenderer(bool enable);
|
||||
void convertURDFToVisualShapeInternal(const struct UrdfVisual* visual, const char* urdfPathPrefix, const class btTransform& visualTransform, btAlignedObjectArray<struct GLInstanceVertex>& verticesOut, btAlignedObjectArray<int>& indicesOut, btAlignedObjectArray<struct BulletURDFTexture>& texturesOut, struct b3ImportMeshData& meshData) const;
|
||||
const struct UrdfDeformable& getDeformableModel() const;
|
||||
const struct UrdfReducedDeformable& getReducedDeformableModel() const;
|
||||
};
|
||||
|
||||
#endif //BULLET_URDF_IMPORTER_H
|
||||
|
||||
@@ -33,6 +33,10 @@ class btRigidBody* MyMultiBodyCreator::allocateRigidBody(int urdfLinkIndex, btSc
|
||||
{
|
||||
btRigidBody::btRigidBodyConstructionInfo rbci(mass, 0, colShape, localInertiaDiagonal);
|
||||
rbci.m_startWorldTransform = initialWorldTrans;
|
||||
btScalar sleep_threshold = btScalar(0.22360679775);//sqrt(0.05) to be similar to btMultiBody (SLEEP_THRESHOLD)
|
||||
rbci.m_angularSleepingThreshold = sleep_threshold;
|
||||
rbci.m_linearSleepingThreshold = sleep_threshold;
|
||||
|
||||
btRigidBody* body = new btRigidBody(rbci);
|
||||
if (m_rigidBody == 0)
|
||||
{
|
||||
|
||||
@@ -10,6 +10,9 @@
|
||||
#include "BulletDynamics/Dynamics/btRigidBody.h"
|
||||
#include "BulletDynamics/Featherstone/btMultiBodyLinkCollider.h"
|
||||
#include "BulletDynamics/Featherstone/btMultiBodyJointLimitConstraint.h"
|
||||
#include "BulletDynamics/Featherstone/btMultiBodySphericalJointLimit.h"
|
||||
|
||||
|
||||
#include "BulletDynamics/ConstraintSolver/btGeneric6DofSpring2Constraint.h"
|
||||
#include "URDF2Bullet.h"
|
||||
#include "URDFImporterInterface.h"
|
||||
@@ -199,7 +202,15 @@ btScalar tmpUrdfScaling = 2;
|
||||
btTransform ConvertURDF2BulletInternal(
|
||||
const URDFImporterInterface& u2b, MultiBodyCreationInterface& creation,
|
||||
URDF2BulletCachedData& cache, int urdfLinkIndex,
|
||||
const btTransform& parentTransformInWorldSpace, btMultiBodyDynamicsWorld* world1,
|
||||
const btTransform& parentTransformInWorldSpace,
|
||||
|
||||
#ifdef USE_DISCRETE_DYNAMICS_WORLD
|
||||
btDiscreteDynamicsWorld* world1,
|
||||
#else
|
||||
btMultiBodyDynamicsWorld* world1,
|
||||
#endif
|
||||
|
||||
|
||||
bool createMultiBody, const char* pathPrefix,
|
||||
int flags, UrdfVisualShapeCache* cachedLinkGraphicsShapesIn, UrdfVisualShapeCache* cachedLinkGraphicsShapesOut, bool recursive)
|
||||
{
|
||||
@@ -251,8 +262,8 @@ btTransform ConvertURDF2BulletInternal(
|
||||
btScalar jointFriction;
|
||||
btScalar jointMaxForce;
|
||||
btScalar jointMaxVelocity;
|
||||
|
||||
bool hasParentJoint = u2b.getJointInfo2(urdfLinkIndex, parent2joint, linkTransformInWorldSpace, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction, jointMaxForce, jointMaxVelocity);
|
||||
btScalar twistLimit;
|
||||
bool hasParentJoint = u2b.getJointInfo3(urdfLinkIndex, parent2joint, linkTransformInWorldSpace, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction, jointMaxForce, jointMaxVelocity, twistLimit);
|
||||
std::string linkName = u2b.getLinkName(urdfLinkIndex);
|
||||
|
||||
if (flags & CUF_USE_SDF)
|
||||
@@ -414,6 +425,20 @@ btTransform ConvertURDF2BulletInternal(
|
||||
cache.m_bulletMultiBody->setupSpherical(mbLinkIndex, mass, localInertiaDiagonal, mbParentIndex,
|
||||
parentRotToThis, offsetInA.getOrigin(), -offsetInB.getOrigin(),
|
||||
disableParentCollision);
|
||||
|
||||
|
||||
//create a spherical joint limit, swing_x,. swing_y and twist
|
||||
//jointLowerLimit <= jointUpperLimit)
|
||||
if (jointUpperLimit > 0 && jointLowerLimit> 0 && twistLimit > 0 && jointMaxForce>0)
|
||||
{
|
||||
btMultiBodySphericalJointLimit* con = new btMultiBodySphericalJointLimit(cache.m_bulletMultiBody, mbLinkIndex,
|
||||
jointLowerLimit,
|
||||
jointUpperLimit,
|
||||
twistLimit,
|
||||
jointMaxForce);
|
||||
world1->addMultiBodyConstraint(con);
|
||||
}
|
||||
|
||||
}
|
||||
else
|
||||
{
|
||||
@@ -505,6 +530,7 @@ btTransform ConvertURDF2BulletInternal(
|
||||
creation.addLinkMapping(urdfLinkIndex, mbLinkIndex);
|
||||
if (createMultiBody)
|
||||
{
|
||||
#ifndef USE_DISCRETE_DYNAMICS_WORLD
|
||||
cache.m_bulletMultiBody->setupRevolute(mbLinkIndex, mass, localInertiaDiagonal, mbParentIndex,
|
||||
parentRotToThis, quatRotate(offsetInB.getRotation(),
|
||||
jointAxisInJointSpace),
|
||||
@@ -519,8 +545,10 @@ btTransform ConvertURDF2BulletInternal(
|
||||
btMultiBodyConstraint* con = new btMultiBodyJointLimitConstraint(cache.m_bulletMultiBody, mbLinkIndex, jointLowerLimit, jointUpperLimit);
|
||||
world1->addMultiBodyConstraint(con);
|
||||
}
|
||||
#endif
|
||||
}
|
||||
else
|
||||
|
||||
{
|
||||
btGeneric6DofSpring2Constraint* dof6 = 0;
|
||||
if (jointType == URDFRevoluteJoint && jointLowerLimit <= jointUpperLimit)
|
||||
@@ -560,6 +588,7 @@ btTransform ConvertURDF2BulletInternal(
|
||||
|
||||
if (createMultiBody)
|
||||
{
|
||||
#ifndef USE_DISCRETE_DYNAMICS_WORLD
|
||||
cache.m_bulletMultiBody->setupPrismatic(mbLinkIndex, mass, localInertiaDiagonal, mbParentIndex,
|
||||
parentRotToThis, quatRotate(offsetInB.getRotation(), jointAxisInJointSpace), offsetInA.getOrigin(), //parent2joint.getOrigin(),
|
||||
-offsetInB.getOrigin(),
|
||||
@@ -574,6 +603,7 @@ btTransform ConvertURDF2BulletInternal(
|
||||
world1->addMultiBodyConstraint(con);
|
||||
}
|
||||
//printf("joint lower limit=%d, upper limit = %f\n", jointLowerLimit, jointUpperLimit);
|
||||
#endif
|
||||
}
|
||||
else
|
||||
{
|
||||
@@ -775,10 +805,18 @@ bool MyIntCompareFunc(childParentIndex a, childParentIndex b)
|
||||
}
|
||||
|
||||
|
||||
|
||||
|
||||
|
||||
void ConvertURDF2Bullet(
|
||||
const URDFImporterInterface& u2b, MultiBodyCreationInterface& creation,
|
||||
const btTransform& rootTransformInWorldSpace,
|
||||
|
||||
#ifdef USE_DISCRETE_DYNAMICS_WORLD
|
||||
btDiscreteDynamicsWorld* world1,
|
||||
#else
|
||||
btMultiBodyDynamicsWorld* world1,
|
||||
#endif
|
||||
bool createMultiBody, const char* pathPrefix, int flags, UrdfVisualShapeCache* cachedLinkGraphicsShapes)
|
||||
{
|
||||
URDF2BulletCachedData cache;
|
||||
@@ -829,7 +867,7 @@ void ConvertURDF2Bullet(
|
||||
{
|
||||
*cachedLinkGraphicsShapes = cachedLinkGraphicsShapesOut;
|
||||
}
|
||||
|
||||
#ifndef USE_DISCRETE_DYNAMICS_WORLD
|
||||
if (world1 && cache.m_bulletMultiBody)
|
||||
{
|
||||
B3_PROFILE("Post process");
|
||||
@@ -855,4 +893,5 @@ void ConvertURDF2Bullet(
|
||||
|
||||
world1->addMultiBody(mb);
|
||||
}
|
||||
#endif
|
||||
}
|
||||
|
||||
@@ -8,6 +8,7 @@
|
||||
class btVector3;
|
||||
class btTransform;
|
||||
class btMultiBodyDynamicsWorld;
|
||||
class btDiscreteDynamicsWorld;
|
||||
class btTransform;
|
||||
|
||||
class URDFImporterInterface;
|
||||
@@ -20,7 +21,18 @@ struct UrdfVisualShapeCache
|
||||
btAlignedObjectArray<UrdfMaterialColor> m_cachedUrdfLinkColors;
|
||||
btAlignedObjectArray<int> m_cachedUrdfLinkVisualShapeIndices;
|
||||
};
|
||||
//#define USE_DISCRETE_DYNAMICS_WORLD
|
||||
#ifdef USE_DISCRETE_DYNAMICS_WORLD
|
||||
void ConvertURDF2Bullet(const URDFImporterInterface& u2b,
|
||||
MultiBodyCreationInterface& creationCallback,
|
||||
const btTransform& rootTransformInWorldSpace,
|
||||
btDiscreteDynamicsWorld* world,
|
||||
bool createMultiBody,
|
||||
const char* pathPrefix,
|
||||
int flags = 0,
|
||||
UrdfVisualShapeCache* cachedLinkGraphicsShapes = 0);
|
||||
|
||||
#else
|
||||
void ConvertURDF2Bullet(const URDFImporterInterface& u2b,
|
||||
MultiBodyCreationInterface& creationCallback,
|
||||
const btTransform& rootTransformInWorldSpace,
|
||||
@@ -29,5 +41,5 @@ void ConvertURDF2Bullet(const URDFImporterInterface& u2b,
|
||||
const char* pathPrefix,
|
||||
int flags = 0,
|
||||
UrdfVisualShapeCache* cachedLinkGraphicsShapes = 0);
|
||||
|
||||
#endif
|
||||
#endif //_URDF2BULLET_H
|
||||
|
||||
@@ -64,6 +64,13 @@ public:
|
||||
return getJointInfo(urdfLinkIndex, parent2joint, linkTransformInWorld, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction);
|
||||
};
|
||||
|
||||
virtual bool getJointInfo3(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity, btScalar& twistLimit) const
|
||||
{
|
||||
//backwards compatibility for custom file importers
|
||||
twistLimit = 0;
|
||||
return getJointInfo2(urdfLinkIndex, parent2joint, linkTransformInWorld, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction, jointMaxForce, jointMaxVelocity);
|
||||
};
|
||||
|
||||
virtual bool getRootTransformInWorld(btTransform& rootTransformInWorld) const = 0;
|
||||
virtual void setRootTransformInWorld(const btTransform& rootTransformInWorld) {}
|
||||
|
||||
|
||||
@@ -94,7 +94,8 @@ static void ParseUserData(const XMLElement* element, btHashMap<btHashString,
|
||||
if (!key_attr) {
|
||||
logger->reportError("User data tag must have a key attribute.");
|
||||
}
|
||||
user_data.insert(key_attr, user_data_xml->GetText());
|
||||
const char* text = user_data_xml->GetText();
|
||||
user_data.insert(key_attr, text ? text : "");
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -1281,6 +1282,171 @@ bool UrdfParser::parseDeformable(UrdfModel& model, tinyxml2::XMLElement* config,
|
||||
return true;
|
||||
}
|
||||
|
||||
bool UrdfParser::parseReducedDeformable(UrdfModel& model, tinyxml2::XMLElement* config, ErrorLogger* logger)
|
||||
{
|
||||
UrdfReducedDeformable& reduced_deformable = model.m_reducedDeformable;
|
||||
const char* name = config->Attribute("name");
|
||||
if (!name)
|
||||
{
|
||||
logger->reportError("Reduced deformable with no name");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_name = name;
|
||||
|
||||
{
|
||||
XMLElement* numModes_xml = config->FirstChildElement("num_modes");
|
||||
if (numModes_xml)
|
||||
{
|
||||
if (!numModes_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("numModes_xml element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_numModes = urdfLexicalCast<double>(numModes_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* mass_xml = config->FirstChildElement("mass");
|
||||
if (mass_xml)
|
||||
{
|
||||
if (!mass_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("mass_xml element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_mass = urdfLexicalCast<double>(mass_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* stiffnessScale_xml = config->FirstChildElement("stiffness_scale");
|
||||
if (stiffnessScale_xml)
|
||||
{
|
||||
if (!stiffnessScale_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("stiffnessScale_xml element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_stiffnessScale = urdfLexicalCast<double>(stiffnessScale_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* collisionMargin_xml = config->FirstChildElement("collision_margin");
|
||||
if (collisionMargin_xml)
|
||||
{
|
||||
if (!collisionMargin_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("collision_margin element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_collisionMargin = urdfLexicalCast<double>(collisionMargin_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* erp_xml = config->FirstChildElement("erp");
|
||||
if (erp_xml)
|
||||
{
|
||||
if (!erp_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("friction element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_erp = urdfLexicalCast<double>(erp_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* cfm_xml = config->FirstChildElement("cfm");
|
||||
if (cfm_xml)
|
||||
{
|
||||
if (!cfm_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("cfm element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_cfm = urdfLexicalCast<double>(cfm_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* damping_xml = config->FirstChildElement("damping_coefficient");
|
||||
if (damping_xml)
|
||||
{
|
||||
if (!damping_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("damping_coefficient element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_damping = urdfLexicalCast<double>(damping_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
{
|
||||
XMLElement* friction_xml = config->FirstChildElement("friction");
|
||||
if (friction_xml)
|
||||
{
|
||||
if (!friction_xml->Attribute("value"))
|
||||
{
|
||||
logger->reportError("friction element must have value attribute");
|
||||
return false;
|
||||
}
|
||||
reduced_deformable.m_friction = urdfLexicalCast<double>(friction_xml->Attribute("value"));
|
||||
}
|
||||
}
|
||||
|
||||
XMLElement* vis_xml = config->FirstChildElement("visual");
|
||||
if (!vis_xml)
|
||||
{
|
||||
logger->reportError("expected an visual element");
|
||||
return false;
|
||||
}
|
||||
if (!vis_xml->Attribute("filename"))
|
||||
{
|
||||
logger->reportError("expected a filename for visual geometry");
|
||||
return false;
|
||||
}
|
||||
std::string fn = vis_xml->Attribute("filename");
|
||||
reduced_deformable.m_visualFileName = fn;
|
||||
|
||||
int out_type(0);
|
||||
bool success = UrdfFindMeshFile(m_fileIO,
|
||||
model.m_sourceFile, fn, sourceFileLocation(vis_xml),
|
||||
&reduced_deformable.m_visualFileName, &out_type);
|
||||
|
||||
if (!success)
|
||||
{
|
||||
// warning already printed
|
||||
return false;
|
||||
}
|
||||
|
||||
// collision mesh is optional
|
||||
XMLElement* col_xml = config->FirstChildElement("collision");
|
||||
if (col_xml)
|
||||
{
|
||||
if (!col_xml->Attribute("filename"))
|
||||
{
|
||||
logger->reportError("expected a filename for collision geoemtry");
|
||||
return false;
|
||||
}
|
||||
fn = col_xml->Attribute("filename");
|
||||
success = UrdfFindMeshFile(m_fileIO,
|
||||
model.m_sourceFile, fn, sourceFileLocation(col_xml),
|
||||
&reduced_deformable.m_simFileName, &out_type);
|
||||
|
||||
if (!success)
|
||||
{
|
||||
// warning already printed
|
||||
return false;
|
||||
}
|
||||
}
|
||||
|
||||
ParseUserData(config, reduced_deformable.m_userData, logger);
|
||||
return true;
|
||||
}
|
||||
|
||||
bool UrdfParser::parseJointLimits(UrdfJoint& joint, XMLElement* config, ErrorLogger* logger)
|
||||
{
|
||||
joint.m_lowerLimit = 0.f;
|
||||
@@ -1289,6 +1455,7 @@ bool UrdfParser::parseJointLimits(UrdfJoint& joint, XMLElement* config, ErrorLog
|
||||
joint.m_velocityLimit = 0.f;
|
||||
joint.m_jointDamping = 0.f;
|
||||
joint.m_jointFriction = 0.f;
|
||||
joint.m_twistLimit = -1;
|
||||
|
||||
if (m_parseSDF)
|
||||
{
|
||||
@@ -1303,13 +1470,19 @@ bool UrdfParser::parseJointLimits(UrdfJoint& joint, XMLElement* config, ErrorLog
|
||||
{
|
||||
joint.m_upperLimit = urdfLexicalCast<double>(upper_xml->GetText());
|
||||
}
|
||||
|
||||
XMLElement* twist_xml = config->FirstChildElement("twist");
|
||||
if (twist_xml)
|
||||
{
|
||||
joint.m_twistLimit = urdfLexicalCast<double>(twist_xml->GetText());
|
||||
}
|
||||
|
||||
XMLElement* effort_xml = config->FirstChildElement("effort");
|
||||
if (effort_xml)
|
||||
{
|
||||
joint.m_effortLimit = urdfLexicalCast<double>(effort_xml->GetText());
|
||||
}
|
||||
|
||||
|
||||
XMLElement* velocity_xml = config->FirstChildElement("velocity");
|
||||
if (velocity_xml)
|
||||
{
|
||||
@@ -1336,6 +1509,14 @@ bool UrdfParser::parseJointLimits(UrdfJoint& joint, XMLElement* config, ErrorLog
|
||||
joint.m_upperLimit *= m_urdfScaling;
|
||||
}
|
||||
|
||||
|
||||
const char* twist_str = config->Attribute("twist");
|
||||
if (twist_str)
|
||||
{
|
||||
joint.m_twistLimit = urdfLexicalCast<double>(twist_str);
|
||||
}
|
||||
|
||||
|
||||
// Get joint effort limit
|
||||
const char* effort_str = config->Attribute("effort");
|
||||
if (effort_str)
|
||||
@@ -1343,6 +1524,7 @@ bool UrdfParser::parseJointLimits(UrdfJoint& joint, XMLElement* config, ErrorLog
|
||||
joint.m_effortLimit = urdfLexicalCast<double>(effort_str);
|
||||
}
|
||||
|
||||
|
||||
// Get joint velocity limit
|
||||
const char* velocity_str = config->Attribute("velocity");
|
||||
if (velocity_str)
|
||||
@@ -2109,9 +2291,16 @@ bool UrdfParser::loadUrdf(const char* urdfText, ErrorLogger* logger, bool forceF
|
||||
// logger->printMessage(msg);
|
||||
|
||||
|
||||
|
||||
XMLElement* reduced_deformable_xml = robot_xml->FirstChildElement("reduced_deformable");
|
||||
if (reduced_deformable_xml) {
|
||||
return parseReducedDeformable(m_urdf2Model, reduced_deformable_xml, logger);
|
||||
}
|
||||
|
||||
XMLElement* deformable_xml = robot_xml->FirstChildElement("deformable");
|
||||
if(deformable_xml)
|
||||
if (deformable_xml) {
|
||||
return parseDeformable(m_urdf2Model, deformable_xml, logger);
|
||||
}
|
||||
|
||||
for (XMLElement* link_xml = robot_xml->FirstChildElement("link"); link_xml; link_xml = link_xml->NextSiblingElement("link"))
|
||||
{
|
||||
|
||||
@@ -189,13 +189,15 @@ struct UrdfJoint
|
||||
|
||||
double m_jointDamping;
|
||||
double m_jointFriction;
|
||||
double m_twistLimit;
|
||||
UrdfJoint()
|
||||
: m_lowerLimit(0),
|
||||
m_upperLimit(-1),
|
||||
m_effortLimit(0),
|
||||
m_velocityLimit(0),
|
||||
m_jointDamping(0),
|
||||
m_jointFriction(0)
|
||||
m_jointFriction(0),
|
||||
m_twistLimit(-1)
|
||||
{
|
||||
}
|
||||
};
|
||||
@@ -245,6 +247,37 @@ struct UrdfDeformable
|
||||
}
|
||||
};
|
||||
|
||||
struct UrdfReducedDeformable
|
||||
{
|
||||
std::string m_name;
|
||||
int m_numModes;
|
||||
|
||||
double m_mass;
|
||||
double m_stiffnessScale;
|
||||
double m_erp;
|
||||
double m_cfm;
|
||||
double m_friction;
|
||||
double m_collisionMargin;
|
||||
double m_damping;
|
||||
|
||||
std::string m_visualFileName;
|
||||
std::string m_simFileName;
|
||||
btHashMap<btHashString, std::string> m_userData;
|
||||
|
||||
UrdfReducedDeformable()
|
||||
: m_numModes(1),
|
||||
m_mass(1),
|
||||
m_stiffnessScale(100),
|
||||
m_erp(0.2), // generally, 0.2 is a good value for erp and cfm
|
||||
m_cfm(0.2),
|
||||
m_friction(0),
|
||||
m_collisionMargin(0.02),
|
||||
m_damping(0),
|
||||
m_visualFileName(""),
|
||||
m_simFileName("")
|
||||
{}
|
||||
};
|
||||
|
||||
struct UrdfModel
|
||||
{
|
||||
std::string m_name;
|
||||
@@ -254,6 +287,7 @@ struct UrdfModel
|
||||
btHashMap<btHashString, UrdfLink*> m_links;
|
||||
btHashMap<btHashString, UrdfJoint*> m_joints;
|
||||
UrdfDeformable m_deformable;
|
||||
UrdfReducedDeformable m_reducedDeformable;
|
||||
// Maps user data keys to user data values.
|
||||
btHashMap<btHashString, std::string> m_userData;
|
||||
|
||||
@@ -331,7 +365,7 @@ protected:
|
||||
bool parseSensor(UrdfModel& model, UrdfLink& link, UrdfJoint& joint, tinyxml2::XMLElement* config, ErrorLogger* logger);
|
||||
bool parseLameCoefficients(LameCoefficients& lameCoefficients, tinyxml2::XMLElement* config, ErrorLogger* logger);
|
||||
bool parseDeformable(UrdfModel& model, tinyxml2::XMLElement* config, ErrorLogger* logger);
|
||||
|
||||
bool parseReducedDeformable(UrdfModel& model, tinyxml2::XMLElement* config, ErrorLogger* logger);
|
||||
|
||||
public:
|
||||
UrdfParser(struct CommonFileIOInterface* fileIO);
|
||||
@@ -411,6 +445,11 @@ public:
|
||||
return m_urdf2Model.m_deformable;
|
||||
}
|
||||
|
||||
const UrdfReducedDeformable& getReducedDeformable() const
|
||||
{
|
||||
return m_urdf2Model.m_reducedDeformable;
|
||||
}
|
||||
|
||||
bool mergeFixedLinks(UrdfModel& model, UrdfLink* link, ErrorLogger* logger, bool forceFixedBase, int level);
|
||||
bool printTree(UrdfLink* link, ErrorLogger* logger, int level);
|
||||
bool recreateModel(UrdfModel& model, UrdfLink* link, ErrorLogger* logger);
|
||||
|
||||
Some files were not shown because too many files have changed in this diff Show More
Reference in New Issue
Block a user