Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 erwincoumans |
63c4d67e33 | ||
|
Erwin Coumans
|
d1a4256b3a | ||
|
Erwin Coumans
|
6c888f4abd | ||
|
Erwin Coumans
|
bda00360fb | ||
|
Erwin Coumans
|
69783a8480 | ||
|
erwincoumans
|
e9c461b0ac | ||
|
erwincoumans
|
43d336fcad | ||
|
erwincoumans
|
5e89410409 | ||
|
ctingley
|
2c7918423d | ||
|
Ian Chen
|
d7f9d66207 | ||
|
Luke Bayes
|
335c18821f | ||
|
Erwin Coumans
|
6bb8d1123d | ||
|
Erwin Coumans
|
fcef2c81f2 | ||
|
erwincoumans
|
39b8de74df | ||
|
erwincoumans
|
e7193f8fdf | ||
|
Xinlei Wang
|
d9a4a7e703 | ||
|
Nate Koenig
|
94e5b69379 | ||
|
erwincoumans
|
0e59474e1c | ||
|
erwincoumans
|
c037d9ba27 | ||
|
Maarten Behn
|
e323404ac3 | ||
|
Maarten Behn
|
5c8dfe4b21 | ||
|
Maarten Behn
|
54cdf39933 | ||
|
Maarten Behn
|
2b4757f512 | ||
|
Maarten Behn
|
9dd446609a | ||
|
Johannes Brust
|
60512c7872 | ||
|
Johannes Brust
|
fa1d1fc8ee | ||
|
yo
|
8549f00502 | ||
|
erwincoumans
|
2c204c49e5 | ||
|
erwincoumans
|
327336d80b | ||
|
erwincoumans
|
dad061fc13 | ||
|
erwincoumans
|
daadfacfff | ||
|
erwincoumans
|
fd2fe1365a | ||
|
Matt Bennice
|
ee0100abbf | ||
|
Matt Bennice
|
555c0c6cd9 | ||
|
Matt Bennice
|
82b7fa6df0 | ||
|
Matt Bennice
|
c7a67d509e | ||
|
Hill Ma
|
dfdb6e2db9 | ||
|
Vitaly Buka
|
acbeea543b | ||
|
Sho Yamanishi
|
d19a418728 | ||
|
Vitaly Buka
|
6626ed1a89 | ||
|
erwincoumans
|
a1d96646c8 | ||
|
erwincoumans
|
466b76680b | ||
|
erwincoumans
|
19aa740d84 | ||
|
Erwin Coumans
|
4ca2de2fd7 | ||
|
Erwin Coumans
|
7ba2965a22 | ||
|
Erwin Coumans
|
56186db344 | ||
|
erwincoumans
|
2ad5f5a7d7 | ||
|
Erwin Coumans
|
b9df2190f1 | ||
|
Rémi Verschelde
|
cc3f3cf7ca | ||
|
erwincoumans
|
7dee3436e7 | ||
|
Erwin Coumans
|
657f347223 | ||
|
erwin coumans
|
fdab95dbab | ||
|
erwin coumans
|
a899725cc6 | ||
|
Erwin Coumans
|
ae4c1f8e72 | ||
|
erwin coumans
|
9185f93174 | ||
|
erwincoumans
|
e95657f80f | ||
|
Erwin Coumans
|
9eb945b1e8 | ||
|
Erwin Coumans
|
968b4356dc | ||
|
Erwin Coumans
|
957a46d840 | ||
|
Erwin Coumans
|
a3ec165915 | ||
|
erwincoumans
|
617df44898 | ||
|
erwincoumans
|
ce23bb9dce | ||
|
Erwin Coumans
|
f263c422e2 | ||
|
Erwin Coumans
|
31b9be82a1 | ||
|
erwincoumans
|
0edcbd693a | ||
|
Sebastian Jura
|
2a8d463fd3 | ||
|
Erwin Coumans
|
4f0673810c | ||
|
erwincoumans
|
cd771af26f | ||
|
erwincoumans
|
31aeeadb2d | ||
|
Szabolcs Dombi
|
aef1d3e27d | ||
|
Raphael Isemann
|
772dcf57ff | ||
|
erwincoumans
|
e306b274f1 | ||
|
Daniele Bartolini
|
66012fe215 | ||
|
Erwin Coumans
|
d3b4c27db4 | ||
|
erwincoumans
|
22d9eec148 | ||
|
Erwin Coumans
|
5e8a4717b9 | ||
|
erwincoumans
|
ae885be38d | ||
|
Erwin Coumans
|
0070e0d52b | ||
|
erwincoumans
|
5d75748c0d | ||
|
erwincoumans
|
b9117c780f | ||
|
erwincoumans
|
c07f6f66e8 | ||
|
erwincoumans
|
c0c03f279a | ||
|
Pawel
|
5e8343cffe | ||
|
Sandy Carter
|
35264f81bb | ||
|
Sandy
|
e4414c8023 | ||
|
Roker2
|
072439b8eb | ||
|
erwincoumans
|
ea715cc3b3 | ||
|
erwincoumans
|
6c300fbeee | ||
|
Chuyuan Kelly Fu
|
d63a721eaa | ||
|
Chuyuan Kelly Fu
|
158eb6d63b | ||
|
Erwin Coumans
|
e942db6f4d | ||
|
erwincoumans
|
e576dbe92c | ||
|
erwincoumans
|
4fbecfeddc | ||
|
erwincoumans
|
aee1ab63fe | ||
|
erwincoumans
|
3df6e1a721 | ||
|
erwincoumans
|
a8e1ce8273 | ||
|
erwincoumans
|
2e4e25b330 | ||
|
erwincoumans
|
6b35174ea9 | ||
|
erwincoumans
|
2b685e98ee | ||
|
Erwin Coumans
|
e262b2b7ee | ||
|
Erwin Coumans
|
3315190d97 | ||
|
Erwin Coumans
|
90414a5074 | ||
|
erwincoumans
|
b74bdfbbcf | ||
|
erwincoumans
|
0c40b73b0e | ||
|
erwincoumans
|
103db13379 | ||
|
erwincoumans
|
0ec6091efb | ||
|
erwincoumans
|
e32c0674e7 | ||
|
erwincoumans
|
34a471586e | ||
|
Erwin Coumans
|
dd93f73fc4 | ||
|
Chuyuan Kelly Fu
|
3fd61413df | ||
|
Chuyuan Kelly Fu
|
cf185a2d53 | ||
|
Chuyuan Kelly Fu
|
c9fe6638f8 | ||
|
tarsin
|
187b2bbc68 | ||
|
Chuyuan Kelly Fu
|
a8cf6008b7 | ||
|
Chuyuan Kelly Fu
|
c014789db0 | ||
|
Chuyuan Kelly Fu
|
4b12767b60 | ||
|
Chuyuan Kelly Fu
|
3088db22a2 | ||
|
jingyuc
|
5fd7ec99ba | ||
|
jingyuc
|
2c1cd798ea | ||
|
Jingyu Chen
|
e9a78e460c | ||
|
jingyuc
|
ca9d9b3ee6 | ||
|
erwincoumans
|
9f3c4123a2 | ||
|
jingyuc
|
c89a7054e9 | ||
|
Erwin Coumans
|
28b951c128 | ||
|
erwincoumans
|
267f983498 | ||
|
r-a-sattarov
|
6038bb2993 | ||
|
erwincoumans
|
58cde7b598 | ||
|
Erwin Coumans
|
9bfca83a8f | ||
|
Tigran Gasparian
|
d26dbef2dc | ||
|
erwincoumans
|
88651395b7 | ||
|
Chris E. Mower
|
713392b789 | ||
|
Peng Xu
|
19d6304d8d | ||
|
Peng Xu
|
751fd3fb65 | ||
|
jingyuc
|
41ce1cca24 | ||
|
Chuyuan Kelly Fu
|
60b6df94d9 | ||
|
Chuyuan Kelly Fu
|
372c8e07bc | ||
|
Chuyuan Kelly Fu
|
548d6af901 | ||
|
Chuyuan Kelly Fu
|
807cf3d387 | ||
|
Chuyuan Kelly Fu
|
bdba9fa2e0 | ||
|
Chuyuan Kelly Fu
|
4e5b3f34c9 | ||
|
Chuyuan Kelly Fu
|
450c95d0b9 | ||
|
Chuyuan Kelly Fu
|
236d39d2ec | ||
|
Chuyuan Kelly Fu
|
07de08a38e | ||
|
Chuyuan Kelly Fu
|
fb3b306af1 | ||
|
erwincoumans
|
9eac022ffa | ||
|
erwincoumans
|
22ef34bb69 | ||
|
Jingyu Chen
|
ca334946a7 | ||
|
jaecheol.sim
|
7d7fb1e291 | ||
|
Jingyu Chen
|
c159305910 | ||
|
erwincoumans
|
2cad239c00 | ||
|
Erwin Coumans
|
256fe2ec70 | ||
|
erwincoumans
|
f0f2a952e1 | ||
|
jingyuc
|
f8abdd1fe1 | ||
|
jingyuc
|
11b79c3838 | ||
|
jingyuc
|
cf7b142063 | ||
|
jingyuc
|
6a78b4bb07 | ||
|
jingyuc
|
bfef75f871 | ||
|
jingyuc
|
fbeafa0249 | ||
|
Erwin Coumans
|
6906198132 | ||
|
Erwin Coumans
|
5cd8160086 | ||
|
Erwin Coumans
|
b602045665 | ||
|
Erwin Coumans
|
6cc267f84b | ||
|
Peter
|
2a5a1d4935 | ||
|
Jelle
|
06a212e667 | ||
|
erwincoumans
|
478da7469a | ||
|
erwincoumans
|
dc72081eb1 | ||
|
Erwin Coumans
|
5d1c8a2ece | ||
|
James Braza
|
51a5aa8026 | ||
|
James Braza
|
0e114e9f9b | ||
|
James Braza
|
72dc1bb4dd | ||
|
James Braza
|
878e3d57f6 | ||
|
erwincoumans
|
f84b523c05 | ||
|
Erwin Coumans
|
0ab3b9d9f7 | ||
|
erwincoumans
|
0fac8209c9 | ||
|
Erwin Coumans
|
610fb2c117 | ||
|
Erwin Coumans
|
0aecbb9cdc | ||
|
Jingyu Chen
|
c9a2d733ad | ||
|
Jingyu Chen
|
f19133e410 | ||
|
Jingyu Chen
|
1feb81463a | ||
|
erwincoumans
|
578523eab4 | ||
|
jingyuc
|
4634077733 | ||
|
jyc-n
|
a018d63fb3 | ||
|
erwincoumans
|
6a59241074 | ||
|
Erwin Coumans
|
9c380f18f6 | ||
|
jingyuc
|
96605f7a8c | ||
|
erwincoumans
|
fa50f195e6 | ||
|
Chase Kew
|
adf75169d8 | ||
|
jingyuc
|
6fb7bd9a94 | ||
|
jingyuc
|
f729fbda95 | ||
|
jingyuc
|
9fae47667b | ||
|
jingyuc
|
8efd0296ab | ||
|
jingyuc
|
bc8adf7bd1 | ||
|
jingyuc
|
4c9d6275aa | ||
|
jingyuc
|
0b641b51d7 | ||
|
erwincoumans
|
946d500c8e | ||
|
jingyuc
|
0279a5a500 | ||
|
jingyuc
|
8c118515b8 | ||
|
jingyuc
|
007eea15cb | ||
|
jingyuc
|
2d08d4047a | ||
|
jingyuc
|
18f81dcaea | ||
|
jingyuc
|
676221fb3e | ||
|
erwincoumans
|
10f72b9b5d | ||
|
erwincoumans
|
ccafe333d1 | ||
|
erwincoumans
|
691ad46baa | ||
|
erwincoumans
|
a9a103fc8c | ||
|
erwincoumans
|
40aeecb72e | ||
|
erwincoumans
|
88c04a8eae | ||
|
Erwin Coumans
|
a3005879bb | ||
|
Erwin Coumans
|
e3b98615f1 | ||
|
jingyuc
|
c2072b5538 | ||
|
Erwin Coumans
|
a84071ee67 | ||
|
Erwin Coumans
|
6088293149 | ||
|
jingyuc
|
7fafbd7718 | ||
|
jingyuc
|
e386b55543 | ||
|
erwincoumans
|
98254b51a9 | ||
|
jingyuc
|
3ec4d68323 | ||
|
jingyuc
|
0a6f278663 | ||
|
jingyuc
|
d7fb9e8a92 | ||
|
jingyuc
|
df661fde15 | ||
|
Chuyuan Fu
|
a2aada62ae | ||
|
erwincoumans
|
a62fb187a5 | ||
|
erwincoumans
|
1dd3d8408e | ||
|
QiaodongCui
|
a672536f43 | ||
|
QiaodongCui
|
e9d40d0726 | ||
|
Stephen Tu
|
63446558cd | ||
|
jingyuc
|
2255e26e14 | ||
|
erwincoumans
|
ac3c283842 | ||
|
jingyuc
|
3540400a9d | ||
|
jingyuc
|
88863f92eb | ||
|
Tigran Gasparian
|
740d2b9783 | ||
|
jingyuc
|
e2f6430d19 | ||
|
Kentaro Wada
|
fd98afe764 | ||
|
Kentaro Wada
|
b22a2432b5 | ||
|
Erwin Coumans
|
1a670681f7 | ||
|
Erwin Coumans
|
e1ac14b23d | ||
|
erwincoumans
|
e4a450a53d | ||
|
erwincoumans
|
33cceed500 | ||
|
erwincoumans
|
d4598bf1cf | ||
|
erwincoumans
|
f79463b699 | ||
|
erwincoumans
|
aef54fed64 | ||
|
Max Argus
|
3c4cb80157 | ||
|
jingyuc
|
b5325a265f | ||
|
jingyuc
|
3a3d8c7a3a | ||
|
Johannes Brust
|
61d5bdb783 | ||
|
Kentaro Wada
|
00dcce85f5 | ||
|
jingyuc
|
d945e48af2 | ||
|
Wenhao Yu
|
af0bfc62ec | ||
|
Wenhao Yu
|
fd96062972 | ||
|
erwincoumans
|
48dc1c45da | ||
|
Erwin Coumans
|
90e331a239 | ||
|
Erwin Coumans
|
a8f088d4d3 | ||
|
Erwin Coumans
|
00567a5261 | ||
|
erwincoumans
|
aa49e19385 | ||
|
jingyuc
|
bd6e49bcc1 | ||
|
jingyuc
|
07cfa9a433 | ||
|
Rémi Verschelde
|
41f03e78a5 | ||
|
Erwin Coumans
|
6390db4bd6 | ||
|
jingyuc
|
1949710131 | ||
|
jingyuc
|
c4da596778 | ||
|
Erwin Coumans
|
931f93d266 | ||
|
Erwin Coumans
|
9d211393e4 | ||
|
Erwin Coumans
|
34d77242e5 | ||
|
Ariel Kwiatkowski
|
496e614f77 | ||
|
Rémi Verschelde
|
364796d1e5 | ||
|
Rémi Verschelde
|
ba65e909bc | ||
|
Johannes Brust
|
5795bd676f | ||
|
jingyuc
|
1bee1ba4c4 | ||
|
jingyuc
|
354c5a6e62 | ||
|
jingyuc
|
107c5526eb | ||
|
jingyuc
|
5e0a805d73 | ||
|
jingyuc
|
9de3d25172 | ||
|
erwincoumans
|
ce26271923 | ||
|
erwincoumans
|
cc84887919 | ||
|
erwincoumans
|
289a1b3f6e | ||
|
erwincoumans
|
9c37ca5185 | ||
|
erwincoumans
|
c57d6f0163 | ||
|
Erwin Coumans
|
143f87abcf | ||
|
erwincoumans
|
47c3f5e994 | ||
|
Erwin Coumans
|
87605ca4c8 | ||
|
Brendan L
|
9675e3d39b | ||
|
jingyuc
|
064fdc40bd | ||
|
erwincoumans
|
101c98cfb8 | ||
|
jingyuc
|
bfd3d1cd8d | ||
|
jingyuc
|
19375d6569 | ||
|
jingyuc
|
593f387a06 | ||
|
Aaron Franke
|
ad74cfe6c8 | ||
|
jingyuc
|
1c8afcf54f | ||
|
jingyuc
|
b4efd91476 | ||
|
jingyuc
|
9d1aafc51c | ||
|
jingyuc
|
e62c42f54c | ||
|
jingyuc
|
ce765a8a88 | ||
|
jingyuc
|
eef3b73cd2 | ||
|
jingyuc
|
3a70641c65 | ||
|
jingyuc
|
3a84b05058 | ||
|
Brendan Lewis
|
b1927a4f92 | ||
|
Erwin Coumans
|
4e881118ef | ||
|
jingyuc
|
df07b42318 | ||
|
jingyuc
|
f2e114fc81 | ||
|
jingyuc
|
e70fc6453b | ||
|
erwincoumans
|
b638300fe4 | ||
|
Erwin Coumans
|
b6df08b553 | ||
|
jingyuc
|
93e00054e3 | ||
|
Felix Büttner
|
4b6ec20b30 | ||
|
jingyuc
|
104410c63d | ||
|
erwin coumans
|
3577ef8108 | ||
|
erwin coumans
|
7de63bdbc5 | ||
|
erwincoumans
|
3fee64fb95 | ||
|
jingyuc
|
c2601663e4 | ||
|
Chuyuan Fu
|
9b3c8c8dbb | ||
|
Chuyuan Fu
|
b795243cc5 | ||
|
jingyuc
|
634c8b7b38 | ||
|
jingyuc
|
42fac2e364 | ||
|
erwincoumans
|
31b8841efc | ||
|
Erwin Coumans
|
68424feb2d | ||
|
jingyuc
|
b1803afbb9 | ||
|
erwincoumans
|
5ec0820c0e | ||
|
jingyuc
|
3e76b11d46 | ||
|
jingyuc
|
f26e3d133d | ||
|
jingyuc
|
6a87310d3c | ||
|
jingyuc
|
52abe35e41 | ||
|
Brendan Lewis
|
090f8369f8 | ||
|
jingyuc
|
166dc2865d | ||
|
jingyuc
|
c735830f0a | ||
|
jingyuc
|
840db372b9 | ||
|
erwincoumans
|
41158a4be8 | ||
|
jingyuc
|
d9152b9cf5 | ||
|
jingyuc
|
368385d5ad | ||
|
Chuyuan Fu
|
107295db5f | ||
|
Chuyuan Fu
|
e16c9bb1cc | ||
|
jingyuc
|
70ec2f9d46 | ||
|
jingyuc
|
0444fea9eb | ||
|
erwin coumans
|
7ac95be8cd | ||
|
jingyuc
|
eacdbe67a0 | ||
|
jingyuc
|
9a17391a9a | ||
|
jyc-n
|
d6d8c3ceac | ||
|
jingyuc
|
35f7a1a569 | ||
|
jingyuc
|
e4e8f1ad93 | ||
|
jingyuc
|
6355b06a8b | ||
|
jyc-n
|
3425c01acc | ||
|
jyc-n
|
042a1f75c9 | ||
|
jingyuc
|
a56ce358f3 | ||
|
jingyuc
|
0acf18f246 | ||
|
notrabs
|
b2fd9a492d | ||
|
Fabrice Fontaine
|
dd37b97e79 | ||
|
jingyuc
|
4f66d8bb87 | ||
|
jyc-n
|
252aa91e9a | ||
|
jingyuc
|
32398d4d7f | ||
|
jingyuc
|
fdfb08b72f | ||
|
erwin coumans
|
e399944982 | ||
|
jingyuc
|
35ec8b39a7 | ||
|
jingyuc
|
a37d23fa24 | ||
|
Ayzaan Wahid
|
83fbd60d5b | ||
|
jingyuc
|
5d17353269 | ||
|
Antonin Raffin
|
13f3778c22 | ||
|
Antonin Raffin
|
2f8b44c702 | ||
|
jingyuc
|
c6c7533167 | ||
|
jingyuc
|
549b57df77 | ||
|
jingyuc
|
6c2023e330 | ||
|
jyc-n
|
bfa74dbacd | ||
|
jingyuc
|
67b58428e8 | ||
|
jingyuc
|
24eb021ed6 | ||
|
jyc-n
|
0983d36eff | ||
|
jyc-n
|
7678545e76 | ||
|
jingyuc
|
9baee29300 | ||
|
jingyuc
|
6f3dd32f37 | ||
|
jyc-n
|
87e20f450b | ||
|
jyc-n
|
c325da8b34 | ||
|
jyc-n
|
45c3db58ff | ||
|
jingyuc
|
49d7bb0301 | ||
|
jingyuc
|
237333d030 | ||
|
jingyuc
|
f6dbbd4e66 | ||
|
jingyuc
|
4119d8812e | ||
|
jingyuc
|
c24f2a72ef | ||
|
jingyuc
|
4b6eaeed4c | ||
|
jingyuc
|
d390360f9e | ||
|
jingyuc
|
f1e86bf257 | ||
|
jingyuc
|
fa00ee2bbd | ||
|
jingyuc
|
a3dc901696 | ||
|
PouleyKetchoupp
|
2045f04f3c | ||
|
erwincoumans
|
0e124cb2f1 | ||
|
erwincoumans
|
a435fb7a41 | ||
|
erwincoumans
|
3e0a211868 | ||
|
Erwin Coumans
|
92fb2db0a3 | ||
|
Chuyuan Fu
|
88112560a1 | ||
|
erwincoumans
|
ebe1916b90 | ||
|
Erwin Coumans
|
092b7bc3d9 | ||
|
erwincoumans
|
39d981bce6 | ||
|
erwin coumans
|
adcf785a4a | ||
|
Erwin Coumans
|
cd76d605a9 | ||
|
erwin coumans
|
f14911c998 | ||
|
erwin coumans
|
e952ac6f63 | ||
|
erwin coumans
|
8e85dedaa9 | ||
|
erwin coumans
|
e4ff5a45d4 | ||
|
erwin coumans
|
b696ed7d7b | ||
|
cadop
|
ace34c4d08 | ||
|
erwincoumans
|
00cd39dc50 | ||
|
Andrea Catania
|
c0efe069c5 | ||
|
erwincoumans
|
c74d5e322f | ||
|
erwincoumans
|
8aab71a86e | ||
|
Erwin Coumans
|
d70c3cfdc8 | ||
|
Erwin Coumans
|
18c62ed725 | ||
|
erwincoumans
|
7f7238f630 | ||
|
erwin coumans
|
a142e8d174 | ||
|
erwin coumans
|
3b2e46e7dd | ||
|
erwincoumans
|
e0b9bc6d7f | ||
|
Erwin Coumans
|
1f6baad974 | ||
|
Erwin Coumans
|
85a03bf999 | ||
|
Erwin Coumans
|
fc2992b75a | ||
|
erwin coumans
|
6cb72b5128 | ||
|
erwin coumans
|
46ea89a284 | ||
|
erwincoumans
|
45d3ead747 | ||
|
Erwin Coumans
|
184b7816d0 | ||
|
erwincoumans
|
a7832e3a18 | ||
|
erwincoumans
|
afb572166a | ||
|
Erwin Coumans
|
c915e82d49 | ||
|
Matt Bennice
|
225fa20944 | ||
|
Erwin Coumans
|
83a5fe2d31 | ||
|
erwincoumans
|
00dcc77885 | ||
|
erwin coumans
|
a5761f2b10 | ||
|
Erwin Coumans
|
9f91e6837a | ||
|
erwincoumans
|
5c2fa7009b | ||
|
erwincoumans
|
201e7159d6 | ||
|
erwincoumans
|
f774a102ee | ||
|
erwin coumans
|
e58e5bdf95 | ||
|
erwin coumans
|
fd154cee8f | ||
|
erwin coumans
|
78f5b141f9 | ||
|
erwin coumans
|
84a63cf221 | ||
|
r-a-sattarov
|
a923ce184e | ||
|
erwincoumans
|
48ba5a37ad | ||
|
erwin coumans
|
910c20334f | ||
|
Alexander Turkin
|
f26e858154 | ||
|
Alexander Turkin
|
f04768ecc4 | ||
|
erwincoumans
|
5ae9a15eca | ||
|
erwincoumans
|
049d13d190 | ||
|
erwincoumans
|
0a8e4f3f6c | ||
|
Erwin Coumans
|
973d8c128f | ||
|
erwincoumans
|
0478d10099 | ||
|
jaraujo98
|
dcf9c8d6a5 | ||
|
erwincoumans
|
21d1b8fc71 | ||
|
Erwin Coumans
|
5205dafcc2 | ||
|
Erwin Coumans
|
29f388a5d8 | ||
|
Erwin Coumans
|
513e3a7db4 | ||
|
Erwin Coumans
|
674c82db89 | ||
|
erwincoumans
|
7ec009ec50 | ||
|
erwincoumans
|
2c3318f86d | ||
|
erwin coumans
|
8b8c1af6a4 | ||
|
erwin coumans
|
4d34ba7310 | ||
|
Erwin Coumans
|
58d47935a3 | ||
|
erwin coumans
|
d1c4c41b9a | ||
|
erwincoumans
|
93be7e6440 | ||
|
erwin coumans
|
0196edd4d2 | ||
|
Kieren
|
c810edf483 | ||
|
erwin coumans
|
546212b158 | ||
|
Chris Djali
|
6e2577ca59 | ||
|
erwin coumans
|
6f7d458679 | ||
|
erwincoumans
|
395e17c7bf | ||
|
erwin coumans
|
5cf8ee3360 | ||
|
erwin coumans
|
0b8f95598d | ||
|
erwincoumans
|
87e668f6b2 | ||
|
erwincoumans
|
2bd7fa7064 | ||
|
Erwin Coumans
|
5864901a2e | ||
|
erwincoumans
|
0c7ea68709 | ||
|
erwincoumans
|
0bf5f2cd84 | ||
|
mbennice
|
296cd85f60 | ||
|
mbennice
|
237843b93a | ||
|
erwincoumans
|
2465756313 | ||
|
Erwin Coumans
|
57c9e66ea9 | ||
|
erwincoumans
|
db5be234dd | ||
|
erwin coumans
|
5832166f53 | ||
|
erwin coumans
|
201f3dd7d8 | ||
|
Erwin Coumans
|
b619763569 | ||
|
erwin coumans
|
3963f077fc | ||
|
Gleb Mazovetskiy
|
89c76981fc | ||
|
Gleb Mazovetskiy
|
40a9584ccb | ||
|
Gleb Mazovetskiy
|
8f5a00dd1e | ||
|
erwincoumans
|
7b84fabb1e | ||
|
Vaclav Brozek
|
364e98c92d | ||
|
erwincoumans
|
e913a75f18 | ||
|
erwincoumans
|
e041514b03 | ||
|
vabr-g
|
390eeb111b | ||
|
Erwin Coumans
|
adcaa75777 | ||
|
vabr-g
|
e4963f73f2 | ||
|
Gleb Mazovetskiy
|
bb838dbec0 | ||
|
Gleb MazovetskiyandAndrew Shulaev
|
e7e28bebf8 | ||
|
Gleb MazovetskiyandAndrew Shulaev
|
782f14caa1 | ||
|
Erwin Coumans
|
97add36b9f | ||
|
Alexander Turkin
|
7aff26b80d | ||
|
erwincoumans
|
abea1a8484 | ||
|
erwincoumans
|
af6aa5fb99 | ||
|
erwincoumans
|
c3f137773b | ||
|
erwincoumans
|
ecbbf24d2a | ||
|
erwincoumans
|
1257ab5915 | ||
|
erwincoumans
|
b582287943 | ||
|
erwincoumans
|
7a6fb20da8 | ||
|
erwincoumans
|
a061644454 | ||
|
erwincoumans
|
643f9c90be | ||
|
erwincoumans
|
5d149250ba | ||
|
erwincoumans
|
062860e455 | ||
|
erwincoumans
|
1fbee5299a | ||
|
erwincoumans
|
6ad7e8fa6e | ||
|
erwincoumans
|
3b52be333b | ||
|
erwincoumans
|
70d7063249 | ||
|
erwincoumans
|
53bc9fe222 | ||
|
erwincoumans
|
e850c15754 | ||
|
erwincoumans
|
671668f6c8 | ||
|
erwincoumans
|
b259d04ba9 | ||
|
erwincoumans
|
9673ff28cf | ||
|
erwincoumans
|
a101dfeaa0 | ||
|
erwincoumans
|
7155d05d67 | ||
|
daniel.ordonez
|
f719c27b04 | ||
|
erwincoumans
|
537ccb2200 | ||
|
Gleb Mazovetskiy
|
d248271e38 | ||
|
yycho0108
|
6f65a12b3a | ||
|
yycho0108
|
c0d9553d65 | ||
|
Gleb Mazovetskiy
|
6442613ba6 | ||
|
erwincoumans
|
d274093f76 | ||
|
erwincoumans
|
48514d038b | ||
|
erwincoumans
|
de8f04f819 | ||
|
Erwin Coumans
|
21bc93a084 | ||
|
Erwin Coumans
|
10020baa71 | ||
|
Erwin Coumans
|
375d7097e4 | ||
|
Erwin Coumans
|
3f9d0197ec | ||
|
erwincoumans
|
df09fd9ed3 | ||
|
Erwin Coumans
|
9e2c39f04f | ||
|
erwincoumans
|
bbb6f86d12 | ||
|
Erwin Coumans
|
6d1dae286b | ||
|
erwincoumans
|
b1f76960ff | ||
|
Erwin Coumans
|
c97f09cf66 | ||
|
Erwin Coumans
|
93575a2e38 | ||
|
WenlongLu
|
62eb2f7788 | ||
|
erwincoumans
|
03c9bff419 | ||
|
erwincoumans
|
87b633bb76 | ||
|
erwincoumans
|
a72a32ba54 | ||
|
erwincoumans
|
ef72fdd73d | ||
|
Erwin Coumans
|
3e16c616d5 | ||
|
David Carlier
|
3c7cdb498b | ||
|
erwincoumans
|
7f87bb5362 | ||
|
Erwin Coumans
|
0f05edf1ae | ||
|
Erwin Coumans
|
ec55878a82 | ||
|
erwincoumans
|
2e550096de | ||
|
Erwin Coumans
|
e32fc59c88 | ||
|
erwincoumans
|
272c7099d3 | ||
|
erwincoumans
|
5fd3e33c86 | ||
|
WenlongLu
|
c377260d71 | ||
|
erwincoumans
|
8c8059831b | ||
|
WenlongLu
|
3ef0ce4890 | ||
|
WenlongLu
|
ddbe6f7a5a | ||
|
erwincoumans
|
875a6a4446 | ||
|
erwincoumans
|
2c38eea830 | ||
|
erwincoumans
|
1dd79bd16a | ||
|
Erwin Coumans
|
d4d11c417a | ||
|
Erwin Coumans
|
1c5d67f790 | ||
|
Erwin Coumans
|
ccf4e70a63 | ||
|
erwincoumans
|
05b5d2ee04 | ||
|
Erwin Coumans
|
76fbbcd37e | ||
|
WenlongLu
|
8ccd67727f | ||
|
WenlongLu
|
c32e721262 | ||
|
erwincoumans
|
a72ce295b4 | ||
|
erwincoumans
|
464bbc4ddd | ||
|
erwincoumans
|
9344606e5d | ||
|
erwincoumans
|
2a0f811c3b | ||
|
erwincoumans
|
63f5dbf97b | ||
|
erwincoumans
|
6c65c04b3f | ||
|
Shayekh Bin Islam
|
91c002232f | ||
|
WenlongLu
|
21836afb97 | ||
|
WenlongLu
|
56b42925d8 | ||
|
WenlongLu
|
5a1977b176 | ||
|
WenlongLu
|
622b44d136 | ||
|
erwincoumans
|
20c6178329 | ||
|
erwincoumans
|
2535d5d6e5 | ||
|
erwincoumans
|
da28ca734a | ||
|
WenlongLu
|
2fc72577f1 | ||
|
WenlongLu
|
b95f9d3afb | ||
|
WenlongLu
|
1a4783a581 | ||
|
erwincoumans
|
edbce66542 | ||
|
Erwin Coumans
|
e21c6c9f46 | ||
|
r-a-sattarov
|
c4073179a2 | ||
|
r-a-sattarov
|
961d79703b | ||
|
Erwin Coumans
|
e3dc3761a0 | ||
|
Erwin Coumans
|
49be2cffaa | ||
|
erwincoumans
|
62684840bd | ||
|
erwincoumans
|
e3274d7fc1 | ||
|
Erwin Coumans
|
a67681aee5 | ||
|
Vladimir Orlov
|
35f489f697 | ||
|
erwincoumans
|
4c46f9ce39 | ||
|
David Cavazos
|
656a1e7472 | ||
|
erwincoumans
|
bd62a6deac | ||
|
erwincoumans
|
fea468d241 | ||
|
Erwin Coumans
|
3285e37868 | ||
|
Erik Gärtner
|
777ab5a5ab | ||
|
Steven89Liu
|
104789ca99 | ||
|
David Cavazos
|
e78d31171b | ||
|
David Cavazos
|
9c2313f5c8 | ||
|
ManifoldFR
|
6a9cd4615c | ||
|
ManifoldFR
|
281e7df2ec | ||
|
tfederico
|
be27283a8e | ||
|
tfederico
|
91cb40c5ba | ||
|
tfederico
|
61df6d2ff4 | ||
|
tfederico
|
ab8d927845 | ||
|
Nan Jiang
|
46519720eb | ||
|
U-CAMELTRAIN\home
|
828020c91c |
@@ -0,0 +1,38 @@
|
||||
name: CMake
|
||||
|
||||
on:
|
||||
push:
|
||||
branches: [ master ]
|
||||
pull_request:
|
||||
branches: [ master ]
|
||||
|
||||
env:
|
||||
# Customize the CMake build type here (Release, Debug, RelWithDebInfo, etc.)
|
||||
BUILD_TYPE: Release
|
||||
|
||||
jobs:
|
||||
build:
|
||||
# The CMake configure and build commands are platform agnostic and should work equally
|
||||
# well on Windows or Mac. You can convert this to a matrix build if you need
|
||||
# cross-platform coverage.
|
||||
# See: https://docs.github.com/en/free-pro-team@latest/actions/learn-github-actions/managing-complex-workflows#using-a-build-matrix
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- uses: actions/checkout@v2
|
||||
|
||||
- name: Configure CMake
|
||||
# Configure CMake in a 'build' subdirectory. `CMAKE_BUILD_TYPE` is only required if you are using a single-configuration generator such as make.
|
||||
# See https://cmake.org/cmake/help/latest/variable/CMAKE_BUILD_TYPE.html?highlight=cmake_build_type
|
||||
run: cmake -B ${{github.workspace}}/build -DCMAKE_BUILD_TYPE=${{env.BUILD_TYPE}}
|
||||
|
||||
- name: Build
|
||||
# Build your program with the given configuration
|
||||
run: cmake --build ${{github.workspace}}/build --config ${{env.BUILD_TYPE}}
|
||||
|
||||
- name: Test
|
||||
working-directory: ${{github.workspace}}/build
|
||||
# Execute tests defined by the CMake configuration.
|
||||
# See https://cmake.org/cmake/help/latest/manual/ctest.1.html for more detail
|
||||
run: ctest -C ${{env.BUILD_TYPE}}
|
||||
|
||||
@@ -36,3 +36,7 @@ CTestTestFile.cmake
|
||||
|
||||
# vim temp files
|
||||
*.swp
|
||||
|
||||
.vscode/
|
||||
.idea/
|
||||
cmake-build-debug/
|
||||
|
||||
-51
@@ -1,51 +0,0 @@
|
||||
language: cpp
|
||||
matrix:
|
||||
include:
|
||||
- os: linux
|
||||
compiler: gcc
|
||||
env:
|
||||
- BUILD_NAME=TRUSTY_GCC
|
||||
- SUDO=sudo
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=TRUSTY_CLANG
|
||||
- SUDO=sudo
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=XENIAL_CLANG
|
||||
- DOCKER_FILE="ubuntu-xenial"
|
||||
services: docker
|
||||
- os: linux
|
||||
compiler: gcc
|
||||
env:
|
||||
- BUILD_NAME=BIONIC_GCC
|
||||
- DOCKER_FILE="ubuntu-bionic"
|
||||
services: docker
|
||||
- os: linux
|
||||
compiler: clang
|
||||
env:
|
||||
- BUILD_NAME=BIONIC_CLANG
|
||||
- DOCKER_FILE="ubuntu-bionic"
|
||||
services: docker
|
||||
- os: osx
|
||||
compiler: gcc
|
||||
env:
|
||||
- BUILD_NAME=OSX_GCC
|
||||
- os: osx
|
||||
compiler: clang
|
||||
env:
|
||||
- COMPILER=clang++
|
||||
- BUILD_NAME=OSX_CLANG
|
||||
before_install:
|
||||
- if [ -n "$DOCKER_FILE" ]; then
|
||||
docker build -t "$DOCKER_FILE" -f ".ci/docker/$DOCKER_FILE" .;
|
||||
docker run -itd -v $TRAVIS_BUILD_DIR:$TRAVIS_BUILD_DIR --env-file .ci/docker/env.list --name bullet-docker "$DOCKER_FILE";
|
||||
fi
|
||||
script:
|
||||
- if [ -n "$DOCKER_FILE" ]; then
|
||||
docker exec bullet-docker /bin/sh -c "cd $TRAVIS_BUILD_DIR && ./.ci/script.sh";
|
||||
else
|
||||
'.ci/script.sh';
|
||||
fi
|
||||
+6
-2
@@ -1,4 +1,4 @@
|
||||
cmake_minimum_required(VERSION 2.4.3)
|
||||
cmake_minimum_required(VERSION 3.5)
|
||||
set(CMAKE_ALLOW_LOOSE_LOOP_CONSTRUCTS true)
|
||||
cmake_policy(SET CMP0017 NEW)
|
||||
#this line has to appear before 'PROJECT' in order to be able to disable incremental linking
|
||||
@@ -28,6 +28,9 @@ SET(CLAMP_VELOCITIES "0" CACHE STRING "Clamp rigid bodies' velocity to this valu
|
||||
OPTION(USE_GRAPHICAL_BENCHMARK "Use Graphical Benchmark" ON)
|
||||
OPTION(BUILD_SHARED_LIBS "Use shared libraries" OFF)
|
||||
OPTION(USE_SOFT_BODY_MULTI_BODY_DYNAMICS_WORLD "Use btSoftMultiBodyDynamicsWorld" ON)
|
||||
OPTION(USE_OPENVR "Use OpenVR for virtual reality" OFF)
|
||||
|
||||
OPTION(ENABLE_VHACD "Use VHACD in BulletRobotics and pybullet" ON)
|
||||
|
||||
OPTION(BULLET2_MULTITHREADING "Build Bullet 2 libraries with mutex locking around certain operations (required for multi-threading)" OFF)
|
||||
IF (BULLET2_MULTITHREADING)
|
||||
@@ -251,7 +254,8 @@ IF(BULLET2_MULTITHREADING)
|
||||
SET(CMAKE_CXX_FLAGS "${CMAKE_CXX_FLAGS} -std=c++11")
|
||||
ENDIF (NOT MSVC)
|
||||
IF (NOT WIN32)
|
||||
LINK_LIBRARIES( pthread )
|
||||
FIND_PACKAGE(Threads)
|
||||
LINK_LIBRARIES( ${CMAKE_THREAD_LIBS_INIT} )
|
||||
ENDIF (NOT WIN32)
|
||||
ENDIF (BULLET2_MULTITHREADING)
|
||||
|
||||
|
||||
@@ -7,6 +7,9 @@ INCLUDE_DIRECTORIES(
|
||||
${BULLET_PHYSICS_SOURCE_DIR}/examples/ThirdPartyLibs/enet/include
|
||||
${BULLET_PHYSICS_SOURCE_DIR}/examples/ThirdPartyLibs/clsocket/src
|
||||
)
|
||||
ADD_DEFINITIONS(-DSTATIC_LINK_SPD_PLUGIN)
|
||||
|
||||
|
||||
|
||||
SET(BulletRobotics_INCLUDES
|
||||
../../examples/CommonInterfaces/Common2dCanvasInterface.h
|
||||
@@ -94,70 +97,103 @@ SET(BulletRobotics_INCLUDES
|
||||
)
|
||||
|
||||
SET(BulletRobotics_SRCS ${BulletRobotics_INCLUDES}
|
||||
../../examples/OpenGLWindow/SimpleCamera.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/SpAlg.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/SpAlg.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/Shape.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/Shape.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDUtil.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDUtil.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDModel.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDModel.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/MathUtil.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/MathUtil.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/KinTree.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/KinTree.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/BulletConversion.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/BulletConversion.h
|
||||
|
||||
../../examples/OpenGLWindow/SimpleCamera.cpp
|
||||
|
||||
../../examples/TinyRenderer/geometry.cpp
|
||||
../../examples/TinyRenderer/model.cpp
|
||||
../../examples/TinyRenderer/tgaimage.cpp
|
||||
../../examples/TinyRenderer/our_gl.cpp
|
||||
../../examples/TinyRenderer/TinyRenderer.cpp
|
||||
../../examples/TinyRenderer/geometry.cpp
|
||||
../../examples/TinyRenderer/model.cpp
|
||||
../../examples/TinyRenderer/tgaimage.cpp
|
||||
../../examples/TinyRenderer/our_gl.cpp
|
||||
../../examples/TinyRenderer/TinyRenderer.cpp
|
||||
|
||||
../../examples/SharedMemory/plugins/collisionFilterPlugin/collisionFilterPlugin.cpp
|
||||
../../examples/SharedMemory/plugins/pdControlPlugin/pdControlPlugin.cpp
|
||||
../../examples/SharedMemory/b3RobotSimulatorClientAPI_NoGUI.cpp
|
||||
../../examples/SharedMemory/b3RobotSimulatorClientAPI_NoDirect.cpp
|
||||
../../examples/SharedMemory/IKTrajectoryHelper.cpp
|
||||
../../examples/SharedMemory/plugins/tinyRendererPlugin/tinyRendererPlugin.cpp
|
||||
../../examples/SharedMemory/plugins/tinyRendererPlugin/TinyRendererVisualShapeConverter.cpp
|
||||
../../examples/SharedMemory/InProcessMemory.cpp
|
||||
../../examples/SharedMemory/PhysicsClient.cpp
|
||||
../../examples/SharedMemory/PhysicsServer.cpp
|
||||
../../examples/SharedMemory/PhysicsServerSharedMemory.cpp
|
||||
../../examples/SharedMemory/PhysicsDirect.cpp
|
||||
../../examples/SharedMemory/PhysicsDirectC_API.cpp
|
||||
../../examples/SharedMemory/PhysicsServerCommandProcessor.cpp
|
||||
../../examples/SharedMemory/b3PluginManager.cpp
|
||||
../../examples/SharedMemory/PhysicsClientSharedMemory.cpp
|
||||
../../examples/SharedMemory/PhysicsClientSharedMemory_C_API.cpp
|
||||
../../examples/SharedMemory/PhysicsClientC_API.cpp
|
||||
../../examples/SharedMemory/Win32SharedMemory.cpp
|
||||
../../examples/SharedMemory/PosixSharedMemory.cpp
|
||||
|
||||
../../examples/Utils/b3ResourcePath.cpp
|
||||
../../examples/Utils/RobotLoggingUtil.cpp
|
||||
../../examples/Utils/b3Clock.cpp
|
||||
../../examples/Utils/b3ResourcePath.cpp
|
||||
../../examples/Utils/ChromeTraceUtil.cpp
|
||||
../../examples/Utils/b3ResourcePath.cpp
|
||||
../../examples/Utils/RobotLoggingUtil.cpp
|
||||
../../examples/Utils/b3Clock.cpp
|
||||
../../examples/Utils/b3ResourcePath.cpp
|
||||
../../examples/Utils/ChromeTraceUtil.cpp
|
||||
|
||||
../../examples/ThirdPartyLibs/tinyxml2/tinyxml2.cpp
|
||||
../../examples/ThirdPartyLibs/Wavefront/tiny_obj_loader.cpp
|
||||
../../examples/ThirdPartyLibs/stb_image/stb_image.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/Jacobian.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/LinearR2.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/LinearR3.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/LinearR4.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/MatrixRmn.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/Misc.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/Node.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/Tree.cpp
|
||||
../../examples/ThirdPartyLibs/BussIK/VectorRn.cpp
|
||||
|
||||
../../examples/Importers/ImportColladaDemo/LoadMeshFromCollada.cpp
|
||||
../../examples/Importers/ImportObjDemo/LoadMeshFromObj.cpp
|
||||
../../examples/Importers/ImportObjDemo/Wavefront2GLInstanceGraphicsShape.cpp
|
||||
../../examples/Importers/ImportMJCFDemo/BulletMJCFImporter.cpp
|
||||
../../examples/Importers/ImportURDFDemo/BulletUrdfImporter.cpp
|
||||
../../examples/Importers/ImportURDFDemo/MyMultiBodyCreator.cpp
|
||||
../../examples/Importers/ImportURDFDemo/URDF2Bullet.cpp
|
||||
../../examples/Importers/ImportURDFDemo/UrdfParser.cpp
|
||||
../../examples/Importers/ImportURDFDemo/urdfStringSplit.cpp
|
||||
../../examples/Importers/ImportMeshUtility/b3ImportMeshUtility.cpp
|
||||
|
||||
../../examples/MultiThreading/b3PosixThreadSupport.cpp
|
||||
../../examples/MultiThreading/b3Win32ThreadSupport.cpp
|
||||
../../examples/MultiThreading/b3ThreadSupportInterface.cpp
|
||||
|
||||
../../examples/Importers/ImportColladaDemo/LoadMeshFromCollada.cpp
|
||||
../../examples/Importers/ImportObjDemo/LoadMeshFromObj.cpp
|
||||
../../examples/Importers/ImportObjDemo/Wavefront2GLInstanceGraphicsShape.cpp
|
||||
../../examples/Importers/ImportMJCFDemo/BulletMJCFImporter.cpp
|
||||
../../examples/Importers/ImportURDFDemo/BulletUrdfImporter.cpp
|
||||
../../examples/Importers/ImportURDFDemo/MyMultiBodyCreator.cpp
|
||||
../../examples/Importers/ImportURDFDemo/URDF2Bullet.cpp
|
||||
../../examples/Importers/ImportURDFDemo/UrdfParser.cpp
|
||||
../../examples/Importers/ImportURDFDemo/urdfStringSplit.cpp
|
||||
../../examples/Importers/ImportMeshUtility/b3ImportMeshUtility.cpp
|
||||
|
||||
../../examples/MultiThreading/b3PosixThreadSupport.cpp
|
||||
../../examples/MultiThreading/b3Win32ThreadSupport.cpp
|
||||
../../examples/MultiThreading/b3ThreadSupportInterface.cpp
|
||||
)
|
||||
|
||||
IF(ENABLE_VHACD)
|
||||
ADD_DEFINITIONS(-DBT_ENABLE_VHACD)
|
||||
SET(BulletRobotics_SRCS ${BulletRobotics_SRCS}
|
||||
../../Extras/VHACD/test/src/main_vhacd.cpp
|
||||
../../Extras/VHACD/src/VHACD.cpp
|
||||
../../Extras/VHACD/src/vhacdICHull.cpp
|
||||
../../Extras/VHACD/src/vhacdManifoldMesh.cpp
|
||||
../../Extras/VHACD/src/vhacdMesh.cpp
|
||||
../../Extras/VHACD/src/vhacdVolume.cpp
|
||||
)
|
||||
INCLUDE_DIRECTORIES(
|
||||
../../Extras/VHACD/inc
|
||||
../../Extras/VHACD/public
|
||||
)
|
||||
ENDIF(ENABLE_VHACD)
|
||||
|
||||
IF(BUILD_CLSOCKET)
|
||||
ADD_DEFINITIONS(-DBT_ENABLE_CLSOCKET)
|
||||
ENDIF(BUILD_CLSOCKET)
|
||||
@@ -180,7 +216,8 @@ ELSE(WIN32)
|
||||
ENDIF(BUILD_CLSOCKET)
|
||||
|
||||
IF(NOT APPLE)
|
||||
LINK_LIBRARIES( pthread ${DL} )
|
||||
FIND_PACKAGE(Threads)
|
||||
LINK_LIBRARIES( ${CMAKE_THREAD_LIBS_INIT} ${DL} )
|
||||
ENDIF(NOT APPLE)
|
||||
ENDIF(WIN32)
|
||||
|
||||
@@ -267,6 +304,7 @@ INSTALL (
|
||||
ENDIF (APPLE AND BUILD_SHARED_LIBS AND FRAMEWORK)
|
||||
|
||||
IF(NOT MSVC)
|
||||
SET(PKGCONFIG_INSTALL_PREFIX "lib${LIB_SUFFIX}/pkgconfig/" CACHE STRING "Base directory for pkgconfig files")
|
||||
CONFIGURE_FILE(${CMAKE_CURRENT_SOURCE_DIR}/bullet_robotics.pc.cmake
|
||||
${CMAKE_CURRENT_BINARY_DIR}/bullet_robotics.pc @ONLY)
|
||||
INSTALL(
|
||||
|
||||
@@ -94,21 +94,6 @@ SET(BulletRoboticsGUI_INCLUDES
|
||||
)
|
||||
|
||||
SET(BulletRoboticsGUI_SRCS ${BulletRoboticsGUI_INCLUDES}
|
||||
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/SpAlg.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/SpAlg.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/Shape.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/Shape.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDUtil.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDUtil.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDModel.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/RBDModel.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/MathUtil.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/MathUtil.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/KinTree.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/KinTree.h
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/BulletConversion.cpp
|
||||
../../examples/SharedMemory/plugins/stablePDPlugin/BulletConversion.h
|
||||
../../examples/ExampleBrowser/InProcessExampleBrowser.cpp
|
||||
../../examples/SharedMemory/GraphicsServerExample.cpp
|
||||
../../examples/SharedMemory/GraphicsClientExample.cpp
|
||||
@@ -146,7 +131,8 @@ ELSE(WIN32)
|
||||
ENDIF(BUILD_CLSOCKET)
|
||||
|
||||
IF(NOT APPLE)
|
||||
LINK_LIBRARIES( pthread ${DL} )
|
||||
FIND_PACKAGE(Threads)
|
||||
LINK_LIBRARIES( ${CMAKE_THREAD_LIBS_INIT} ${DL} )
|
||||
ENDIF(NOT APPLE)
|
||||
ENDIF(WIN32)
|
||||
|
||||
@@ -197,6 +183,7 @@ ENDIF (BUILD_SHARED_LIBS)
|
||||
ENDIF (APPLE AND BUILD_SHARED_LIBS AND FRAMEWORK)
|
||||
|
||||
IF(NOT MSVC)
|
||||
SET(PKGCONFIG_INSTALL_PREFIX "lib${LIB_SUFFIX}/pkgconfig/" CACHE STRING "Base directory for pkgconfig files")
|
||||
CONFIGURE_FILE(${CMAKE_CURRENT_SOURCE_DIR}/bullet_robotics_gui.pc.cmake
|
||||
${CMAKE_CURRENT_BINARY_DIR}/bullet_robotics_gui.pc @ONLY)
|
||||
INSTALL(
|
||||
|
||||
+32
-1
@@ -1,5 +1,36 @@
|
||||
SUBDIRS( InverseDynamics BulletRoboticsGUI BulletRobotics obj2sdf Serialize ConvexDecomposition HACD GIMPACTUtils )
|
||||
OPTION(BUILD_INVERSE_DYNAMIC_EXTRA "Build InverseDynamic extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_GUI_EXTRA "Build BulletRoboticsGUI extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_EXTRA "Build BulletRobotics extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_OBJ2SDF_EXTRA "Build obj2sdf extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_SERIALIZE_EXTRA "Build Serialize extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_CONVEX_DECOMPOSITION_EXTRA "Build ConvexDecomposition extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_HACD_EXTRA "Build HACD extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_GIMPACTUTILS_EXTRA "Build GIMPACTUtils extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
|
||||
IF(BUILD_INVERSE_DYNAMIC_EXTRA)
|
||||
SUBDIRS( InverseDynamics )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_GUI_EXTRA)
|
||||
SUBDIRS( BulletRoboticsGUI )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_EXTRA)
|
||||
SUBDIRS( BulletRobotics )
|
||||
ENDIF()
|
||||
IF(BUILD_OBJ2SDF_EXTRA)
|
||||
SUBDIRS( obj2sdf )
|
||||
ENDIF()
|
||||
IF(BUILD_SERIALIZE_EXTRA)
|
||||
SUBDIRS( Serialize )
|
||||
ENDIF()
|
||||
IF(BUILD_CONVEX_DECOMPOSITION_EXTRA)
|
||||
SUBDIRS( ConvexDecomposition )
|
||||
ENDIF()
|
||||
IF(BUILD_HACD_EXTRA)
|
||||
SUBDIRS( HACD )
|
||||
ENDIF()
|
||||
IF(BUILD_GIMPACTUTILS_EXTRA)
|
||||
SUBDIRS( GIMPACTUtils )
|
||||
ENDIF()
|
||||
|
||||
|
||||
#Maya Dynamica plugin is moved to http://dynamica.googlecode.com
|
||||
|
||||
@@ -0,0 +1,19 @@
|
||||
Copyright (c) 2004 Open Dynamics Framework Group
|
||||
www.physicstools.org
|
||||
All rights reserved.
|
||||
Redistribution and use in source and binary forms, with or without modification, are permitted provided
|
||||
that the following conditions are met:
|
||||
Redistributions of source code must retain the above copyright notice, this list of conditions
|
||||
and the following disclaimer.
|
||||
Redistributions in binary form must reproduce the above copyright notice,
|
||||
this list of conditions and the following disclaimer in the documentation
|
||||
and/or other materials provided with the distribution.
|
||||
Neither the name of the Open Dynamics Framework Group nor the names of its contributors may
|
||||
be used to endorse or promote products derived from this software without specific prior written permission.
|
||||
THIS SOFTWARE IS PROVIDED BY THE COPYRIGHT HOLDERS AND CONTRIBUTORS 'AS IS' AND ANY EXPRESS OR IMPLIED WARRANTIES,
|
||||
INCLUDING, BUT NOT LIMITED TO, THE IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR PURPOSE ARE
|
||||
DISCLAIMED. IN NO EVENT SHALL THE INTEL OR CONTRIBUTORS BE LIABLE FOR ANY DIRECT, INDIRECT, INCIDENTAL, SPECIAL,
|
||||
EXEMPLARY, OR CONSEQUENTIAL DAMAGES (INCLUDING, BUT NOT LIMITED TO, PROCUREMENT OF SUBSTITUTE GOODS OR SERVICES;
|
||||
LOSS OF USE, DATA, OR PROFITS; OR BUSINESS INTERRUPTION) HOWEVER CAUSED AND ON ANY THEORY OF LIABILITY, WHETHER
|
||||
IN CONTRACT, STRICT LIABILITY, OR TORT (INCLUDING NEGLIGENCE OR OTHERWISE) ARISING IN ANY WAY OUT OF THE USE OF
|
||||
THIS SOFTWARE, EVEN IF ADVISED OF THE POSSIBILITY OF SUCH DAMAGE.
|
||||
@@ -0,0 +1,11 @@
|
||||
|
||||
Copyright (c) 2007 Francisco Leon Najera. C.C. 80087371.
|
||||
email: projectileman@yahoo.com
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
@@ -0,0 +1,13 @@
|
||||
Copyright (c) 2011 Khaled Mamou (kmamou at gmail dot com)
|
||||
All rights reserved.
|
||||
|
||||
|
||||
Redistribution and use in source and binary forms, with or without modification, are permitted provided that the following conditions are met:
|
||||
|
||||
1. Redistributions of source code must retain the above copyright notice, this list of conditions and the following disclaimer.
|
||||
|
||||
2. Redistributions in binary form must reproduce the above copyright notice, this list of conditions and the following disclaimer in the documentation and/or other materials provided with the distribution.
|
||||
|
||||
3. The names of the contributors may not be used to endorse or promote products derived from this software without specific prior written permission.
|
||||
|
||||
THIS SOFTWARE IS PROVIDED BY THE COPYRIGHT HOLDERS AND CONTRIBUTORS "AS IS" AND ANY EXPRESS OR IMPLIED WARRANTIES, INCLUDING, BUT NOT LIMITED TO, THE IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR PURPOSE ARE DISCLAIMED. IN NO EVENT SHALL THE COPYRIGHT HOLDER OR CONTRIBUTORS BE LIABLE FOR ANY DIRECT, INDIRECT, INCIDENTAL, SPECIAL, EXEMPLARY, OR CONSEQUENTIAL DAMAGES (INCLUDING, BUT NOT LIMITED TO, PROCUREMENT OF SUBSTITUTE GOODS OR SERVICES; LOSS OF USE, DATA, OR PROFITS; OR BUSINESS INTERRUPTION) HOWEVER CAUSED AND ON ANY THEORY OF LIABILITY, WHETHER IN CONTRACT, STRICT LIABILITY, OR TORT (INCLUDING NEGLIGENCE OR OTHERWISE) ARISING IN ANY WAY OUT OF THE USE OF THIS SOFTWARE, EVEN IF ADVISED OF THE POSSIBILITY OF SUCH DAMAGE.
|
||||
@@ -0,0 +1,12 @@
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
http://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
@@ -75,6 +75,7 @@ bFile::bFile(const char *filename, const char headerString[7])
|
||||
fseek(fp, 0L, SEEK_SET);
|
||||
|
||||
mFileBuffer = (char *)malloc(mFileLen + 1);
|
||||
memset(mFileBuffer, 0, mFileLen+1);
|
||||
size_t bytesRead;
|
||||
bytesRead = fread(mFileBuffer, mFileLen, 1, fp);
|
||||
|
||||
@@ -643,8 +644,8 @@ char *bFile::readStruct(char *head, bChunkInd &dataChunk)
|
||||
if ((strcmp(oldType, "btShortIntIndexData") == 0))
|
||||
{
|
||||
int allocLen = 2;
|
||||
char *dataAlloc = new char[(dataChunk.nr * allocLen) + 1];
|
||||
memset(dataAlloc, 0, (dataChunk.nr * allocLen) + 1);
|
||||
char *dataAlloc = new char[(dataChunk.nr * allocLen) + sizeof(void*)];
|
||||
memset(dataAlloc, 0, (dataChunk.nr * allocLen) + sizeof(void*));
|
||||
short *dest = (short *)dataAlloc;
|
||||
const short *src = (short *)head;
|
||||
for (int i = 0; i < dataChunk.nr; i++)
|
||||
@@ -682,8 +683,8 @@ char *bFile::readStruct(char *head, bChunkInd &dataChunk)
|
||||
// numBlocks * length
|
||||
|
||||
int allocLen = (curLen);
|
||||
char *dataAlloc = new char[(dataChunk.nr * allocLen) + 1];
|
||||
memset(dataAlloc, 0, (dataChunk.nr * allocLen));
|
||||
char *dataAlloc = new char[(dataChunk.nr * allocLen) + sizeof(void*)];
|
||||
memset(dataAlloc, 0, (dataChunk.nr * allocLen) + sizeof(void*));
|
||||
|
||||
// track allocated
|
||||
addDataBlock(dataAlloc);
|
||||
@@ -719,8 +720,8 @@ char *bFile::readStruct(char *head, bChunkInd &dataChunk)
|
||||
#endif //
|
||||
}
|
||||
|
||||
char *dataAlloc = new char[(dataChunk.len) + 1];
|
||||
memset(dataAlloc, 0, dataChunk.len + 1);
|
||||
char *dataAlloc = new char[(dataChunk.len) + sizeof(void*)];
|
||||
memset(dataAlloc, 0, dataChunk.len + sizeof(void*));
|
||||
|
||||
// track allocated
|
||||
addDataBlock(dataAlloc);
|
||||
@@ -736,7 +737,7 @@ void bFile::parseStruct(char *strcPtr, char *dtPtr, int old_dna, int new_dna, bo
|
||||
if (new_dna == -1) return;
|
||||
|
||||
//disable this, because we need to fixup pointers/ListBase
|
||||
if (0) //mFileDNA->flagEqual(old_dna))
|
||||
if (/* DISABLES CODE */ (0)) //mFileDNA->flagEqual(old_dna))
|
||||
{
|
||||
short *strc = mFileDNA->getStruct(old_dna);
|
||||
int len = mFileDNA->getLength(strc[0]);
|
||||
|
||||
@@ -333,6 +333,7 @@ void btBulletFile::parse(int verboseMode)
|
||||
if (m_DnaCopy)
|
||||
delete m_DnaCopy;
|
||||
m_DnaCopy = (char*)btAlignedAlloc(sBulletDNAlen64, 16);
|
||||
memset(m_DnaCopy, 0, sBulletDNAlen64);
|
||||
memcpy(m_DnaCopy, sBulletDNAstr64, sBulletDNAlen64);
|
||||
parseInternal(verboseMode, m_DnaCopy, sBulletDNAlen64);
|
||||
}
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2011 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2011 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,3 +1,17 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
http://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
*/
|
||||
|
||||
#ifndef DNA_RIGIDBODY_H
|
||||
#define DNA_RIGIDBODY_H
|
||||
|
||||
@@ -0,0 +1,14 @@
|
||||
Copyright (c) 2011 Khaled Mamou (kmamou at gmail dot com)
|
||||
All rights reserved.
|
||||
|
||||
|
||||
Redistribution and use in source and binary forms, with or without modification, are permitted provided that the following conditions are met:
|
||||
|
||||
1. Redistributions of source code must retain the above copyright notice, this list of conditions and the following disclaimer.
|
||||
|
||||
2. Redistributions in binary form must reproduce the above copyright notice, this list of conditions and the following disclaimer in the documentation and/or other materials provided with the distribution.
|
||||
|
||||
3. The names of the contributors may not be used to endorse or promote products derived from this software without specific prior written permission.
|
||||
|
||||
THIS SOFTWARE IS PROVIDED BY THE COPYRIGHT HOLDERS AND CONTRIBUTORS "AS IS" AND ANY EXPRESS OR IMPLIED WARRANTIES, INCLUDING, BUT NOT LIMITED TO, THE IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR PURPOSE ARE DISCLAIMED. IN NO EVENT SHALL THE COPYRIGHT HOLDER OR CONTRIBUTORS BE LIABLE FOR ANY DIRECT, INDIRECT, INCIDENTAL, SPECIAL, EXEMPLARY, OR CONSEQUENTIAL DAMAGES (INCLUDING, BUT NOT LIMITED TO, PROCUREMENT OF SUBSTITUTE GOODS OR SERVICES; LOSS OF USE, DATA, OR PROFITS; OR BUSINESS INTERRUPTION) HOWEVER CAUSED AND ON ANY THEORY OF LIABILITY, WHETHER IN CONTRACT, STRICT LIABILITY, OR TORT (INCLUDING NEGLIGENCE OR OTHERWISE) ARISING IN ANY WAY OUT OF THE USE OF THIS SOFTWARE, EVEN IF ADVISED OF THE POSSIBILITY OF SUCH DAMAGE.
|
||||
|
||||
@@ -69,7 +69,7 @@
|
||||
#include <pthread.h>
|
||||
#endif
|
||||
|
||||
#if defined(__APPLE__)
|
||||
#if defined(__APPLE__) || !defined(__GLIBC__)
|
||||
#define PTHREAD_MUTEX_RECURSIVE_NP PTHREAD_MUTEX_RECURSIVE
|
||||
#endif
|
||||
|
||||
|
||||
+26
-12
@@ -4,6 +4,20 @@
|
||||
/// this will make it easier to load complex obj files into pybullet
|
||||
/// see for example export in data/kitchens/fathirmutfak.sdf
|
||||
|
||||
///Bullet Continuous Collision Detection and Physics Library
|
||||
///Erwin Coumans (C) 2018
|
||||
///http://bulletphysics.org
|
||||
///
|
||||
///This software is provided 'as-is', without any express or implied warranty.
|
||||
///In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
///Permission is granted to anyone to use this software for any purpose,
|
||||
///including commercial applications, and to alter it and redistribute it freely,
|
||||
///subject to the following restrictions:
|
||||
///
|
||||
///1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
///2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
///3. This notice may not be removed or altered from any source distribution.
|
||||
|
||||
#include <string.h>
|
||||
#include <stdio.h>
|
||||
#include <assert.h>
|
||||
@@ -16,13 +30,13 @@
|
||||
#include "Bullet3Common/b3HashMap.h"
|
||||
#include "../Utils/b3BulletDefaultFileIO.h"
|
||||
|
||||
using tinyobj::index_t;
|
||||
using bt_tinyobj::index_t;
|
||||
|
||||
struct ShapeContainer
|
||||
{
|
||||
std::string m_matName;
|
||||
std::string m_shapeName;
|
||||
tinyobj::material_t material;
|
||||
bt_tinyobj::material_t material;
|
||||
std::vector<float> positions;
|
||||
std::vector<float> normals;
|
||||
std::vector<float> texcoords;
|
||||
@@ -77,11 +91,11 @@ int main(int argc, char* argv[])
|
||||
char materialPrefixPath[MAX_PATH_LEN];
|
||||
b3FileUtils::extractPath(fileNameWithPath, materialPrefixPath, MAX_PATH_LEN);
|
||||
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
|
||||
b3BulletDefaultFileIO fileIO;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, fileNameWithPath, materialPrefixPath,&fileIO);
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, fileNameWithPath, materialPrefixPath, &fileIO);
|
||||
|
||||
char sdfFileName[MAX_PATH_LEN];
|
||||
sprintf(sdfFileName, "%s%s.sdf", materialPrefixPath, "newsdf");
|
||||
@@ -96,8 +110,8 @@ int main(int argc, char* argv[])
|
||||
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
tinyobj::material_t mat = shape.material;
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::material_t mat = shape.material;
|
||||
|
||||
b3HashString key = mat.name.length() ? mat.name.c_str() : "";
|
||||
if (!gMaterialNames.find(key))
|
||||
@@ -198,7 +212,7 @@ int main(int argc, char* argv[])
|
||||
|
||||
int faceCount = shapeCon->indices.size();
|
||||
int vertexCount = shapeCon->positions.size();
|
||||
tinyobj::material_t mat = shapeCon->material;
|
||||
bt_tinyobj::material_t mat = shapeCon->material;
|
||||
if (shapeCon->m_matName.length())
|
||||
{
|
||||
const char* objName = shapeCon->m_matName.c_str();
|
||||
@@ -257,7 +271,7 @@ int main(int argc, char* argv[])
|
||||
fprintf(sdfFile,
|
||||
"\t\t<model name='%s'>\n"
|
||||
"\t\t\t<static>1</static>\n"
|
||||
"\t\t\t<pose frame=''>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<pose >0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<link name='link_d%d'>\n"
|
||||
"\t\t\t<inertial>\n"
|
||||
"\t\t\t<mass>0</mass>\n"
|
||||
@@ -303,7 +317,7 @@ int main(int argc, char* argv[])
|
||||
{
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
|
||||
if (shape.name.length())
|
||||
{
|
||||
@@ -337,7 +351,7 @@ int main(int argc, char* argv[])
|
||||
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
int vertexCount = attribute.vertices.size();
|
||||
tinyobj::material_t mat = shape.material;
|
||||
bt_tinyobj::material_t mat = shape.material;
|
||||
if (shape.name.length())
|
||||
{
|
||||
const char* objName = shape.name.c_str();
|
||||
@@ -397,7 +411,7 @@ int main(int argc, char* argv[])
|
||||
fprintf(sdfFile,
|
||||
"\t\t<model name='%s'>\n"
|
||||
"\t\t\t<static>1</static>\n"
|
||||
"\t\t\t<pose frame=''>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<pose>0 0 0 0 0 0</pose>\n"
|
||||
"\t\t\t<link name='link_d%d'>\n"
|
||||
"\t\t\t<inertial>\n"
|
||||
"\t\t\t<mass>0</mass>\n"
|
||||
|
||||
@@ -7,8 +7,11 @@ This is the official C++ source code repository of the Bullet Physics SDK: real-
|
||||
|
||||
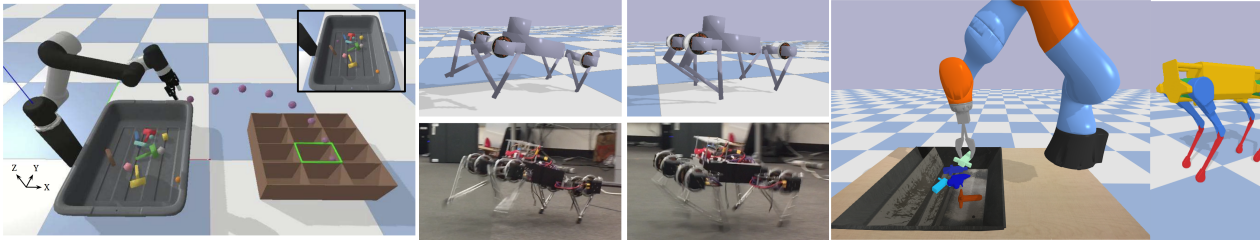
|
||||
|
||||
## Issues ##
|
||||
The Issue tracker was flooded with support questions and is closed until it is cleaned up. Use the [PyBullet forums](http://pybullet.org) to discuss with others.
|
||||
|
||||
## PyBullet ##
|
||||
New in Bullet 2.85: pybullet Python bindings, improved support for robotics and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
It is highly recommended to use PyBullet Python bindings for improved support for robotics, reinforcement learning and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
|
||||
Installation is simple:
|
||||
```
|
||||
@@ -21,11 +24,11 @@ python3 -m pybullet_envs.deep_mimic.testrl --arg_file run_humanoid3d_backflip_ar
|
||||
If you use PyBullet in your research, please cite it like this:
|
||||
|
||||
```
|
||||
@MISC{coumans2019,
|
||||
@MISC{coumans2021,
|
||||
author = {Erwin Coumans and Yunfei Bai},
|
||||
title = {PyBullet, a Python module for physics simulation for games, robotics and machine learning},
|
||||
howpublished = {\url{http://pybullet.org}},
|
||||
year = {2016--2019}
|
||||
year = {2016--2021}
|
||||
}
|
||||
```
|
||||
|
||||
@@ -63,7 +66,7 @@ You can download and install Bullet using the [vcpkg](https://github.com/Microso
|
||||
cd vcpkg
|
||||
./bootstrap-vcpkg.sh
|
||||
./vcpkg integrate install
|
||||
vcpkg install bullet3
|
||||
./vcpkg install bullet3
|
||||
|
||||
The Bullet port in vcpkg is kept up to date by Microsoft team members and community contributors. If the version is out of date, please [create an issue or pull request](https://github.com/Microsoft/vcpkg) on the vcpkg repository.
|
||||
|
||||
@@ -88,12 +91,12 @@ p.connect(p.SHARED_MEMORY) #or (p.TCP, "localhost", 6667) or (p.UDP, "192.168.86
|
||||
|
||||
**Linux and Mac OSX gnu make**
|
||||
|
||||
Make sure cmake is installed (sudo apt-get install cmake, brew install cmake, or https://cmake.org)
|
||||
Make sure gcc and cmake is installed (`sudo apt-get install build-essential` and `sudo apt-get install cmake` for Linux, `brew install cmake` for Mac, or https://cmake.org)
|
||||
|
||||
In a terminal type:
|
||||
|
||||
./build_cmake_pybullet_double.sh
|
||||
|
||||
```
|
||||
./build_cmake_pybullet_double.sh
|
||||
```
|
||||
This script will invoke cmake and build in the build_cmake directory. You can find pybullet in Bullet/examples/pybullet.
|
||||
The BulletExampleBrowser binary will be in Bullet/examples/ExampleBrowser.
|
||||
|
||||
@@ -101,15 +104,15 @@ You can also build Bullet using premake. There are premake executables in the bu
|
||||
Depending on your system (Linux 32bit, 64bit or Mac OSX) use one of the following lines
|
||||
Using premake:
|
||||
```
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
```
|
||||
Then
|
||||
```
|
||||
cd gmake
|
||||
make
|
||||
cd gmake
|
||||
make
|
||||
```
|
||||
|
||||
Note that on Linux, you need to use cmake to build pybullet, since the compiler has issues of mixing shared and static libraries.
|
||||
@@ -117,9 +120,9 @@ Note that on Linux, you need to use cmake to build pybullet, since the compiler
|
||||
**Mac OSX Xcode**
|
||||
|
||||
Click on build3/xcode4.command or in a terminal window execute
|
||||
|
||||
./premake_osx xcode4
|
||||
|
||||
```
|
||||
./premake_osx xcode4
|
||||
```
|
||||
## Usage
|
||||
|
||||
The App_ExampleBrowser executables will be located in the bin folder.
|
||||
|
||||
+29
-1
@@ -66,7 +66,27 @@
|
||||
trigger = "enable_static_vr_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/vrSyncPlugin)"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_test_plugin",
|
||||
description = "Statically link test plugin (in examples/SharedMemory/plugins/testPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_tiny_renderer__plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/tinyRendererPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_pd_control_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/pdControlPlugin)"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_static_collision_filter_plugin",
|
||||
description = "Statically link vr plugin (in examples/SharedMemory/plugins/collisionFilterPlugin)"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
trigger = "enable_physx",
|
||||
@@ -319,6 +339,12 @@ end
|
||||
trigger = "no-test",
|
||||
description = "Disable all tests"
|
||||
}
|
||||
newoption
|
||||
{
|
||||
trigger = "test-bullet2",
|
||||
|
||||
description = "Enable Bullet2 LinearMath test"
|
||||
}
|
||||
|
||||
newoption
|
||||
{
|
||||
@@ -646,7 +672,9 @@ end
|
||||
end
|
||||
|
||||
if not _OPTIONS["no-test"] then
|
||||
if _OPTIONS["test-bullet2"] then
|
||||
include "../test/Bullet2"
|
||||
end
|
||||
|
||||
if not _OPTIONS["no-gtest"] then
|
||||
include "../test/gtest-1.7.0"
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
mkdir build_cmake
|
||||
cd build_cmake
|
||||
cmake -DBUILD_PYBULLET=ON -DUSE_DOUBLE_PRECISION=ON -DCMAKE_BUILD_TYPE=Release -DPYTHON_INCLUDE_DIR=c:\python-3.5.3.amd64\include -DPYTHON_LIBRARY=c:\python-3.5.3.amd64\libs\python35.lib -DPYTHON_DEBUG_LIBRARY=c:\python-3.5.3.amd64\libs\python35_d.lib -G "Visual Studio 16 2019" ..
|
||||
cmake -DBUILD_PYBULLET=ON -DUSE_DOUBLE_PRECISION=ON -DCMAKE_BUILD_TYPE=Release -DPYTHON_INCLUDE_DIR=c:\python38\include -DPYTHON_LIBRARY=c:\python38\libs\python38.lib -DPYTHON_DEBUG_LIBRARY=c:\python38\libs\python38.lib -G "Visual Studio 16 2019" ..
|
||||
start .
|
||||
+1
-1
@@ -1,7 +1,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='unit_box_0'>
|
||||
<pose frame=''>0 0 0.107 0 0 0</pose>
|
||||
<pose>0 0 0.107 0 0 0</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
<inertial>
|
||||
<mass>0.1</mass>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.26 3.14 0 0</pose>
|
||||
<pose>0 0 0.26 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -249,9 +249,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -264,7 +264,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -273,7 +273,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</joint>
|
||||
|
||||
<link name='finger_right'>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -319,7 +319,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -329,7 +329,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -345,7 +345,7 @@
|
||||
</joint>
|
||||
|
||||
<link name='finger_left'>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -359,7 +359,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -369,7 +369,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -3,11 +3,11 @@
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
|
||||
<pose frame=''>0 -2.3 2.1 0 0 0</pose>
|
||||
<pose>0 -2.3 2.1 0 0 0</pose>
|
||||
<link name='world'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -26,9 +26,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -41,7 +41,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -56,9 +56,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -70,7 +70,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -100,9 +100,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -114,7 +114,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -145,9 +145,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -159,7 +159,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -190,9 +190,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -205,7 +205,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -214,7 +214,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -247,9 +247,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -262,7 +262,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -271,7 +271,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -307,7 +307,7 @@
|
||||
<lateral_friction value="1.0"/>
|
||||
<spinning_friction value="1.5"/>
|
||||
</contact>
|
||||
<pose frame=''>0.042 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.042 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -321,7 +321,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -331,7 +331,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -351,7 +351,7 @@
|
||||
<lateral_friction value="1.0"/>
|
||||
<spinning_friction value="1.5"/>
|
||||
</contact>
|
||||
<pose frame=''>-0.042 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.042 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -365,7 +365,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -375,7 +375,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.7 3.14 0 0</pose>
|
||||
<pose>0 0 0.7 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -248,9 +248,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -263,7 +263,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -272,7 +272,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -307,7 +307,7 @@
|
||||
<spinning_friction>.3</spinning_friction>
|
||||
<rolling_friction>0.04</rolling_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -321,7 +321,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -331,7 +331,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -351,7 +351,7 @@
|
||||
<spinning_friction>.3</spinning_friction>
|
||||
<rolling_friction>0.04</rolling_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -365,7 +365,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -375,7 +375,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,11 +2,11 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>1.4 -0.2 2.1 0 0 0</pose>
|
||||
<pose>1.4 -0.2 2.1 0 0 0</pose>
|
||||
<link name='world'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -25,9 +25,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -40,7 +40,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -55,9 +55,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -69,7 +69,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -99,9 +99,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -113,7 +113,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -144,9 +144,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -158,7 +158,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -189,9 +189,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -204,7 +204,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -213,7 +213,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -245,9 +245,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<pose>0.055 0 0.06 0 0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -260,7 +260,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -269,7 +269,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -304,7 +304,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -318,7 +318,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -328,7 +328,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -348,7 +348,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -362,7 +362,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -372,7 +372,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.4 3.14 0 0</pose>
|
||||
<pose>0 0 0.4 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -43,7 +43,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,9 +58,9 @@
|
||||
</link>
|
||||
|
||||
<link name='motor'>
|
||||
<pose frame=''>0 0 0.03 0 0 0</pose>
|
||||
<pose>0 0 0.03 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -72,7 +72,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0 0 0.01 0 0 0</pose>
|
||||
<pose>0 0 0.01 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.02 </size>
|
||||
@@ -102,9 +102,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='left_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -116,7 +116,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<pose>-0.03 0 0.01 0 -1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -147,9 +147,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='right_hinge'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.035 0 0 0</pose>
|
||||
<pose>0 0 0.035 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -161,7 +161,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='motor_visual'>
|
||||
<pose frame=''>0.03 0 0.01 0 1.2 0</pose>
|
||||
<pose>0.03 0 0.01 0 1.2 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.07 </size>
|
||||
@@ -192,9 +192,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0.06 0 -0 0</pose>
|
||||
<pose>-0.055 0 0.06 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -207,7 +207,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 0</pose>
|
||||
<pose>0 0 -0.06 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -216,7 +216,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 0</pose>
|
||||
<pose>0 0 -0.037 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -248,9 +248,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0.06 0 0 0</pose>
|
||||
<pose>0.055 0 0.06 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -263,7 +263,7 @@
|
||||
</inertial>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 -0.06 0 0 3.14159</pose>
|
||||
<pose>0 0 -0.06 0 0 3.14159</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -272,7 +272,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 -0.037 0 0 3.14159</pose>
|
||||
<pose>0 0 -0.037 0 0 3.14159</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='wsg50_with_gripper'>
|
||||
<pose frame=''>0 0 0.27 3.14 0 0</pose>
|
||||
<pose>0 0 0.27 3.14 0 0</pose>
|
||||
|
||||
<link name='world'>
|
||||
</link>
|
||||
@@ -28,9 +28,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -42,7 +42,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='base_link_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.2 0.05 0.05 </size>
|
||||
@@ -50,7 +50,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -67,9 +67,9 @@
|
||||
</link>
|
||||
|
||||
<link name='gripper_left'>
|
||||
<pose frame=''>-0.055 0 0 0 -0 0</pose>
|
||||
<pose>-0.055 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -82,7 +82,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='gripper_left_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -91,7 +91,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<collision name='gripper_left_fixed_joint_lump__finger_left_collision_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -101,7 +101,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='gripper_left_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -110,7 +110,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_left_fixed_joint_lump__finger_left_visual_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -141,9 +141,9 @@
|
||||
</joint>
|
||||
|
||||
<link name='gripper_right'>
|
||||
<pose frame=''>0.055 0 0 0 -0 3.14159</pose>
|
||||
<pose>0.055 0 0 0 -0 3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.0115 0 -0 0</pose>
|
||||
<pose>0 0 0.0115 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -156,7 +156,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='gripper_right_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -165,7 +165,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<collision name='gripper_right_fixed_joint_lump__finger_right_collision_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -175,7 +175,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='gripper_right_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -184,7 +184,7 @@
|
||||
</geometry>
|
||||
</visual>
|
||||
<visual name='gripper_right_fixed_joint_lump__finger_right_visual_1'>
|
||||
<pose frame=''>0 0 0.023 0 -0 0</pose>
|
||||
<pose>0 0 0.023 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>0.001 0.001 0.001</scale>
|
||||
@@ -219,7 +219,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<pose>0.062 0 0.145 0 0 1.5708</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -233,7 +233,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_right_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -243,7 +243,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_right_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -263,7 +263,7 @@
|
||||
<lateral_friction>1.0</lateral_friction>
|
||||
<spinning_friction>1.5</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<pose>-0.062 0 0.145 0 0 4.71239</pose>
|
||||
<inertial>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
@@ -277,7 +277,7 @@
|
||||
</inertial>
|
||||
|
||||
<collision name='finger_left_collision'>
|
||||
<pose frame=''>0 0 0.042 0 0 0 </pose>
|
||||
<pose>0 0 0.042 0 0 0 </pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.02 0.02 0.15 </size>
|
||||
@@ -287,7 +287,7 @@
|
||||
</collision>
|
||||
|
||||
<visual name='finger_left_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
+170
-170
File diff suppressed because it is too large
Load Diff
@@ -11,9 +11,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa_with_wsg50'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -25,7 +25,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -34,7 +34,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -50,9 +50,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -64,7 +64,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -73,7 +73,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -108,9 +108,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -122,7 +122,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -131,7 +131,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -166,9 +166,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -180,7 +180,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -189,7 +189,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -224,9 +224,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -238,7 +238,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,7 +247,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -282,9 +282,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -296,7 +296,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -340,9 +340,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -354,7 +354,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -363,7 +363,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -398,9 +398,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -412,7 +412,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -421,7 +421,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -462,9 +462,9 @@
|
||||
<child>base_link</child>
|
||||
</joint>
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 1.305 0 -0 0</pose>
|
||||
<pose>0 0 1.305 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>1.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -476,7 +476,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -511,9 +511,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='left_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -525,7 +525,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -544,9 +544,9 @@
|
||||
<child>left_finger_base</child>
|
||||
</joint>
|
||||
<link name='left_finger_base'>
|
||||
<pose frame=''>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<pose>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>-0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -558,7 +558,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -573,7 +573,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -606,9 +606,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>1.0</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<pose>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>-0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -620,7 +620,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_tip_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -635,7 +635,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -664,9 +664,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='right_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.1</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -678,7 +678,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -697,9 +697,9 @@
|
||||
<child>right_finger_base</child>
|
||||
</joint>
|
||||
<link name='right_finger_base'>
|
||||
<pose frame=''>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<pose>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -711,7 +711,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -726,7 +726,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -759,9 +759,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>1.0</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<pose>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -773,7 +773,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -788,7 +788,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -11,9 +11,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa_with_wsg50'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -25,7 +25,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -34,7 +34,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -50,9 +50,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -64,7 +64,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -73,7 +73,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -108,9 +108,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -122,7 +122,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -131,7 +131,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -166,9 +166,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -180,7 +180,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -189,7 +189,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -224,9 +224,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -238,7 +238,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,7 +247,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -282,9 +282,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -296,7 +296,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -305,7 +305,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -340,9 +340,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -354,7 +354,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -363,7 +363,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -398,9 +398,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>1.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -412,7 +412,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -421,7 +421,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -468,9 +468,9 @@
|
||||
|
||||
|
||||
<link name='base_link'>
|
||||
<pose frame=''>0 0 1.305 0 -0 0</pose>
|
||||
<pose>0 0 1.305 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>1</ixx>
|
||||
@@ -482,7 +482,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='base_link_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -496,7 +496,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='base_link_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.05 0.05 0.1 </size>
|
||||
@@ -531,9 +531,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='left_finger'>
|
||||
<pose frame=''>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 -0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -545,7 +545,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -559,7 +559,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_collision'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -577,9 +577,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<pose>-0.005 0.024 1.43 0 -0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>-0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -591,7 +591,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -606,7 +606,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -639,9 +639,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<pose>-0.02 0.024 1.49 0 0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>-0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -653,7 +653,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='left_finger_tip_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -668,7 +668,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='left_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -701,9 +701,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0 0.024 1.35 0 0.05 0</pose>
|
||||
<pose>0 0.024 1.35 0 0.05 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -715,7 +715,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -729,7 +729,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_collision'>
|
||||
<pose frame=''>0 0 0.04 0 0 0</pose>
|
||||
<pose>0 0 0.04 0 0 0</pose>
|
||||
<geometry>
|
||||
<box>
|
||||
<size>0.01 0.01 0.08</size>
|
||||
@@ -752,9 +752,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<pose>0.005 0.024 1.43 0 0.3 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.003 0 0.04 0 0 0 </pose>
|
||||
<pose>0.003 0 0.04 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -766,7 +766,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_base_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -781,7 +781,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_base_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0 </pose>
|
||||
<pose>0 0 0 0 0 0 </pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -814,9 +814,9 @@
|
||||
<lateral_friction>0.8</lateral_friction>
|
||||
<spinning_friction>.1</spinning_friction>
|
||||
</contact>
|
||||
<pose frame=''>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<pose>0.02 0.024 1.49 0 -0.2 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.005 0 0.026 0 0 0 </pose>
|
||||
<pose>0.005 0 0.026 0 0 0 </pose>
|
||||
<mass>0.2</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -828,7 +828,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<visual name='right_finger_visual'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
@@ -843,7 +843,7 @@
|
||||
</material>
|
||||
</visual>
|
||||
<collision name='right_finger_tip_collision'>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1 </scale>
|
||||
|
||||
@@ -6,9 +6,9 @@
|
||||
<child>lbr_iiwa_link_0</child>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0.01</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -20,7 +20,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -29,7 +29,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -39,9 +39,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -53,7 +53,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -62,7 +62,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -92,9 +92,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -106,7 +106,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -115,7 +115,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -145,9 +145,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -159,7 +159,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -168,7 +168,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -198,9 +198,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -212,7 +212,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -221,7 +221,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -251,9 +251,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -265,7 +265,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -274,7 +274,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -304,9 +304,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -318,7 +318,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -327,7 +327,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -357,9 +357,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -371,7 +371,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -380,7 +380,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
+33
-33
@@ -1,11 +1,11 @@
|
||||
<sdf version='1.6'>
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa'>
|
||||
<pose frame=''>0 -2.3 0.7 0 0 0</pose>
|
||||
<pose>0 -2.3 0.7 0 0 0</pose>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -17,7 +17,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -26,7 +26,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -42,9 +42,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -56,7 +56,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -65,7 +65,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -101,9 +101,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -115,7 +115,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -124,7 +124,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -160,9 +160,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -174,7 +174,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -183,7 +183,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -219,9 +219,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -233,7 +233,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -242,7 +242,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -278,9 +278,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -292,7 +292,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -301,7 +301,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -337,9 +337,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -351,7 +351,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -360,7 +360,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -396,9 +396,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -410,7 +410,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -419,7 +419,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
+65
-65
@@ -2,9 +2,9 @@
|
||||
<world name='default'>
|
||||
<model name='lbr_iiwa'>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -16,7 +16,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -25,7 +25,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -35,9 +35,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -49,7 +49,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -58,7 +58,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -88,9 +88,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -102,7 +102,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -111,7 +111,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -141,9 +141,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -155,7 +155,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -164,7 +164,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -194,9 +194,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -208,7 +208,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -217,7 +217,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -247,9 +247,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -261,7 +261,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -270,7 +270,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -300,9 +300,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -314,7 +314,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -323,7 +323,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -353,9 +353,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -367,7 +367,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -376,7 +376,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -408,11 +408,11 @@
|
||||
</model>
|
||||
|
||||
<model name='lbr_iiwa'>
|
||||
<pose frame=''>2 2 0 0 -0 0</pose>
|
||||
<pose>2 2 0 0 -0 0</pose>
|
||||
<link name='lbr_iiwa_link_0'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>-0.1 0 0.07 0 -0 0</pose>
|
||||
<pose>-0.1 0 0.07 0 -0 0</pose>
|
||||
<mass>0</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -424,7 +424,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_0_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -433,7 +433,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_0_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -443,9 +443,9 @@
|
||||
</visual>
|
||||
</link>
|
||||
<link name='lbr_iiwa_link_1'>
|
||||
<pose frame=''>0 0 0.1575 0 -0 0</pose>
|
||||
<pose>0 0 0.1575 0 -0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 -0.03 0.12 0 -0 0</pose>
|
||||
<pose>0 -0.03 0.12 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.1</ixx>
|
||||
@@ -457,7 +457,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_1_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -466,7 +466,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_1_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -496,9 +496,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_2'>
|
||||
<pose frame=''>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 0.36 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<pose>0.0003 0.059 0.042 0 -0 0</pose>
|
||||
<mass>4</mass>
|
||||
<inertia>
|
||||
<ixx>0.05</ixx>
|
||||
@@ -510,7 +510,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_2_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -519,7 +519,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_2_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -549,9 +549,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_3'>
|
||||
<pose frame=''>0 -0 0.5645 0 0 0</pose>
|
||||
<pose>0 -0 0.5645 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.03 0.13 0 -0 0</pose>
|
||||
<pose>0 0.03 0.13 0 -0 0</pose>
|
||||
<mass>3</mass>
|
||||
<inertia>
|
||||
<ixx>0.08</ixx>
|
||||
@@ -563,7 +563,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_3_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -572,7 +572,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_3_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -602,9 +602,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_4'>
|
||||
<pose frame=''>0 -0 0.78 1.5708 0 0</pose>
|
||||
<pose>0 -0 0.78 1.5708 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.067 0.034 0 -0 0</pose>
|
||||
<pose>0 0.067 0.034 0 -0 0</pose>
|
||||
<mass>2.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.03</ixx>
|
||||
@@ -616,7 +616,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_4_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -625,7 +625,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_4_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -655,9 +655,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_5'>
|
||||
<pose frame=''>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<pose>0 -0 0.9645 0 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<pose>0.0001 0.021 0.076 0 -0 0</pose>
|
||||
<mass>1.7</mass>
|
||||
<inertia>
|
||||
<ixx>0.02</ixx>
|
||||
@@ -669,7 +669,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_5_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -678,7 +678,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_5_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -708,9 +708,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_6'>
|
||||
<pose frame=''>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<pose>0 0 1.18 1.5708 -0 -3.14159</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<pose>0 0.0006 0.0004 0 -0 0</pose>
|
||||
<mass>1.8</mass>
|
||||
<inertia>
|
||||
<ixx>0.005</ixx>
|
||||
@@ -722,7 +722,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_6_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -731,7 +731,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_6_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -761,9 +761,9 @@
|
||||
</axis>
|
||||
</joint>
|
||||
<link name='lbr_iiwa_link_7'>
|
||||
<pose frame=''>0 0 1.261 0 0 0</pose>
|
||||
<pose>0 0 1.261 0 0 0</pose>
|
||||
<inertial>
|
||||
<pose frame=''>0 0 0.02 0 -0 0</pose>
|
||||
<pose>0 0 0.02 0 -0 0</pose>
|
||||
<mass>0.3</mass>
|
||||
<inertia>
|
||||
<ixx>0.001</ixx>
|
||||
@@ -775,7 +775,7 @@
|
||||
</inertia>
|
||||
</inertial>
|
||||
<collision name='lbr_iiwa_link_7_collision'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
@@ -784,7 +784,7 @@
|
||||
</geometry>
|
||||
</collision>
|
||||
<visual name='lbr_iiwa_link_7_visual'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<geometry>
|
||||
<mesh>
|
||||
<scale>1 1 1</scale>
|
||||
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,83 @@
|
||||
#vtk DataFile Version 2.0
|
||||
I don't think this matters
|
||||
ASCII
|
||||
DATASET UNSTRUCTURED_GRID
|
||||
POINTS 28 double
|
||||
-0.5000000000000000 -0.2500000000000000 -2.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 -2.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 -2.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 -2.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 2.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 2.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 2.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 2.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 0.0000000000000000
|
||||
-0.5000000000000000 -0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 0.0000000000000000
|
||||
0.5000000000000000 -0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 1.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 0.0000000000000000
|
||||
-0.5000000000000000 0.2500000000000000 -1.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 1.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 0.0000000000000000
|
||||
0.5000000000000000 0.2500000000000000 -1.0000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 -1.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 -0.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 0.5000000000000000
|
||||
0.0000000000000000 -0.2500000000000000 1.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 1.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 0.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 -0.5000000000000000
|
||||
0.0000000000000000 0.2500000000000000 -1.5000000000000000
|
||||
CELLS 48 192
|
||||
4 22 12 17 13
|
||||
4 20 26 21 11
|
||||
4 23 8 5 24
|
||||
4 11 27 26 19
|
||||
4 27 11 26 20
|
||||
4 17 22 24 25
|
||||
4 7 23 13 6
|
||||
4 22 17 24 13
|
||||
4 9 25 21 15
|
||||
4 24 22 8 14
|
||||
4 24 8 22 23
|
||||
4 25 9 21 22
|
||||
4 23 7 13 24
|
||||
4 15 10 16 26
|
||||
4 14 25 9 15
|
||||
4 25 14 9 22
|
||||
4 24 23 22 13
|
||||
4 15 10 21 9
|
||||
4 15 21 10 26
|
||||
4 24 25 22 14
|
||||
4 2 11 27 20
|
||||
4 7 5 23 6
|
||||
4 11 21 12 26
|
||||
4 20 1 0 16
|
||||
4 18 25 12 17
|
||||
4 18 12 25 26
|
||||
4 5 7 23 24
|
||||
4 26 21 25 15
|
||||
4 20 16 27 1
|
||||
4 21 25 22 12
|
||||
4 20 16 10 26
|
||||
4 20 27 16 26
|
||||
4 20 10 16 0
|
||||
4 11 12 19 26
|
||||
4 14 22 8 9
|
||||
4 8 23 5 4
|
||||
4 24 14 8 5
|
||||
4 11 2 27 3
|
||||
4 2 27 1 20
|
||||
4 12 18 19 26
|
||||
4 27 2 1 3
|
||||
4 24 13 17 7
|
||||
4 20 2 0 1
|
||||
4 5 23 6 4
|
||||
4 20 10 21 26
|
||||
4 12 22 17 25
|
||||
4 3 27 11 19
|
||||
4 21 26 25 12
|
||||
CELL_TYPES 10
|
||||
@@ -0,0 +1,83 @@
|
||||
#vtk DataFile Version 2.0
|
||||
I don't think this matters
|
||||
ASCII
|
||||
DATASET UNSTRUCTURED_GRID
|
||||
POINTS 28 double
|
||||
0.0000000000000000 0.0000000000000000 0.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 0.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 0.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 0.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 4.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 4.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 4.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 4.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 2.0000000000000000
|
||||
0.0000000000000000 0.0000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 2.0000000000000000
|
||||
1.0000000000000000 0.0000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 3.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 2.0000000000000000
|
||||
0.0000000000000000 0.5000000000000000 1.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 3.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 2.0000000000000000
|
||||
1.0000000000000000 0.5000000000000000 1.0000000000000000
|
||||
0.5000000000000000 0.0000000000000000 0.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 1.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 2.5000000000000000
|
||||
0.5000000000000000 0.0000000000000000 3.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 3.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 2.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 1.5000000000000000
|
||||
0.5000000000000000 0.5000000000000000 0.5000000000000000
|
||||
CELLS 48 192
|
||||
4 22 12 17 13
|
||||
4 20 26 21 11
|
||||
4 23 8 5 24
|
||||
4 11 27 26 19
|
||||
4 27 11 26 20
|
||||
4 17 22 24 25
|
||||
4 7 23 13 6
|
||||
4 22 17 24 13
|
||||
4 9 25 21 15
|
||||
4 24 22 8 14
|
||||
4 24 8 22 23
|
||||
4 25 9 21 22
|
||||
4 23 7 13 24
|
||||
4 15 10 16 26
|
||||
4 14 25 9 15
|
||||
4 25 14 9 22
|
||||
4 24 23 22 13
|
||||
4 15 10 21 9
|
||||
4 15 21 10 26
|
||||
4 24 25 22 14
|
||||
4 2 11 27 20
|
||||
4 7 5 23 6
|
||||
4 11 21 12 26
|
||||
4 20 1 0 16
|
||||
4 18 25 12 17
|
||||
4 18 12 25 26
|
||||
4 5 7 23 24
|
||||
4 26 21 25 15
|
||||
4 20 16 27 1
|
||||
4 21 25 22 12
|
||||
4 20 16 10 26
|
||||
4 20 27 16 26
|
||||
4 20 10 16 0
|
||||
4 11 12 19 26
|
||||
4 14 22 8 9
|
||||
4 8 23 5 4
|
||||
4 24 14 8 5
|
||||
4 11 2 27 3
|
||||
4 2 27 1 20
|
||||
4 12 18 19 26
|
||||
4 27 2 1 3
|
||||
4 24 13 17 7
|
||||
4 20 2 0 1
|
||||
4 5 23 6 4
|
||||
4 20 10 21 26
|
||||
4 12 22 17 25
|
||||
4 3 27 11 19
|
||||
4 21 26 25 12
|
||||
CELL_TYPES 10
|
||||
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_beam">
|
||||
<num_modes value="20"/>
|
||||
<mass value="1"/>
|
||||
<stiffness_scale value="100"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.0"/>
|
||||
<visual filename="beam_mesh_origin.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
File diff suppressed because it is too large
Load Diff
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="cube">
|
||||
<deformable name="cube">
|
||||
<inertial>
|
||||
<mass value="10" />
|
||||
<inertia ixx="0.0" ixy="0" ixz="0" iyy="0" iyz="0" izz="0" />
|
||||
</inertial>
|
||||
<collision_margin value="0.006"/>
|
||||
<repulsion_stiffness value="800.0"/>
|
||||
<friction value= "0.5"/>
|
||||
<neohookean mu= "180" lambda= "600" damping= "0.01" />
|
||||
<visual filename="cube_mesh.vtk"/>
|
||||
</deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,14 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_cube">
|
||||
<num_modes value="20"/>
|
||||
<mass value="10"/>
|
||||
<stiffness_scale value="100"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.0"/>
|
||||
<visual filename="cube_mesh.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,15 @@
|
||||
<?xml version="1.0"?>
|
||||
<robot name="reduced_cube">
|
||||
<reduced_deformable name="reduced_cube">
|
||||
<num_modes value="20"/>
|
||||
<mass value="10"/>
|
||||
<stiffness_scale value="10"/>
|
||||
<collision_margin value="0.01"/>
|
||||
<erp value= "0.2"/>
|
||||
<cfm value= "0.2"/>
|
||||
<friction value= "0.5"/>
|
||||
<damping_coefficient value="0.00001"/>
|
||||
<visual filename="torus_textured.obj"/>
|
||||
<collision filename="torus_mesh.vtk"/>
|
||||
</reduced_deformable>
|
||||
</robot>
|
||||
File diff suppressed because it is too large
Load Diff
File diff suppressed because it is too large
Load Diff
File diff suppressed because it is too large
Load Diff
+3
-3
@@ -3,7 +3,7 @@
|
||||
<gravity>0 0 -9.8</gravity>
|
||||
<model name='roboschool/models_outdoor/stadium/part0.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d0'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -34,7 +34,7 @@
|
||||
</model>
|
||||
<model name='roboschool/models_outdoor/stadium/part1.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d1'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -73,7 +73,7 @@
|
||||
</model>
|
||||
<model name='part2.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d2'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
|
||||
@@ -3,7 +3,7 @@
|
||||
<gravity>0 0 -9.8</gravity>
|
||||
<model name='part0.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d0'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -42,7 +42,7 @@
|
||||
</model>
|
||||
<model name='part1.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d1'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
@@ -81,7 +81,7 @@
|
||||
</model>
|
||||
<model name='part2.obj'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0 0 0 0 0 0</pose>
|
||||
<pose>0 0 0 0 0 0</pose>
|
||||
<link name='link_d2'>
|
||||
<inertial>
|
||||
<mass>0</mass>
|
||||
|
||||
+11
-11
@@ -3,7 +3,7 @@
|
||||
<light name='sun' type='directional'>
|
||||
<yunfei>99.2</yunfei>
|
||||
<cast_shadows>1</cast_shadows>
|
||||
<pose frame=''>0 0 10 0 -0 0</pose>
|
||||
<pose>0 0 10 0 -0 0</pose>
|
||||
<diffuse>0.8 0.8 0.8 1</diffuse>
|
||||
<specular>0.2 0.2 0.2 1</specular>
|
||||
<attenuation>
|
||||
@@ -87,7 +87,7 @@
|
||||
</spherical_coordinates>
|
||||
<model name='unit_box_0'>
|
||||
<static>1</static>
|
||||
<pose frame=''>0.512455 -1.58317 0.5 0 -0 0</pose>
|
||||
<pose>0.512455 -1.58317 0.5 0 -0 0</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
|
||||
<inertial>
|
||||
@@ -142,7 +142,7 @@
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0_clone'>
|
||||
<pose frame=''>0.105158 -4.55002 1.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 1.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<link name='unit_box_0::link'>
|
||||
<inertial>
|
||||
<mass>1</mass>
|
||||
@@ -197,42 +197,42 @@
|
||||
<wall_time>1462824251 956472000</wall_time>
|
||||
<iterations>0</iterations>
|
||||
<model name='ground_plane'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='link'>
|
||||
<pose frame=''>0 0 0 0 -0 0</pose>
|
||||
<pose>0 0 0 0 -0 0</pose>
|
||||
<velocity>0 0 0 0 -0 0</velocity>
|
||||
<acceleration>0 0 0 0 -0 0</acceleration>
|
||||
<wrench>0 0 0 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0'>
|
||||
<pose frame=''>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='unit_box_0::link'>
|
||||
<pose frame=''>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.223196 -1.84719 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<velocity>0.004896 3e-06 -0.004891 -6e-06 0.009793 -0</velocity>
|
||||
<acceleration>0.010615 0.006191 -9.78231 -0.012424 0.021225 -1.8e-05</acceleration>
|
||||
<wrench>0.010615 0.006191 -9.78231 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<model name='unit_box_0_clone'>
|
||||
<pose frame=''>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<scale>1 1 1</scale>
|
||||
<link name='unit_box_0::link'>
|
||||
<pose frame=''>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<pose>0.105158 -4.55002 0.499995 -2.89297 -0.988287 -3.14159</pose>
|
||||
<velocity>0 0 0 0 -0 0</velocity>
|
||||
<acceleration>0 0 0 0 -0 0</acceleration>
|
||||
<wrench>0 0 0 0 -0 0</wrench>
|
||||
</link>
|
||||
</model>
|
||||
<light name='sun'>
|
||||
<pose frame=''>0 0 10 0 -0 0</pose>
|
||||
<pose>0 0 10 0 -0 0</pose>
|
||||
</light>
|
||||
</state>
|
||||
<gui fullscreen='0'>
|
||||
<camera name='user_camera'>
|
||||
<pose frame=''>8.0562 -8.87312 3.07529 0 0.205021 2.5208</pose>
|
||||
<pose>8.0562 -8.87312 3.07529 0 0.205021 2.5208</pose>
|
||||
<view_controller>orbit</view_controller>
|
||||
<projection_type>perspective</projection_type>
|
||||
</camera>
|
||||
|
||||
Binary file not shown.
@@ -84,7 +84,8 @@ ELSE(WIN32)
|
||||
ADD_DEFINITIONS("-DGLEW_STATIC")
|
||||
ADD_DEFINITIONS("-DGLEW_DYNAMIC_LOAD_ALL_GLX_FUNCTIONS=1")
|
||||
|
||||
LINK_LIBRARIES( pthread ${DL} )
|
||||
FIND_PACKAGE(Threads)
|
||||
LINK_LIBRARIES( ${CMAKE_THREAD_LIBS_INIT} ${DL} )
|
||||
ENDIF(APPLE)
|
||||
ENDIF(WIN32)
|
||||
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -52,6 +52,8 @@ struct GUIHelperInterface
|
||||
virtual int getShapeIndexFromInstance(int instanceUid) { return -1; }
|
||||
virtual void replaceTexture(int shapeIndex, int textureUid) {}
|
||||
virtual void removeTexture(int textureUid) {}
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]) {}
|
||||
|
||||
|
||||
virtual Common2dCanvasInterface* get2dCanvasInterface() = 0;
|
||||
|
||||
@@ -110,6 +112,7 @@ struct GUIHelperInterface
|
||||
|
||||
virtual int addUserDebugText3D(const char* txt, const double positionXYZ[3], const double orientation[4], const double textColorRGB[3], double size, double lifeTime, int trackingVisualShapeIndex, int optionFlags, int replaceItemUid) { return -1; }
|
||||
virtual int addUserDebugLine(const double debugLineFromXYZ[3], const double debugLineToXYZ[3], const double debugLineColorRGB[3], double lineWidth, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid) { return -1; };
|
||||
virtual int addUserDebugPoints(const double debugPointPositionXYZ[], const double debugPointColorRGB[3], double pointSize, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid, int debugPointNum) { return -1; };
|
||||
virtual int addUserDebugParameter(const char* txt, double rangeMin, double rangeMax, double startValue) { return -1; };
|
||||
virtual int readUserDebugParameter(int itemUniqueId, double* value) { return 0; }
|
||||
|
||||
@@ -123,6 +126,7 @@ struct GUIHelperInterface
|
||||
virtual void dumpFramesToVideo(const char* mp4FileName){};
|
||||
virtual void drawDebugDrawerLines(){}
|
||||
virtual void clearLines(){}
|
||||
virtual bool isRemoteVisualizer() { return false; }
|
||||
};
|
||||
|
||||
///the DummyGUIHelper does nothing, so we can test the examples without GUI/graphics (in 'console mode')
|
||||
@@ -216,6 +220,10 @@ struct DummyGUIHelper : public GUIHelperInterface
|
||||
{
|
||||
return -1;
|
||||
}
|
||||
virtual int addUserDebugPoints(const double debugPointPositionXYZ[3], const double debugPointColorRGB[3], double pointSize, double lifeTime, int trackingVisualShapeIndex, int replaceItemUid, int debugPointNum)
|
||||
{
|
||||
return -1;
|
||||
};
|
||||
virtual void removeUserDebugItem(int debugItemUniqueId)
|
||||
{
|
||||
}
|
||||
|
||||
@@ -56,6 +56,8 @@ struct CommonRenderInterface
|
||||
|
||||
virtual void setLightPosition(const float lightPos[3]) = 0;
|
||||
virtual void setLightPosition(const double lightPos[3]) = 0;
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]) = 0;
|
||||
|
||||
virtual void setShadowMapResolution(int shadowMapResolution) = 0;
|
||||
virtual void setShadowMapIntensity(double shadowMapIntensity) = 0;
|
||||
|
||||
@@ -78,6 +80,7 @@ struct CommonRenderInterface
|
||||
virtual void drawLine(const double from[4], const double to[4], const double color[4], double lineWidth) = 0;
|
||||
virtual void drawPoint(const float* position, const float color[4], float pointDrawSize) = 0;
|
||||
virtual void drawPoint(const double* position, const double color[4], double pointDrawSize) = 0;
|
||||
virtual void drawPoints(const float* positions, const float* colors, int numPoints, int pointStrideInBytes, float pointDrawSize) = 0;
|
||||
virtual void drawTexturedTriangleMesh(float worldPosition[3], float worldOrientation[4], const float* vertices, int numvertices, const unsigned int* indices, int numIndices, float color[4], int textureIndex = -1, int vertexLayout = 0) = 0;
|
||||
|
||||
virtual int registerShape(const float* vertices, int numvertices, const int* indices, int numIndices, int primitiveType = B3_GL_TRIANGLES, int textureIndex = -1) = 0;
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2015 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2015 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -55,7 +55,7 @@ public:
|
||||
m_dynamicsWorld->stepSimulation(deltaTime, 4, internalTimeStep);
|
||||
}
|
||||
|
||||
void addCloth(btVector3 origin);
|
||||
void addCloth(const btVector3& origin);
|
||||
|
||||
virtual void renderScene()
|
||||
{
|
||||
@@ -126,7 +126,7 @@ void DeformableSelfCollision::initPhysics()
|
||||
getDeformableDynamicsWorld()->setLineSearch(false);
|
||||
m_guiHelper->autogenerateGraphicsObjects(m_dynamicsWorld);
|
||||
}
|
||||
void DeformableSelfCollision::addCloth(btVector3 origin)
|
||||
void DeformableSelfCollision::addCloth(const btVector3& origin)
|
||||
// create a piece of cloth
|
||||
{
|
||||
const btScalar s = 0.6;
|
||||
|
||||
@@ -0,0 +1,405 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2019 Google Inc. http://bulletphysics.org
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
*/
|
||||
|
||||
#include "LoadDeformed.h"
|
||||
///btBulletDynamicsCommon.h is the main Bullet include file, contains most common include files.
|
||||
#include "btBulletDynamicsCommon.h"
|
||||
#include "BulletSoftBody/btDeformableMultiBodyDynamicsWorld.h"
|
||||
#include "BulletSoftBody/btSoftBody.h"
|
||||
#include "BulletSoftBody/btSoftBodyHelpers.h"
|
||||
#include "BulletSoftBody/btDeformableBodySolver.h"
|
||||
#include "BulletSoftBody/btSoftBodyRigidBodyCollisionConfiguration.h"
|
||||
#include "BulletDynamics/Featherstone/btMultiBodyConstraintSolver.h"
|
||||
#include "../CommonInterfaces/CommonParameterInterface.h"
|
||||
#include <stdio.h> //printf debugging
|
||||
|
||||
#include "../CommonInterfaces/CommonDeformableBodyBase.h"
|
||||
#include "../Utils/b3ResourcePath.h"
|
||||
#include "../Utils/b3BulletDefaultFileIO.h"
|
||||
#include <iostream>
|
||||
#include <iomanip>
|
||||
#include <sstream>
|
||||
#include <string.h>
|
||||
|
||||
struct CustomSoftBodyHelper : public btSoftBodyHelpers
|
||||
{
|
||||
static std::string loadDeformableState(btAlignedObjectArray<btVector3>& qs, btAlignedObjectArray<btVector3>& vs, const char* filename, CommonFileIOInterface* fileIO);
|
||||
|
||||
};
|
||||
|
||||
static inline bool isSpace(const char c)
|
||||
{
|
||||
return (c == ' ') || (c == '\t');
|
||||
}
|
||||
static inline bool isNewLine(const char c)
|
||||
{
|
||||
return (c == '\r') || (c == '\n') || (c == '\0');
|
||||
}
|
||||
static inline float parseFloat(const char*& token)
|
||||
{
|
||||
token += strspn(token, " \t");
|
||||
float f = (float)atof(token);
|
||||
token += strcspn(token, " \t\r");
|
||||
return f;
|
||||
}
|
||||
static inline void parseFloat3(
|
||||
float& x, float& y, float& z,
|
||||
const char*& token)
|
||||
{
|
||||
x = parseFloat(token);
|
||||
y = parseFloat(token);
|
||||
z = parseFloat(token);
|
||||
}
|
||||
|
||||
|
||||
std::string CustomSoftBodyHelper::loadDeformableState(btAlignedObjectArray<btVector3>& qs, btAlignedObjectArray<btVector3>& vs, const char* filename, CommonFileIOInterface* fileIO)
|
||||
{
|
||||
{
|
||||
qs.clear();
|
||||
vs.clear();
|
||||
std::string tmp = filename;
|
||||
std::stringstream err;
|
||||
#ifdef USE_STREAM
|
||||
std::ifstream ifs(filename);
|
||||
if (!ifs)
|
||||
{
|
||||
err << "Cannot open file [" << filename << "]" << std::endl;
|
||||
return err.str();
|
||||
}
|
||||
#else
|
||||
int fileHandle = fileIO->fileOpen(filename, "r");
|
||||
if (fileHandle < 0)
|
||||
{
|
||||
err << "Cannot open file [" << filename << "]" << std::endl;
|
||||
return err.str();
|
||||
}
|
||||
#endif
|
||||
|
||||
std::string name;
|
||||
|
||||
int maxchars = 8192; // Alloc enough size.
|
||||
std::vector<char> buf(maxchars); // Alloc enough size.
|
||||
std::string linebuf;
|
||||
linebuf.reserve(maxchars);
|
||||
|
||||
#ifdef USE_STREAM
|
||||
while (ifs.peek() != -1)
|
||||
#else
|
||||
char* line = 0;
|
||||
do
|
||||
#endif
|
||||
{
|
||||
linebuf.resize(0);
|
||||
#ifdef USE_STREAM
|
||||
safeGetline(ifs, linebuf);
|
||||
#else
|
||||
char tmpBuf[1024];
|
||||
line = fileIO->readLine(fileHandle, tmpBuf, 1024);
|
||||
if (line)
|
||||
{
|
||||
linebuf = line;
|
||||
}
|
||||
#endif
|
||||
// Trim newline '\r\n' or '\r'
|
||||
if (linebuf.size() > 0)
|
||||
{
|
||||
if (linebuf[linebuf.size() - 1] == '\n') linebuf.erase(linebuf.size() - 1);
|
||||
}
|
||||
if (linebuf.size() > 0)
|
||||
{
|
||||
if (linebuf[linebuf.size() - 1] == '\n') linebuf.erase(linebuf.size() - 1);
|
||||
}
|
||||
|
||||
// Skip if empty line.
|
||||
if (linebuf.empty())
|
||||
{
|
||||
continue;
|
||||
}
|
||||
|
||||
// Skip leading space.
|
||||
const char* token = linebuf.c_str();
|
||||
token += strspn(token, " \t");
|
||||
|
||||
btAssert(token);
|
||||
if (token[0] == '\0') continue; // empty line
|
||||
|
||||
if (token[0] == '#') continue; // comment line
|
||||
|
||||
// q
|
||||
if (token[0] == 'q' && isSpace((token[1])))
|
||||
{
|
||||
token += 2;
|
||||
float x, y, z;
|
||||
parseFloat3(x, y, z, token);
|
||||
qs.push_back(btVector3(x, y, z));
|
||||
continue;
|
||||
}
|
||||
|
||||
// v
|
||||
if (token[0] == 'v' && isSpace((token[1])))
|
||||
{
|
||||
token += 3;
|
||||
float x, y, z;
|
||||
parseFloat3(x, y, z, token);
|
||||
vs.push_back(btVector3(x, y, z));
|
||||
continue;
|
||||
}
|
||||
|
||||
// Ignore unknown command.
|
||||
}
|
||||
#ifndef USE_STREAM
|
||||
while (line)
|
||||
;
|
||||
#endif
|
||||
|
||||
if (fileHandle >= 0)
|
||||
{
|
||||
fileIO->fileClose(fileHandle);
|
||||
}
|
||||
return err.str();
|
||||
}
|
||||
}
|
||||
|
||||
|
||||
class LoadDeformed : public CommonDeformableBodyBase
|
||||
{
|
||||
int steps;
|
||||
btSoftBody* psb;
|
||||
char filename;
|
||||
int reset_frame;
|
||||
float sim_time;
|
||||
|
||||
public:
|
||||
LoadDeformed(struct GUIHelperInterface* helper)
|
||||
: CommonDeformableBodyBase(helper)
|
||||
{
|
||||
steps = 0;
|
||||
psb = nullptr;
|
||||
reset_frame = 0;
|
||||
sim_time = 0;
|
||||
}
|
||||
virtual ~LoadDeformed()
|
||||
{
|
||||
}
|
||||
void initPhysics();
|
||||
|
||||
void exitPhysics();
|
||||
|
||||
void resetCamera()
|
||||
{
|
||||
float dist = 2;
|
||||
float pitch = -45;
|
||||
float yaw = 100;
|
||||
float targetPos[3] = {0, 0, 0};
|
||||
m_guiHelper->resetCamera(dist, yaw, pitch, targetPos[0], targetPos[1], targetPos[2]);
|
||||
}
|
||||
|
||||
void stepSimulation(float deltaTime)
|
||||
{
|
||||
steps++;
|
||||
sim_time += deltaTime;
|
||||
//// int seconds = 1/deltaTime;
|
||||
if (0)
|
||||
{
|
||||
// if (reset_frame==0 && steps<100){
|
||||
//// printf("steps %d, seconds %d, steps/seconds %d\n", steps,seconds,steps/seconds);
|
||||
char filename[100];
|
||||
sprintf(filename, "%s_%d_%d.txt", "states", reset_frame, steps);
|
||||
btSoftBodyHelpers::writeState(filename, psb);
|
||||
}
|
||||
if (sim_time + reset_frame * 0.05 >= 5) exit(0);
|
||||
float internalTimeStep = 1. / 240.f;
|
||||
// float internalTimeStep = 0.1f;
|
||||
m_dynamicsWorld->stepSimulation(deltaTime, deltaTime / internalTimeStep, internalTimeStep);
|
||||
}
|
||||
|
||||
void addCloth(const btVector3& origin);
|
||||
|
||||
virtual void renderScene()
|
||||
{
|
||||
CommonDeformableBodyBase::renderScene();
|
||||
btDeformableMultiBodyDynamicsWorld* deformableWorld = getDeformableDynamicsWorld();
|
||||
|
||||
for (int i = 0; i < deformableWorld->getSoftBodyArray().size(); i++)
|
||||
{
|
||||
btSoftBody* psb = (btSoftBody*)deformableWorld->getSoftBodyArray()[i];
|
||||
{
|
||||
btSoftBodyHelpers::DrawFrame(psb, deformableWorld->getDebugDrawer());
|
||||
btSoftBodyHelpers::Draw(psb, deformableWorld->getDebugDrawer(), deformableWorld->getDrawFlags());
|
||||
}
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
void LoadDeformed::initPhysics()
|
||||
{
|
||||
m_guiHelper->setUpAxis(1);
|
||||
|
||||
///collision configuration contains default setup for memory, collision setup
|
||||
m_collisionConfiguration = new btSoftBodyRigidBodyCollisionConfiguration();
|
||||
|
||||
///use the default collision dispatcher. For parallel processing you can use a diffent dispatcher (see Extras/BulletMultiThreaded)
|
||||
m_dispatcher = new btCollisionDispatcher(m_collisionConfiguration);
|
||||
|
||||
m_broadphase = new btDbvtBroadphase();
|
||||
btDeformableBodySolver* deformableBodySolver = new btDeformableBodySolver();
|
||||
|
||||
btDeformableMultiBodyConstraintSolver* sol = new btDeformableMultiBodyConstraintSolver();
|
||||
sol->setDeformableSolver(deformableBodySolver);
|
||||
m_solver = sol;
|
||||
|
||||
m_dynamicsWorld = new btDeformableMultiBodyDynamicsWorld(m_dispatcher, m_broadphase, sol, m_collisionConfiguration, deformableBodySolver);
|
||||
btVector3 gravity = btVector3(0, -9.8, 0);
|
||||
m_dynamicsWorld->setGravity(gravity);
|
||||
getDeformableDynamicsWorld()->getWorldInfo().m_gravity = gravity;
|
||||
getDeformableDynamicsWorld()->getWorldInfo().m_sparsesdf.setDefaultVoxelsz(0.25);
|
||||
|
||||
m_guiHelper->createPhysicsDebugDrawer(m_dynamicsWorld);
|
||||
|
||||
{
|
||||
///create a ground
|
||||
btCollisionShape* groundShape = new btBoxShape(btVector3(btScalar(150.), btScalar(2.5), btScalar(150.)));
|
||||
groundShape->setMargin(0.02);
|
||||
m_collisionShapes.push_back(groundShape);
|
||||
|
||||
btTransform groundTransform;
|
||||
groundTransform.setIdentity();
|
||||
groundTransform.setOrigin(btVector3(0, -3.5, 0));
|
||||
groundTransform.setRotation(btQuaternion(btVector3(1, 0, 0), SIMD_PI * 0));
|
||||
btScalar mass(0.);
|
||||
|
||||
//rigidbody is dynamic if and only if mass is non zero, otherwise static
|
||||
bool isDynamic = (mass != 0.f);
|
||||
|
||||
btVector3 localInertia(0, 0, 0);
|
||||
if (isDynamic)
|
||||
groundShape->calculateLocalInertia(mass, localInertia);
|
||||
|
||||
//using motionstate is recommended, it provides interpolation capabilities, and only synchronizes 'active' objects
|
||||
btDefaultMotionState* myMotionState = new btDefaultMotionState(groundTransform);
|
||||
btRigidBody::btRigidBodyConstructionInfo rbInfo(mass, myMotionState, groundShape, localInertia);
|
||||
btRigidBody* body = new btRigidBody(rbInfo);
|
||||
body->setFriction(4);
|
||||
|
||||
//add the ground to the dynamics world
|
||||
m_dynamicsWorld->addRigidBody(body);
|
||||
}
|
||||
addCloth(btVector3(0, 1, 0));
|
||||
getDeformableDynamicsWorld()->setImplicit(false);
|
||||
getDeformableDynamicsWorld()->setLineSearch(false);
|
||||
m_guiHelper->autogenerateGraphicsObjects(m_dynamicsWorld);
|
||||
}
|
||||
|
||||
void LoadDeformed::addCloth(const btVector3& origin)
|
||||
// create a piece of cloth
|
||||
{
|
||||
const btScalar s = 0.6;
|
||||
const btScalar h = 0;
|
||||
|
||||
psb = btSoftBodyHelpers::CreatePatch(getDeformableDynamicsWorld()->getWorldInfo(), btVector3(-s, h, -2 * s),
|
||||
btVector3(+s, h, -2 * s),
|
||||
btVector3(-s, h, +2 * s),
|
||||
btVector3(+s, h, +2 * s),
|
||||
15, 30,
|
||||
0, true, 0.0);
|
||||
|
||||
psb->getCollisionShape()->setMargin(0.02);
|
||||
psb->generateBendingConstraints(2);
|
||||
psb->setTotalMass(.5);
|
||||
psb->m_cfg.kKHR = 1; // collision hardness with kinematic objects
|
||||
psb->m_cfg.kCHR = 1; // collision hardness with rigid body
|
||||
psb->m_cfg.kDF = 0.1;
|
||||
psb->rotate(btQuaternion(0, SIMD_PI / 2, 0));
|
||||
btTransform clothTransform;
|
||||
clothTransform.setIdentity();
|
||||
clothTransform.setOrigin(btVector3(0, 0.2, 0) + origin);
|
||||
psb->transform(clothTransform);
|
||||
|
||||
b3BulletDefaultFileIO fileio;
|
||||
char absolute_path[1024];
|
||||
char filename[100];
|
||||
sprintf(filename, "/Users/fuchuyuan/Documents/mybullet/build_cmake/examples/ExampleBrowser/states_0_%d.txt", reset_frame);
|
||||
fileio.findResourcePath(filename, absolute_path, 1024);
|
||||
btAlignedObjectArray<btVector3> qs;
|
||||
btAlignedObjectArray<btVector3> vs;
|
||||
CustomSoftBodyHelper::loadDeformableState(qs, vs, absolute_path, &fileio);
|
||||
if (reset_frame > 0)
|
||||
psb->updateState(qs, vs);
|
||||
psb->m_cfg.collisions = btSoftBody::fCollision::SDF_RD;
|
||||
psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_MDF;
|
||||
psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_RDF;
|
||||
// psb->m_cfg.collisions |= btSoftBody::fCollision::SDF_RDN;
|
||||
psb->setCollisionFlags(0);
|
||||
psb->setCacheBarycenter(true);
|
||||
getDeformableDynamicsWorld()->addSoftBody(psb);
|
||||
psb->setSelfCollision(false);
|
||||
|
||||
btDeformableMassSpringForce* mass_spring = new btDeformableMassSpringForce(2, 0.2, true);
|
||||
psb->setSpringStiffness(4);
|
||||
getDeformableDynamicsWorld()->addForce(psb, mass_spring);
|
||||
m_forces.push_back(mass_spring);
|
||||
btVector3 gravity = btVector3(0, -9.8, 0);
|
||||
btDeformableGravityForce* gravity_force = new btDeformableGravityForce(gravity);
|
||||
getDeformableDynamicsWorld()->addForce(psb, gravity_force);
|
||||
// getDeformableDynamicsWorld()->setUseProjection(true);
|
||||
m_forces.push_back(gravity_force);
|
||||
}
|
||||
|
||||
void LoadDeformed::exitPhysics()
|
||||
{
|
||||
//cleanup in the reverse order of creation/initialization
|
||||
removePickingConstraint();
|
||||
//remove the rigidbodies from the dynamics world and delete them
|
||||
int i;
|
||||
for (i = m_dynamicsWorld->getNumCollisionObjects() - 1; i >= 0; i--)
|
||||
{
|
||||
btCollisionObject* obj = m_dynamicsWorld->getCollisionObjectArray()[i];
|
||||
btRigidBody* body = btRigidBody::upcast(obj);
|
||||
if (body && body->getMotionState())
|
||||
{
|
||||
delete body->getMotionState();
|
||||
}
|
||||
m_dynamicsWorld->removeCollisionObject(obj);
|
||||
delete obj;
|
||||
}
|
||||
// delete forces
|
||||
for (int j = 0; j < m_forces.size(); j++)
|
||||
{
|
||||
btDeformableLagrangianForce* force = m_forces[j];
|
||||
delete force;
|
||||
}
|
||||
m_forces.clear();
|
||||
|
||||
//delete collision shapes
|
||||
for (int j = 0; j < m_collisionShapes.size(); j++)
|
||||
{
|
||||
btCollisionShape* shape = m_collisionShapes[j];
|
||||
delete shape;
|
||||
}
|
||||
m_collisionShapes.clear();
|
||||
|
||||
delete m_dynamicsWorld;
|
||||
|
||||
delete m_solver;
|
||||
|
||||
delete m_broadphase;
|
||||
|
||||
delete m_dispatcher;
|
||||
|
||||
delete m_collisionConfiguration;
|
||||
}
|
||||
|
||||
class CommonExampleInterface* LoadDeformedCreateFunc(struct CommonExampleOptions& options)
|
||||
{
|
||||
return new LoadDeformed(options.m_guiHelper);
|
||||
}
|
||||
@@ -0,0 +1,19 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2019 Google Inc. http://bulletphysics.org
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
2. Altered source versions must be plainly marked as such, and must not be misrepresented as being the original software.
|
||||
3. This notice may not be removed or altered from any source distribution.
|
||||
*/
|
||||
|
||||
#ifndef _LOAD_DEFORMED_H
|
||||
#define _LOAD_DEFORMED_H
|
||||
|
||||
class CommonExampleInterface* LoadDeformedCreateFunc(struct CommonExampleOptions& options);
|
||||
|
||||
#endif //_LOAD_DEFORMED_H
|
||||
@@ -61,11 +61,12 @@ IF (BUILD_SHARED_LIBS)
|
||||
BulletInverseDynamics LinearMath OpenGLWindow gwen BussIK
|
||||
${COCOA} ${OPENGL_gl_LIBRARY} ${OPENGL_glu_LIBRARY}
|
||||
)
|
||||
ELSE(APPLE)
|
||||
ELSE(APPLE)
|
||||
FIND_PACKAGE(Threads)
|
||||
TARGET_LINK_LIBRARIES(
|
||||
BulletExampleBrowserLib Bullet3Common BulletSoftBody BulletDynamics BulletCollision BulletInverseDynamicsUtils
|
||||
BulletInverseDynamics LinearMath OpenGLWindow gwen BussIK
|
||||
pthread ${DL}
|
||||
${CMAKE_THREAD_LIBS_INIT} ${DL}
|
||||
)
|
||||
ENDIF(APPLE)
|
||||
ENDIF(WIN32)
|
||||
@@ -116,7 +117,8 @@ ELSE(WIN32)
|
||||
ADD_DEFINITIONS("-DGLEW_STATIC")
|
||||
ADD_DEFINITIONS("-DGLEW_DYNAMIC_LOAD_ALL_GLX_FUNCTIONS=1")
|
||||
INCLUDE_DIRECTORIES( ${BULLET_PHYSICS_SOURCE_DIR}/examples/ThirdPartyLibs/glad )
|
||||
LINK_LIBRARIES( pthread ${DL})
|
||||
FIND_PACKAGE(Threads)
|
||||
LINK_LIBRARIES( ${CMAKE_THREAD_LIBS_INIT} ${DL} )
|
||||
ENDIF(APPLE)
|
||||
ENDIF(WIN32)
|
||||
|
||||
@@ -282,7 +284,7 @@ SET(BulletExampleBrowser_SRCS
|
||||
../Benchmarks/BenchmarkDemo.cpp
|
||||
../Benchmarks/BenchmarkDemo.h
|
||||
../Benchmarks/landscapeData.h
|
||||
../Benchmarks/TaruData
|
||||
../Benchmarks/TaruData.h
|
||||
../Raycast/RaytestDemo.cpp
|
||||
../Importers/ImportBsp/BspConverter.h
|
||||
../Importers/ImportBullet/SerializeSetup.cpp
|
||||
@@ -350,7 +352,8 @@ SET(BulletExampleBrowser_SRCS
|
||||
../MultiBody/TestJointTorqueSetup.h
|
||||
../MultiBody/InvertedPendulumPDControl.cpp
|
||||
../MultiBody/InvertedPendulumPDControl.h
|
||||
../MultiBody/MultiBodyConstraintFeedback.cpp
|
||||
../MultiBody/MultiBodyConstraintFeedback.cpp
|
||||
../MultiBody/KinematicMultiBodyExample.cpp
|
||||
../SoftDemo/SoftDemo.cpp
|
||||
../SoftDemo/SoftDemo.h
|
||||
../DeformableDemo/DeformableContact.cpp
|
||||
@@ -376,6 +379,8 @@ SET(BulletExampleBrowser_SRCS
|
||||
../DeformableDemo/Collide.cpp
|
||||
../DeformableDemo/Collide.h
|
||||
../DeformableDemo/LargeDeformation.cpp
|
||||
../DeformableDemo/LoadDeformed.h
|
||||
../DeformableDemo/LoadDeformed.cpp
|
||||
../DeformableDemo/LargeDeformation.h
|
||||
../DeformableDemo/DeformableClothAnchor.cpp
|
||||
../DeformableDemo/DeformableClothAnchor.h
|
||||
@@ -384,6 +389,25 @@ SET(BulletExampleBrowser_SRCS
|
||||
../MultiBody/MultiDofDemo.cpp
|
||||
../MultiBody/MultiDofDemo.h
|
||||
../RigidBody/RigidBodySoftContact.cpp
|
||||
../RigidBody/KinematicRigidBodyExample.cpp
|
||||
../ReducedDeformableDemo/ConservationTest.cpp
|
||||
../ReducedDeformableDemo/ConservationTest.h
|
||||
../ReducedDeformableDemo/Springboard.cpp
|
||||
../ReducedDeformableDemo/Springboard.h
|
||||
../ReducedDeformableDemo/ModeVisualizer.cpp
|
||||
../ReducedDeformableDemo/ModeVisualizer.h
|
||||
../ReducedDeformableDemo/FreeFall.cpp
|
||||
../ReducedDeformableDemo/FreeFall.h
|
||||
../ReducedDeformableDemo/FrictionSlope.cpp
|
||||
../ReducedDeformableDemo/FrictionSlope.h
|
||||
../ReducedDeformableDemo/ReducedCollide.cpp
|
||||
../ReducedDeformableDemo/ReducedCollide.h
|
||||
../ReducedDeformableDemo/ReducedGrasp.cpp
|
||||
../ReducedDeformableDemo/ReducedGrasp.h
|
||||
../ReducedDeformableDemo/ReducedBenchmark.cpp
|
||||
../ReducedDeformableDemo/ReducedBenchmark.h
|
||||
../ReducedDeformableDemo/ReducedMotorGrasp.cpp
|
||||
../ReducedDeformableDemo/ReducedMotorGrasp.h
|
||||
../Constraints/TestHingeTorque.cpp
|
||||
../Constraints/TestHingeTorque.h
|
||||
../Constraints/ConstraintDemo.cpp
|
||||
|
||||
@@ -33,8 +33,10 @@
|
||||
#include "../MultiBody/MultiBodyConstraintFeedback.h"
|
||||
#include "../MultiBody/MultiDofDemo.h"
|
||||
#include "../MultiBody/InvertedPendulumPDControl.h"
|
||||
#include "../MultiBody/KinematicMultiBodyExample.h"
|
||||
|
||||
#include "../RigidBody/RigidBodySoftContact.h"
|
||||
#include "../RigidBody/KinematicRigidBodyExample.h"
|
||||
#include "../VoronoiFracture/VoronoiFractureDemo.h"
|
||||
#include "../SoftDemo/SoftDemo.h"
|
||||
#include "../Constraints/ConstraintDemo.h"
|
||||
@@ -53,6 +55,7 @@
|
||||
#include "../DeformableDemo/DeformableMultibody.h"
|
||||
#include "../DeformableDemo/VolumetricDeformable.h"
|
||||
#include "../DeformableDemo/LargeDeformation.h"
|
||||
#include "../DeformableDemo/LoadDeformed.h"
|
||||
#include "../DeformableDemo/Collide.h"
|
||||
#include "../DeformableDemo/GraspDeformable.h"
|
||||
#include "../DeformableDemo/DeformableContact.h"
|
||||
@@ -70,6 +73,15 @@
|
||||
#include "../RoboticsLearning/R2D2GraspExample.h"
|
||||
#include "../RoboticsLearning/KukaGraspExample.h"
|
||||
#include "../RoboticsLearning/GripperGraspExample.h"
|
||||
#include "../ReducedDeformableDemo/ConservationTest.h"
|
||||
#include "../ReducedDeformableDemo/ModeVisualizer.h"
|
||||
#include "../ReducedDeformableDemo/Springboard.h"
|
||||
#include "../ReducedDeformableDemo/FreeFall.h"
|
||||
#include "../ReducedDeformableDemo/FrictionSlope.h"
|
||||
#include "../ReducedDeformableDemo/ReducedCollide.h"
|
||||
#include "../ReducedDeformableDemo/ReducedGrasp.h"
|
||||
#include "../ReducedDeformableDemo/ReducedMotorGrasp.h"
|
||||
#include "../ReducedDeformableDemo/ReducedBenchmark.h"
|
||||
#include "../InverseKinematics/InverseKinematicsExample.h"
|
||||
|
||||
#ifdef B3_ENABLE_TINY_AUDIO
|
||||
@@ -145,6 +157,7 @@ static ExampleEntry gDefaultExamples[] =
|
||||
ExampleEntry(1, "Gyroscopic", "Show the Dzhanibekov effect using various settings of the gyroscopic term. You can select the gyroscopic term computation using btRigidBody::setFlags, with arguments BT_ENABLE_GYROSCOPIC_FORCE_EXPLICIT (using explicit integration, which adds energy and can lead to explosions), BT_ENABLE_GYROSCOPIC_FORCE_IMPLICIT_WORLD, BT_ENABLE_GYROSCOPIC_FORCE_IMPLICIT_BODY. If you don't set any of these flags, there is no gyroscopic term used.", GyroscopicCreateFunc),
|
||||
|
||||
ExampleEntry(1, "Soft Contact", "Using the error correction parameter (ERP) and constraint force mixing (CFM) values for contacts to simulate compliant contact.", RigidBodySoftContactCreateFunc),
|
||||
ExampleEntry(1, "Kinematic Body", "Let the user set the transform, the physics engine computes the velocity for one-way contact and friction interaction.", KinematicRigidBodyExampleCreateFunc),
|
||||
|
||||
ExampleEntry(0, "MultiBody"),
|
||||
ExampleEntry(1, "MultiDof", "Create a basic btMultiBody with 3-DOF spherical joints (mobilizers). The demo uses a fixed base or a floating base at restart.", MultiDofCreateFunc),
|
||||
@@ -154,6 +167,7 @@ static ExampleEntry gDefaultExamples[] =
|
||||
ExampleEntry(1, "Constraint Feedback", "The example shows how to receive joint reaction forces in a btMultiBody. Also the applied impulse is available for a btMultiBodyJointMotor", MultiBodyConstraintFeedbackCreateFunc),
|
||||
ExampleEntry(1, "Inverted Pendulum PD", "Keep an inverted pendulum up using open loop PD control", InvertedPendulumPDControlCreateFunc),
|
||||
ExampleEntry(1, "MultiBody Soft Contact", "Using the error correction parameter (ERP) and constraint force mixing (CFM) values for contacts to simulate compliant contact.", MultiBodySoftContactCreateFunc, 0),
|
||||
ExampleEntry(1, "Kinematic MultiBody", "Let the user set the transform, the physics engine computes the velocity for one-way contact and friction interaction.", KinematicMultiBodyExampleCreateFunc),
|
||||
|
||||
ExampleEntry(0, "Physics Client-Server"),
|
||||
ExampleEntry(1, "Physics Server", "Create a physics server that communicates with a physics client over shared memory. You can connect to the server using pybullet, a PhysicsClient or a UDP/TCP Bridge.",
|
||||
@@ -205,11 +219,24 @@ static ExampleEntry gDefaultExamples[] =
|
||||
ExampleEntry(1, "Grasp Deformable with Motor", "Grasping test", GraspDeformableCreateFunc),
|
||||
ExampleEntry(1, "Volumetric Deformable Objects", "Volumetric Deformable test", VolumetricDeformableCreateFunc),
|
||||
ExampleEntry(1, "Extreme Deformation", "Recovery from extreme deformation", LargeDeformationCreateFunc),
|
||||
ExampleEntry(1, "Load Deformed", "Reconstruct a deformed object", LoadDeformedCreateFunc),
|
||||
ExampleEntry(1, "Colliding Test", "Volumetric deformable collide with rigid box", CollideCreateFunc),
|
||||
ExampleEntry(1, "Rigid Cloth Anchor", "Deformable Rigid body Anchor test", DeformableClothAnchorCreateFunc),
|
||||
ExampleEntry(1, "Multibody Cloth Anchor", "Deformable Multibody Anchor test", MultibodyClothAnchorCreateFunc),
|
||||
ExampleEntry(1, "Deformable-MultiBody Contact", "MultiBody and Deformable contact", DeformableMultibodyCreateFunc),
|
||||
// ExampleEntry(1, "MultiBody Baseline", "MultiBody Baseline", MultiBodyBaselineCreateFunc),
|
||||
|
||||
ExampleEntry(0, "Reduced Deformabe Body"),
|
||||
ExampleEntry(1, "Mode Visualizer", "Visualizer the modes for reduced deformable objects", ReducedModeVisualizerCreateFunc),
|
||||
ExampleEntry(1, "Reduced Conservation Test", "Momentum conservation test for the reduced deformable objects", ReducedConservationTestCreateFunc),
|
||||
ExampleEntry(1, "Reduced Springboard", "Moving rigid object colliding with a fixed reduced deformable objects", ReducedSpringboardCreateFunc),
|
||||
ExampleEntry(1, "Reduced Free Fall", "Free fall ground contact test for the reduced deformable model", ReducedFreeFallCreateFunc),
|
||||
ExampleEntry(1, "Reduced Collision Test", "Collision between a reduced block and the a rigid block", ReducedCollideCreateFunc),
|
||||
ExampleEntry(1, "Reduced Grasp", "Grasp a reduced deformable block", ReducedGraspCreateFunc),
|
||||
ExampleEntry(1, "Reduced Motor Grasp", "Grasp a reduced deformable block with motor", ReducedMotorGraspCreateFunc),
|
||||
ExampleEntry(1, "Reduced Friction Slope", "Grasp a reduced deformable block", FrictionSlopeCreateFunc),
|
||||
ExampleEntry(1, "Reduced Benchmark", "Reduced deformable performance benchmark example", ReducedBenchmarkCreateFunc),
|
||||
// ExampleEntry(1, "Simple Reduced Deformable Test", "Simple dynamics test for the reduced deformable objects", ReducedBasicTestCreateFunc),
|
||||
|
||||
#ifdef INCLUDE_CLOTH_DEMOS
|
||||
ExampleEntry(0, "Soft Body"),
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,7 +1,11 @@
|
||||
#include "GwenParameterInterface.h"
|
||||
#include "gwenInternalData.h"
|
||||
#include <cstring>
|
||||
|
||||
#ifdef _WIN32
|
||||
#define safe_printf _snprintf
|
||||
#else
|
||||
#define safe_printf snprintf
|
||||
#endif
|
||||
struct MyButtonEventHandler : public Gwen::Event::Handler
|
||||
{
|
||||
Gwen::Controls::Button* m_buttonControl;
|
||||
@@ -85,7 +89,7 @@ struct MySliderEventHandler : public Gwen::Event::Handler
|
||||
if (m_showValue)
|
||||
{
|
||||
char txt[1024];
|
||||
snprintf(txt, sizeof(txt), "%s : %.3f", m_variableName, val);
|
||||
safe_printf(txt, sizeof(txt), "%s : %.3f", m_variableName, val);
|
||||
m_label->SetText(txt);
|
||||
}
|
||||
}
|
||||
@@ -231,7 +235,7 @@ void GwenParameterInterface::registerSliderFloatParameter(SliderParams& params)
|
||||
}
|
||||
pSlider->SetValue(*params.m_paramValuePointer); //dimensions[i] );
|
||||
char labelName[1024];
|
||||
snprintf(labelName, sizeof(labelName), "%s", params.m_name); //axisNames[0]);
|
||||
safe_printf(labelName, sizeof(labelName), "%s", params.m_name); //axisNames[0]);
|
||||
MySliderEventHandler<btScalar>* handler = new MySliderEventHandler<btScalar>(labelName, label, pSlider, params.m_paramValuePointer, params.m_callback, params.m_userPointer);
|
||||
handler->m_showValue = params.m_showValues;
|
||||
m_paramInternalData->m_sliderEventHandlers.push_back(handler);
|
||||
|
||||
@@ -885,6 +885,20 @@ bool OpenGLExampleBrowser::init(int argc, char* argv[])
|
||||
sUseOpenGL2 = args.CheckCmdLineFlag("opengl2");
|
||||
args.GetCmdLineArgument("render_device", gRenderDevice);
|
||||
args.GetCmdLineArgument("window_backend", gWindowBackend);
|
||||
|
||||
int max_num_object_capacity = 128 * 1024;
|
||||
int max_shape_capacity_in_bytes = 128 * 1024 * 1024;
|
||||
if (args.CheckCmdLineFlag("max_num_object_capacity"))
|
||||
{
|
||||
args.GetCmdLineArgument("max_num_object_capacity", max_num_object_capacity);
|
||||
}
|
||||
|
||||
if (args.CheckCmdLineFlag("max_shape_capacity_in_bytes"))
|
||||
{
|
||||
args.GetCmdLineArgument("max_shape_capacity_in_bytes", max_shape_capacity_in_bytes);
|
||||
}
|
||||
|
||||
|
||||
#else
|
||||
sUseOpenGL2 = true;
|
||||
#endif
|
||||
@@ -914,7 +928,7 @@ bool OpenGLExampleBrowser::init(int argc, char* argv[])
|
||||
{
|
||||
char title[1024];
|
||||
sprintf(title, "%s using OpenGL3+ %s %s", appTitle, glContext, optMode);
|
||||
simpleApp = new SimpleOpenGL3App(title, width, height, gAllowRetina, gWindowBackend, gRenderDevice);
|
||||
simpleApp = new SimpleOpenGL3App(title, width, height, gAllowRetina, gWindowBackend, gRenderDevice, max_num_object_capacity, max_shape_capacity_in_bytes);
|
||||
s_app = simpleApp;
|
||||
}
|
||||
#endif
|
||||
|
||||
@@ -236,13 +236,19 @@ OpenGLGuiHelper::OpenGLGuiHelper(CommonGraphicsApp* glApp, bool useOpenGL2)
|
||||
m_data->m_debugDraw = 0;
|
||||
}
|
||||
|
||||
OpenGLGuiHelper::~OpenGLGuiHelper()
|
||||
|
||||
OpenGLGuiHelper::~OpenGLGuiHelper()
|
||||
{
|
||||
delete m_data->m_debugDraw;
|
||||
|
||||
delete m_data;
|
||||
}
|
||||
|
||||
void OpenGLGuiHelper::setBackgroundColor(const double rgbBackground[3])
|
||||
{
|
||||
this->getRenderInterface()->setBackgroundColor(rgbBackground);
|
||||
}
|
||||
|
||||
struct CommonRenderInterface* OpenGLGuiHelper::getRenderInterface()
|
||||
{
|
||||
return m_data->m_glApp->m_renderer;
|
||||
|
||||
@@ -36,7 +36,7 @@ struct OpenGLGuiHelper : public GUIHelperInterface
|
||||
virtual int getShapeIndexFromInstance(int instanceUid);
|
||||
virtual void replaceTexture(int shapeIndex, int textureUid);
|
||||
virtual void updateShape(int shapeIndex, float* vertices, int numVertices);
|
||||
|
||||
virtual void setBackgroundColor(const double rgbBackground[3]);
|
||||
virtual void createCollisionShapeGraphicsObject(btCollisionShape* collisionShape);
|
||||
|
||||
virtual void syncPhysicsToGraphics(const btDiscreteDynamicsWorld* rbWorld);
|
||||
|
||||
@@ -182,6 +182,7 @@ project "App_BulletExampleBrowser"
|
||||
"../VoronoiFracture/*",
|
||||
"../SoftDemo/*",
|
||||
"../DeformableDemo/*",
|
||||
"../ReducedDeformableDemo/*",
|
||||
"../RollingFrictionDemo/*",
|
||||
"../rbdl/*",
|
||||
"../FractureDemo/*",
|
||||
@@ -196,7 +197,9 @@ project "App_BulletExampleBrowser"
|
||||
"../MultiBody/MultiBodySoftContact.cpp",
|
||||
"../MultiBody/MultiBodyConstraintFeedback.cpp",
|
||||
"../MultiBody/InvertedPendulumPDControl.cpp",
|
||||
"../MultiBody/KinematicMultiBodyExample.cpp",
|
||||
"../RigidBody/RigidBodySoftContact.cpp",
|
||||
"../RigidBody/KinematicRigidBodyExample.cpp",
|
||||
"../ThirdPartyLibs/stb_image/stb_image.cpp",
|
||||
"../ThirdPartyLibs/Wavefront/tiny_obj_loader.*",
|
||||
"../GyroscopicDemo/GyroscopicSetup.cpp",
|
||||
|
||||
@@ -101,7 +101,7 @@ void CompoundBoxesExample::initPhysics()
|
||||
#else
|
||||
// recompute the shift to make sure the compound shape is re-aligned
|
||||
for (int i = 0; i < compoundShape->getNumChildShapes(); i++)
|
||||
compound2->addChildShape(compoundShape->getChildTransform(i) * principal.inverse(),
|
||||
compound2->addChildShape(principal.inverse() * compoundShape->getChildTransform(i),
|
||||
compoundShape->getChildShape(i));
|
||||
#endif
|
||||
delete compoundShape;
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2011 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2011 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2007 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2007 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
/*
|
||||
Bullet Continuous Collision Detection and Physics Library
|
||||
Copyright (c) 2003-2006 Erwin Coumans http://continuousphysics.com/Bullet/
|
||||
Copyright (c) 2003-2006 Erwin Coumans https://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
|
||||
@@ -2273,7 +2273,7 @@ int BulletMJCFImporter::getBodyUniqueId() const
|
||||
return m_data->m_activeBodyUniqueId;
|
||||
}
|
||||
|
||||
static btCollisionShape* MjcfCreateConvexHullFromShapes(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, const btVector3& geomScale, btScalar collisionMargin)
|
||||
static btCollisionShape* MjcfCreateConvexHullFromShapes(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, const btVector3& geomScale, btScalar collisionMargin)
|
||||
{
|
||||
btCompoundShape* compound = new btCompoundShape();
|
||||
compound->setMargin(collisionMargin);
|
||||
@@ -2285,7 +2285,7 @@ static btCollisionShape* MjcfCreateConvexHullFromShapes(const tinyobj::attrib_t&
|
||||
{
|
||||
btConvexHullShape* convexHull = new btConvexHullShape();
|
||||
convexHull->setMargin(collisionMargin);
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
@@ -2399,9 +2399,9 @@ class btCompoundShape* BulletMJCFImporter::convertLinkCollisionShapes(int linkIn
|
||||
}
|
||||
else
|
||||
{
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, col->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, col->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
//create a convex hull for each shape, and store it in a btCompoundShape
|
||||
|
||||
childShape = MjcfCreateConvexHullFromShapes(attribute, shapes, col->m_geometry.m_meshScale, m_data->m_globalDefaults.m_defaultCollisionMargin);
|
||||
|
||||
@@ -64,8 +64,8 @@ bool b3ImportMeshUtility::loadAndRegisterMeshFromFileInternal(const std::string&
|
||||
b3FileUtils::extractPath(relativeFileName, pathPrefix, 1024);
|
||||
btVector3 shift(0, 0, 0);
|
||||
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
{
|
||||
B3_PROFILE("tinyobj::LoadObj");
|
||||
std::string err = LoadFromCachedOrFromObj(attribute, shapes, relativeFileName, pathPrefix, fileIO);
|
||||
@@ -79,7 +79,7 @@ bool b3ImportMeshUtility::loadAndRegisterMeshFromFileInternal(const std::string&
|
||||
//try to load some texture
|
||||
for (int i = 0; meshData.m_textureImage1 == 0 && i < shapes.size(); i++)
|
||||
{
|
||||
const tinyobj::shape_t& shape = shapes[i];
|
||||
const bt_tinyobj::shape_t& shape = shapes[i];
|
||||
meshData.m_rgbaColor[0] = shape.material.diffuse[0];
|
||||
meshData.m_rgbaColor[1] = shape.material.diffuse[1];
|
||||
meshData.m_rgbaColor[2] = shape.material.diffuse[2];
|
||||
|
||||
@@ -11,8 +11,8 @@
|
||||
struct CachedObjResult
|
||||
{
|
||||
std::string m_msg;
|
||||
std::vector<tinyobj::shape_t> m_shapes;
|
||||
tinyobj::attrib_t m_attribute;
|
||||
std::vector<bt_tinyobj::shape_t> m_shapes;
|
||||
bt_tinyobj::attrib_t m_attribute;
|
||||
};
|
||||
|
||||
static b3HashMap<b3HashString, CachedObjResult> gCachedObjResults;
|
||||
@@ -32,8 +32,8 @@ void b3EnableFileCaching(int enable)
|
||||
}
|
||||
|
||||
std::string LoadFromCachedOrFromObj(
|
||||
tinyobj::attrib_t& attribute,
|
||||
std::vector<tinyobj::shape_t>& shapes, // [output]
|
||||
bt_tinyobj::attrib_t& attribute,
|
||||
std::vector<bt_tinyobj::shape_t>& shapes, // [output]
|
||||
const char* filename,
|
||||
const char* mtl_basepath,
|
||||
struct CommonFileIOInterface* fileIO)
|
||||
@@ -47,7 +47,7 @@ std::string LoadFromCachedOrFromObj(
|
||||
return result.m_msg;
|
||||
}
|
||||
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, filename, mtl_basepath, fileIO);
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, filename, mtl_basepath, fileIO);
|
||||
CachedObjResult result;
|
||||
result.m_msg = err;
|
||||
result.m_shapes = shapes;
|
||||
@@ -62,10 +62,10 @@ std::string LoadFromCachedOrFromObj(
|
||||
GLInstanceGraphicsShape* LoadMeshFromObj(const char* relativeFileName, const char* materialPrefixPath, struct CommonFileIOInterface* fileIO)
|
||||
{
|
||||
B3_PROFILE("LoadMeshFromObj");
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
{
|
||||
B3_PROFILE("tinyobj::LoadObj2");
|
||||
B3_PROFILE("bt_tinyobj::LoadObj2");
|
||||
std::string err = LoadFromCachedOrFromObj(attribute, shapes, relativeFileName, materialPrefixPath, fileIO);
|
||||
}
|
||||
|
||||
|
||||
@@ -9,8 +9,8 @@ int b3IsFileCachingEnabled();
|
||||
void b3EnableFileCaching(int enable);
|
||||
|
||||
std::string LoadFromCachedOrFromObj(
|
||||
tinyobj::attrib_t& attribute,
|
||||
std::vector<tinyobj::shape_t>& shapes, // [output]
|
||||
bt_tinyobj::attrib_t& attribute,
|
||||
std::vector<bt_tinyobj::shape_t>& shapes, // [output]
|
||||
const char* filename,
|
||||
const char* mtl_basepath,
|
||||
struct CommonFileIOInterface* fileIO);
|
||||
|
||||
@@ -9,7 +9,7 @@
|
||||
#include "../../OpenGLWindow/GLInstancingRenderer.h"
|
||||
#include "../../OpenGLWindow/GLInstanceGraphicsShape.h"
|
||||
|
||||
GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, bool flatShading)
|
||||
GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, bool flatShading)
|
||||
{
|
||||
b3AlignedObjectArray<GLInstanceVertex>* vertices = new b3AlignedObjectArray<GLInstanceVertex>;
|
||||
{
|
||||
@@ -19,7 +19,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
|
||||
for (int s = 0; s < (int)shapes.size(); s++)
|
||||
{
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
for (int f = 0; f < faceCount; f += 3)
|
||||
@@ -36,7 +36,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx0;
|
||||
tinyobj::index_t v_0 = shape.mesh.indices[f];
|
||||
bt_tinyobj::index_t v_0 = shape.mesh.indices[f];
|
||||
vtx0.xyzw[0] = attribute.vertices[3 * v_0.vertex_index];
|
||||
vtx0.xyzw[1] = attribute.vertices[3 * v_0.vertex_index + 1];
|
||||
vtx0.xyzw[2] = attribute.vertices[3 * v_0.vertex_index + 2];
|
||||
@@ -65,7 +65,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx1;
|
||||
tinyobj::index_t v_1 = shape.mesh.indices[f + 1];
|
||||
bt_tinyobj::index_t v_1 = shape.mesh.indices[f + 1];
|
||||
vtx1.xyzw[0] = attribute.vertices[3 * v_1.vertex_index];
|
||||
vtx1.xyzw[1] = attribute.vertices[3 * v_1.vertex_index + 1];
|
||||
vtx1.xyzw[2] = attribute.vertices[3 * v_1.vertex_index + 2];
|
||||
@@ -94,7 +94,7 @@ GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::a
|
||||
}
|
||||
|
||||
GLInstanceVertex vtx2;
|
||||
tinyobj::index_t v_2 = shape.mesh.indices[f + 2];
|
||||
bt_tinyobj::index_t v_2 = shape.mesh.indices[f + 2];
|
||||
vtx2.xyzw[0] = attribute.vertices[3 * v_2.vertex_index];
|
||||
vtx2.xyzw[1] = attribute.vertices[3 * v_2.vertex_index + 1];
|
||||
vtx2.xyzw[2] = attribute.vertices[3 * v_2.vertex_index + 2];
|
||||
|
||||
@@ -4,6 +4,6 @@
|
||||
#include "../../ThirdPartyLibs/Wavefront/tiny_obj_loader.h"
|
||||
#include <vector>
|
||||
|
||||
struct GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, bool flatShading = false);
|
||||
struct GLInstanceGraphicsShape* btgCreateGraphicsShapeFromWavefrontObj(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, bool flatShading = false);
|
||||
|
||||
#endif //WAVEFRONT2GRAPHICS_H
|
||||
|
||||
@@ -483,6 +483,12 @@ void BulletURDFImporter::getMassAndInertia(int linkIndex, btScalar& mass, btVect
|
||||
}
|
||||
|
||||
bool BulletURDFImporter::getJointInfo2(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity) const
|
||||
{
|
||||
btScalar twistLimit;
|
||||
return getJointInfo3(urdfLinkIndex, parent2joint, linkTransformInWorld, jointAxisInJointSpace, jointType, jointLowerLimit, jointUpperLimit, jointDamping, jointFriction, jointMaxForce, jointMaxVelocity, twistLimit);
|
||||
}
|
||||
|
||||
bool BulletURDFImporter::getJointInfo3(int urdfLinkIndex, btTransform& parent2joint, btTransform& linkTransformInWorld, btVector3& jointAxisInJointSpace, int& jointType, btScalar& jointLowerLimit, btScalar& jointUpperLimit, btScalar& jointDamping, btScalar& jointFriction, btScalar& jointMaxForce, btScalar& jointMaxVelocity, btScalar& twistLimit) const
|
||||
{
|
||||
jointLowerLimit = 0.f;
|
||||
jointUpperLimit = 0.f;
|
||||
@@ -510,6 +516,7 @@ bool BulletURDFImporter::getJointInfo2(int urdfLinkIndex, btTransform& parent2jo
|
||||
jointFriction = pj->m_jointFriction;
|
||||
jointMaxForce = pj->m_effortLimit;
|
||||
jointMaxVelocity = pj->m_velocityLimit;
|
||||
twistLimit = pj->m_twistLimit;
|
||||
return true;
|
||||
}
|
||||
else
|
||||
@@ -540,7 +547,7 @@ bool BulletURDFImporter::getRootTransformInWorld(btTransform& rootTransformInWor
|
||||
return true;
|
||||
}
|
||||
|
||||
static btCollisionShape* createConvexHullFromShapes(const tinyobj::attrib_t& attribute, std::vector<tinyobj::shape_t>& shapes, const btVector3& geomScale, int flags)
|
||||
static btCollisionShape* createConvexHullFromShapes(const bt_tinyobj::attrib_t& attribute, std::vector<bt_tinyobj::shape_t>& shapes, const btVector3& geomScale, int flags)
|
||||
{
|
||||
B3_PROFILE("createConvexHullFromShapes");
|
||||
btCompoundShape* compound = new btCompoundShape();
|
||||
@@ -553,7 +560,7 @@ static btCollisionShape* createConvexHullFromShapes(const tinyobj::attrib_t& att
|
||||
{
|
||||
btConvexHullShape* convexHull = new btConvexHullShape();
|
||||
convexHull->setMargin(gUrdfDefaultCollisionMargin);
|
||||
tinyobj::shape_t& shape = shapes[s];
|
||||
bt_tinyobj::shape_t& shape = shapes[s];
|
||||
int faceCount = shape.mesh.indices.size();
|
||||
|
||||
for (int f = 0; f < faceCount; f += 3)
|
||||
@@ -747,9 +754,9 @@ btCollisionShape* BulletURDFImporter::convertURDFToCollisionShape(const UrdfColl
|
||||
}
|
||||
else
|
||||
{
|
||||
std::vector<tinyobj::shape_t> shapes;
|
||||
tinyobj::attrib_t attribute;
|
||||
std::string err = tinyobj::LoadObj(attribute, shapes, collision->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
std::vector<bt_tinyobj::shape_t> shapes;
|
||||
bt_tinyobj::attrib_t attribute;
|
||||
std::string err = bt_tinyobj::LoadObj(attribute, shapes, collision->m_geometry.m_meshFileName.c_str(), "", m_data->m_fileIO);
|
||||
//create a convex hull for each shape, and store it in a btCompoundShape
|
||||
shape = createConvexHullFromShapes(attribute, shapes, collision->m_geometry.m_meshScale, m_data->m_flags);
|
||||
m_data->m_bulletCollisionShape2UrdfCollision.insert(shape, *collision);
|
||||
@@ -1534,3 +1541,8 @@ const struct UrdfDeformable& BulletURDFImporter::getDeformableModel() const
|
||||
{
|
||||
return m_data->m_urdfParser.getDeformable();
|
||||
}
|
||||
|
||||
const struct UrdfReducedDeformable& BulletURDFImporter::getReducedDeformableModel() const
|
||||
{
|
||||
return m_data->m_urdfParser.getReducedDeformable();
|
||||
}
|
||||
|
||||
Some files were not shown because too many files have changed in this diff Show More
Reference in New Issue
Block a user